Related Experiment Video
Updated: Nov 19, 2025
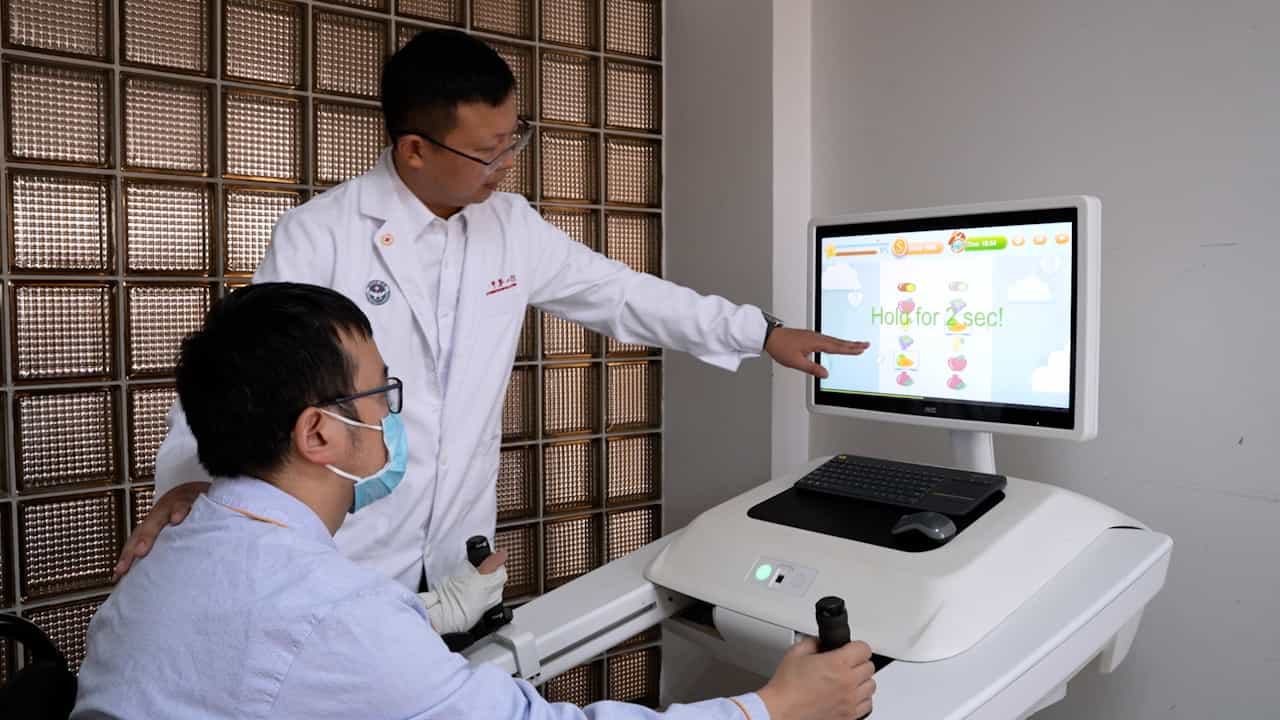

Author Spotlight: Enhancing Upper Limb Rehabilitation in Stroke Patients Through Advanced Robotic and Neuromodulation Technologies
Published on: October 11, 2024
Multi-Lateral Teleoperation Based on Multi-Agent Framework: Application to Simultaneous Training and Therapy in
Iman Sharifi1, Heidar Ali Talebi1, Rajni R Patel2
1Electrical Engineering Department, Amirkabir University of Technology, Tehran, Iran.

Abstract:
In this paper, a new scheme for multi-lateral remote rehabilitation is proposed. There exist one therapist, one patient, and several trainees, who are participating in the process of telerehabilitation (TR) in this scheme. This kind of strategy helps the therapist to facilitate the neurorehabilitation remotely. Thus, the patients can stay in their homes, resulting in safer and less expensive costs. Meanwhile, several trainees in medical education centers can be trained by participating partially in the rehabilitation process. The trainees participate in a "hands-on" manner; so, they feel like they are rehabilitating the patient directly. For implementing such a scheme, a novel theoretical method is proposed using the power of multi-agent systems (MAS) theory into the multi-lateral teleoperation, based on the self-intelligence in the MAS. In the previous related works, changing the number of participants in the multi-lateral teleoperation tasks required redesigning the controllers; while, in this paper using both of the decentralized control and the self-intelligence of the MAS, avoids the need for redesigning the controller in the proposed structure. Moreover, in this research, uncertainties in the operators' dynamics, as well as time-varying delays in the communication channels, are taken into account. It is shown that the proposed structure has two tuning matrices (L and D) that can be used for different scenarios of multi-lateral teleoperation. By choosing proper tuning matrices, many related works about the multi-lateral teleoperation/telerehabilitation process can be implemented. In the final section of the paper, several scenarios were introduced to achieve "Simultaneous Training and Therapy" in TR and are implemented with the proposed structure. The results confirmed the stability and performance of the proposed framework.
More Related Videos
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
 13:44
Haptic/Graphic Rehabilitation: Integrating a Robot into a Virtual Environment Library and Applying it to Stroke Therapy
Published on: August 8, 2011