Related Experiment Video
Updated: Nov 17, 2025

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Small-signal modeling and robust multi-loop PID and H∞ controllers synthesis for a self-excited induction generator
Metin Demirtas1, Haris Calgan1, Toufik Amieur2
1Department of Electrical and Electronics Engineering, Balikesir University, 10145 Balikesir, Turkey.

Abstract:
This paper presents modeling and designing of robust multi-loop controllers for the terminal voltage and stator frequency regulations of three-phase self-excited induction generator (SEIG) driven by a prime mover. The lack of the internal functionality of the SEIG system often represents a major challenge for most researchers. This is due to the several reasons, such as the absence of perfect mathematical models describing the actual behavior of SEIG, existence of some non-linear modes to be neglected during the linearization step and presence of unavoidable model uncertainties, etc. For this purpose, a small-signal-based method is proposed in order to overcome these drawbacks by designing the frequency and voltage linear models of the SEIG around its operating point. These models are carried out through the preprocessed experimental data recorded previously from actual SEIG system. Each appropriate model is independently computed using the identification toolbox of Matlab® software. The main advantage of the small-signal-based modeling is its simplicity without any knowledge of the equivalent circuit parameters of the SEIG. Accordingly, three robust voltage H∞ controllers are synthesized from solving a weighted-mixed sensitivity problem using both classical and structured H∞ synthesis. Each robust voltage controller and a robust frequency controller are operated with together as multi-loop controller. The novelty and contribution of the proposed method involve adjusting the parameters of the robust multi-loop controllers that ensure a good trade-off between performances and robustness using the small-signal model of the voltage and frequency in correspondence with the preselected operating point, recorded and pre-processed input-output data of the SEIG. The advantage of the multi-loop controllers is ensured not only for the nominal plant but also for all neighboring uncertainty models. The real-time implementation of controllers is performed using STM32 microcontroller unit. Simulation and experimental tests show the validity of the proposed linear small-signal models as well as the effectiveness of each proposed robust multi-loop controllers in terms of Nominal Performance (NP) margin, Robust Stability (RS) margin and the trade-off between them. However, when the operating point of the SEIG system changes significantly according to its nominal state, the guarantee of NP-RS trade-off becomes insecure.
More Related Videos
 06:04
Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:19
PID Controller
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:24
PI Controller: Design
 01:21
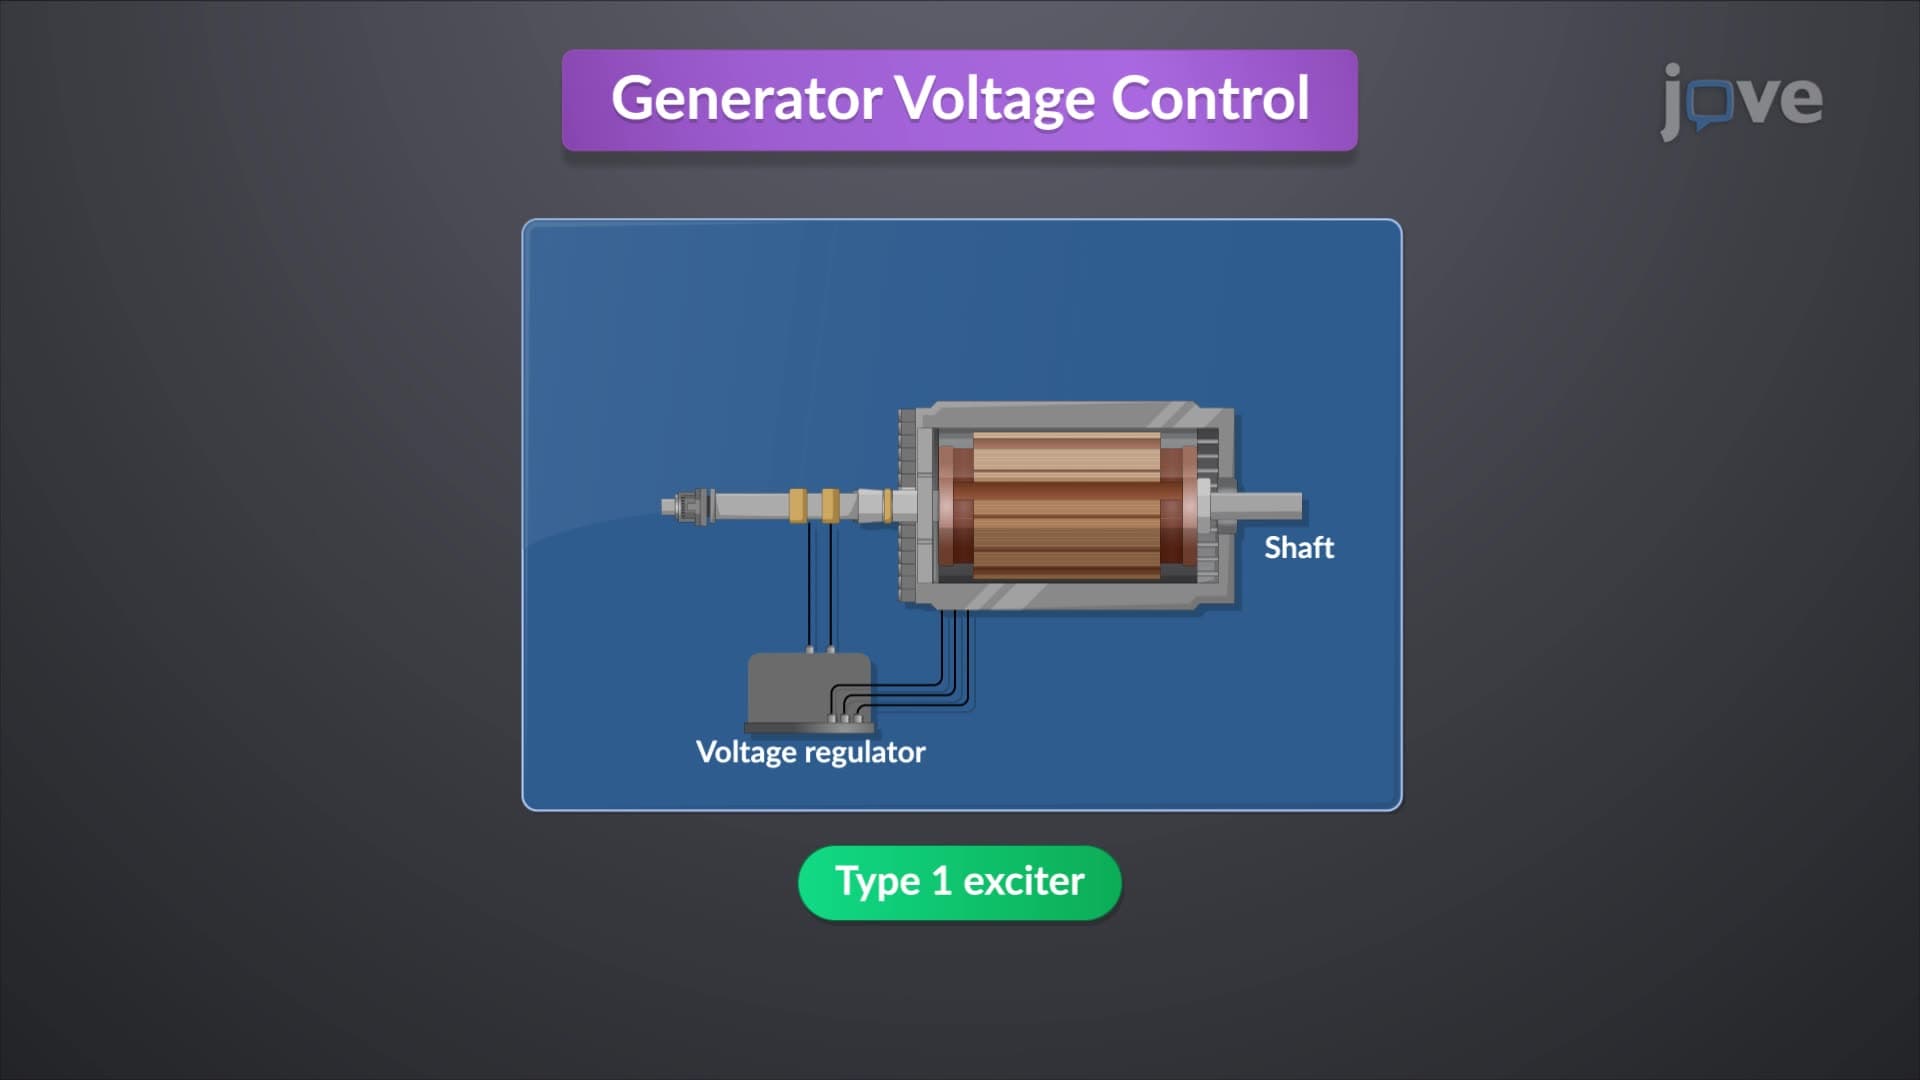
Generator Voltage Control
 01:24
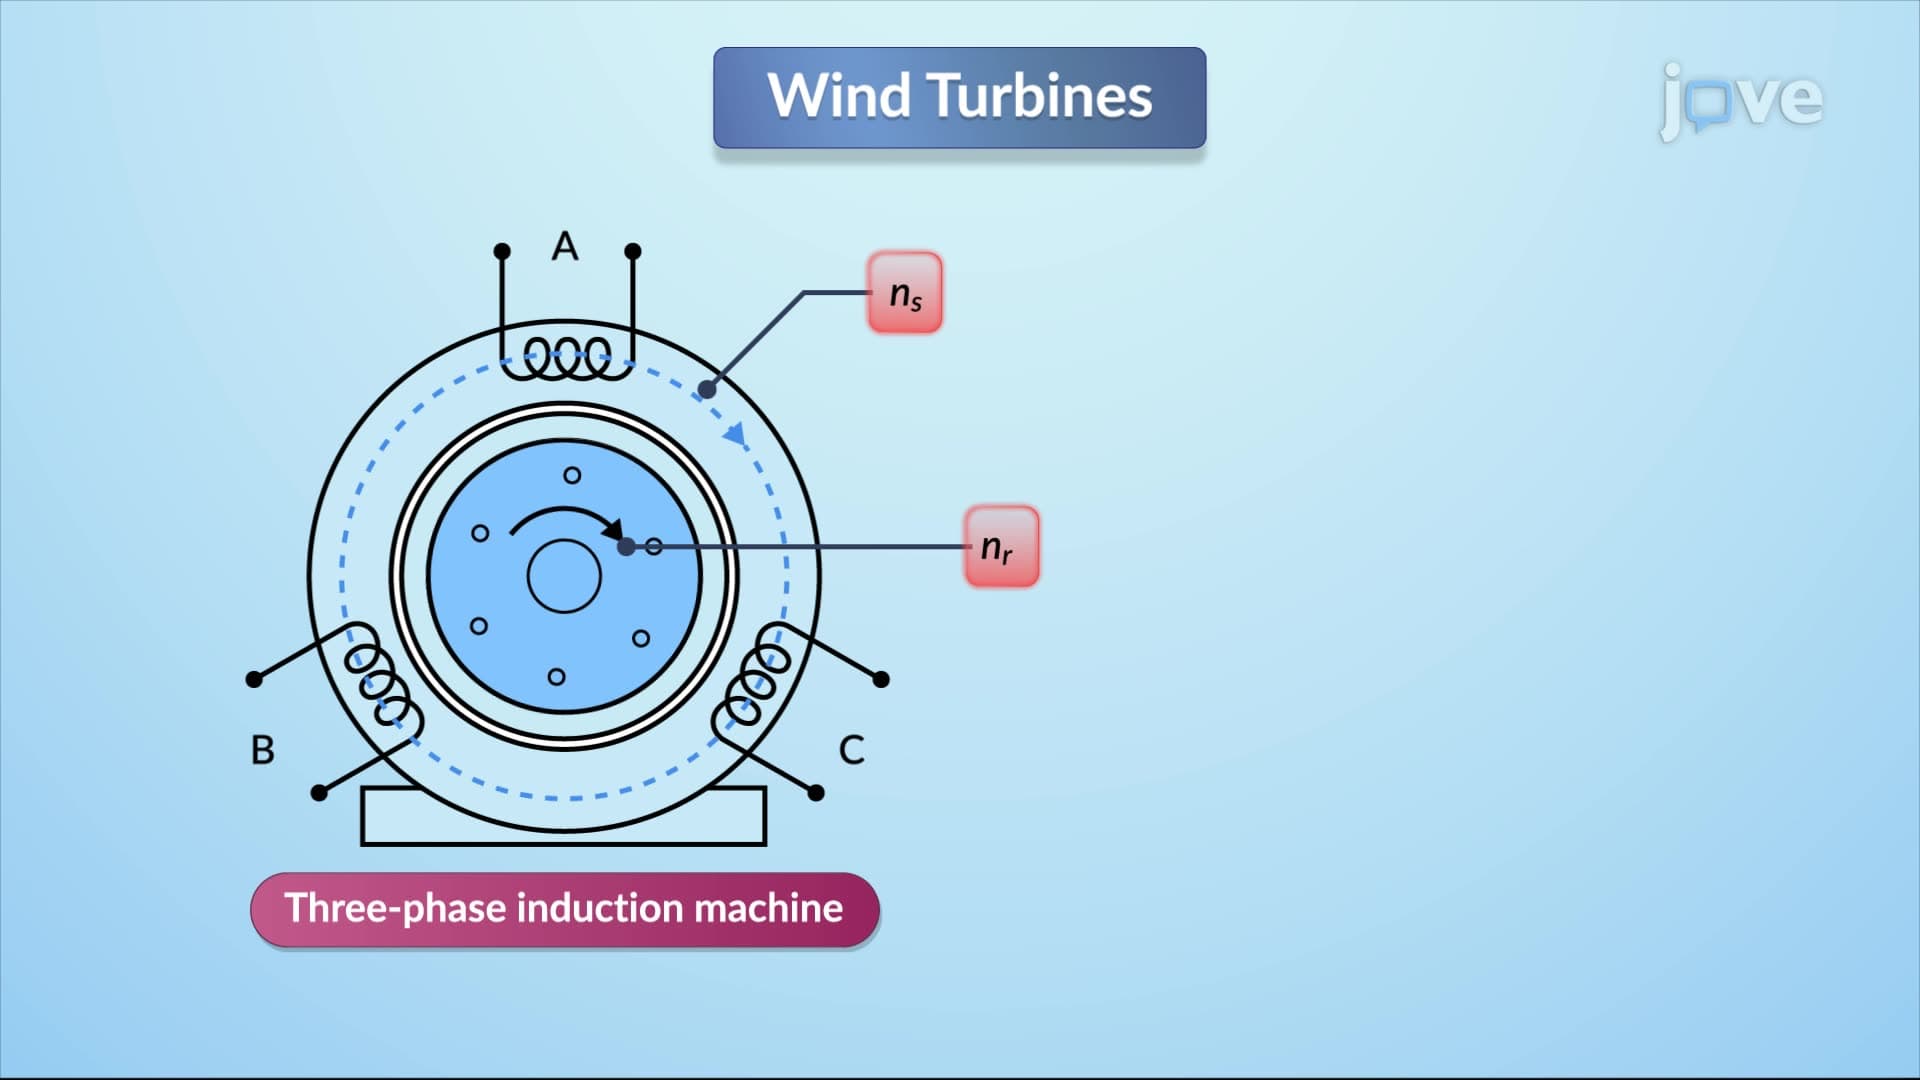
Wind Turbine Machine Models
Induction machines interact through the rotating magnetic field generated by the stator and the rotor. The key parameter is slip, which is the difference between synchronous speed and rotor speed relative to synchronous speed. Slip is...
 01:30
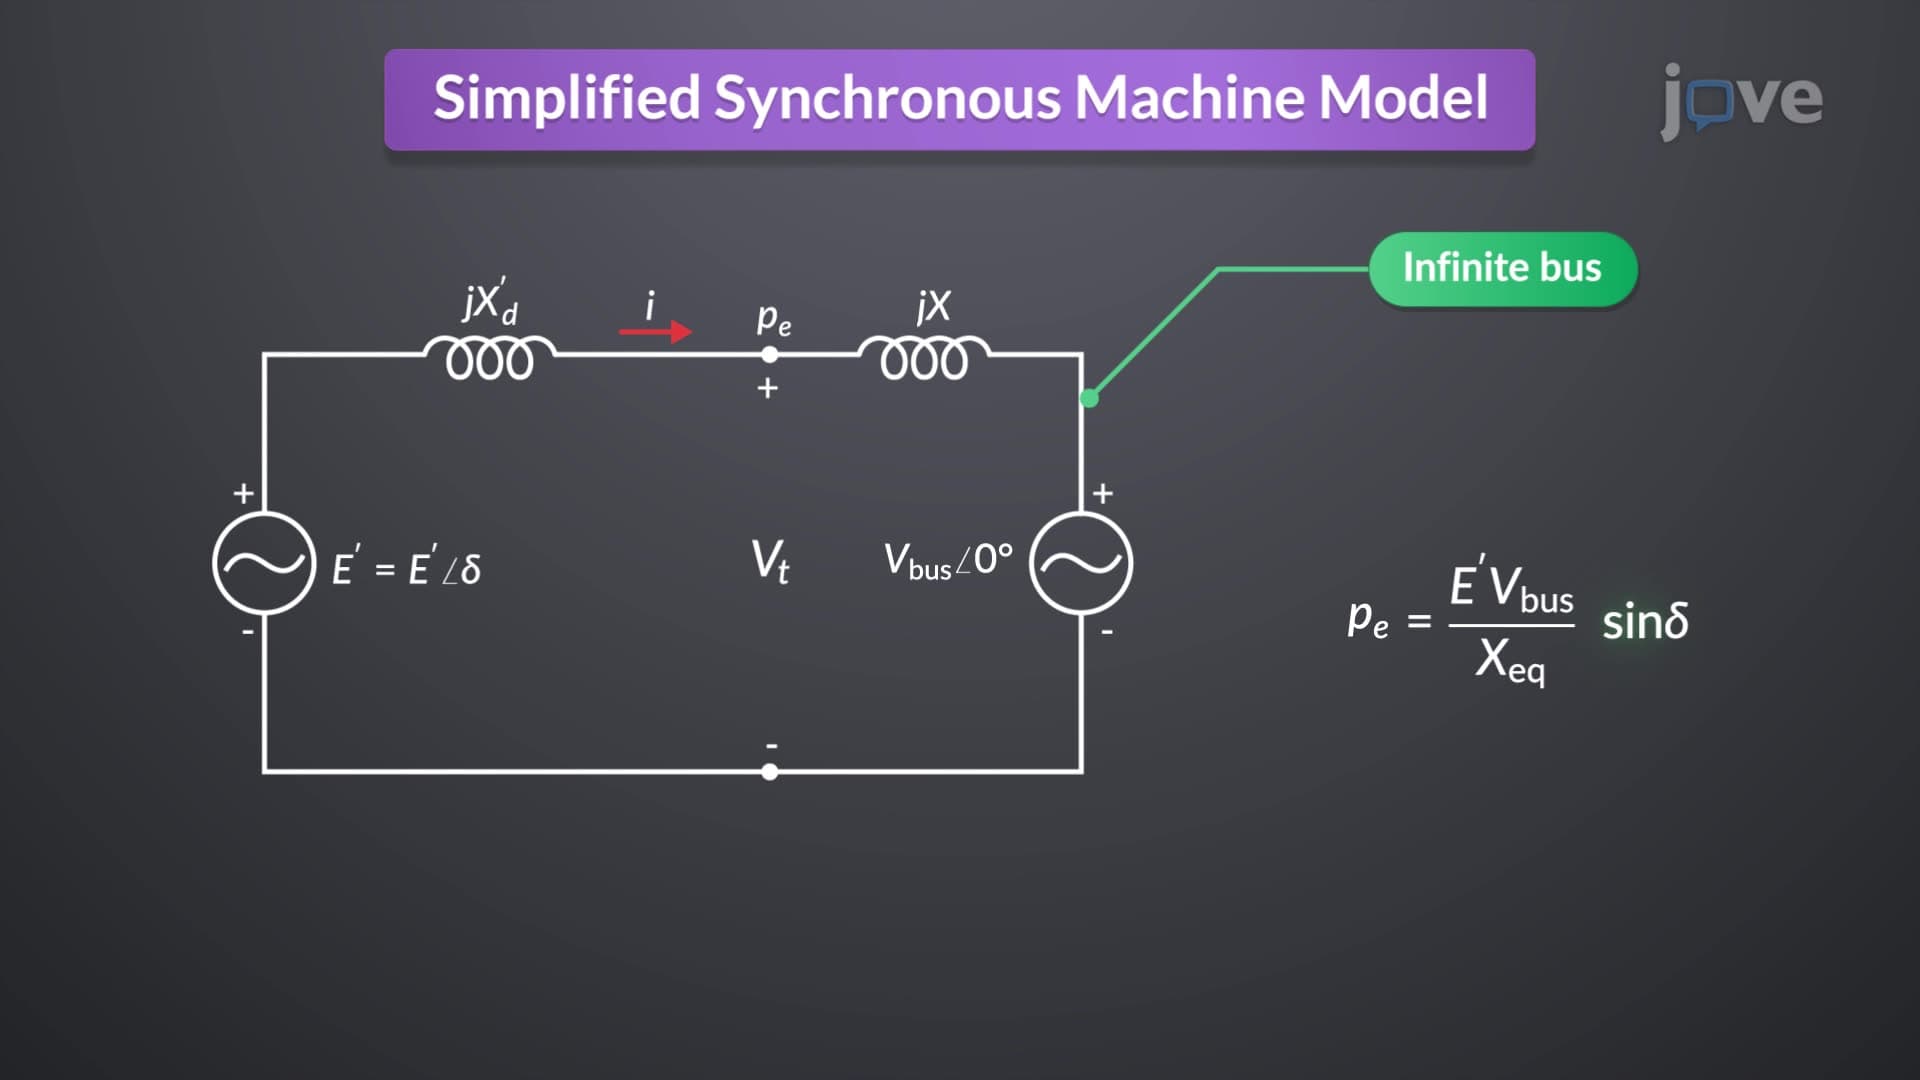
Simplified Synchronous Machine Model
In this model, each generator is connected to a...