Distributed L2-gain control of large-scale systems: A space construction approach
Related Experiment Video
Updated: Nov 17, 2025

Large Scale Energy Efficient Sensor Network Routing Using a Quantum Processor Unit
Published on: September 8, 2023
1Department of Automation, University of Science and Technology of China, Hefei 230026, China.

Abstract:
This note studies the distributed L2-gain control problem for discrete-time large-scale systems. The considered system is transformed equivalently to a high dimensional system. The classical controller design methods are not suitable to be applied directly due to the matrix inversion terms in the transformed system. Using a space construction approach, this paper derives necessary and sufficient stability conditions in the form of linear matrix inequalities for large-scale systems. In addition, under given L2-gain γ, necessary and sufficient conditions are established such that the considered system is asymptotically stable and the prescribed L2-gain is satisfied. Then, these results are used to design distributed controllers for large-scale systems. Based on a matrix construction method, distributed controllers can be constructed via the solutions of a set of linear matrix inequalities to guarantee that the closed-loop system is stable with the given L2-gain. Finally, the advantages of the proposed theoretical results are demonstrated by two examples.

Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
Distributed Loads: Problem Solving
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:16
SFG Algebra
Each node in an SFG corresponds to a variable, and the interactions between nodes are represented by branches with associated gains. When multiple branches lead into a node, the value at that node is the sum of the...
 01:21
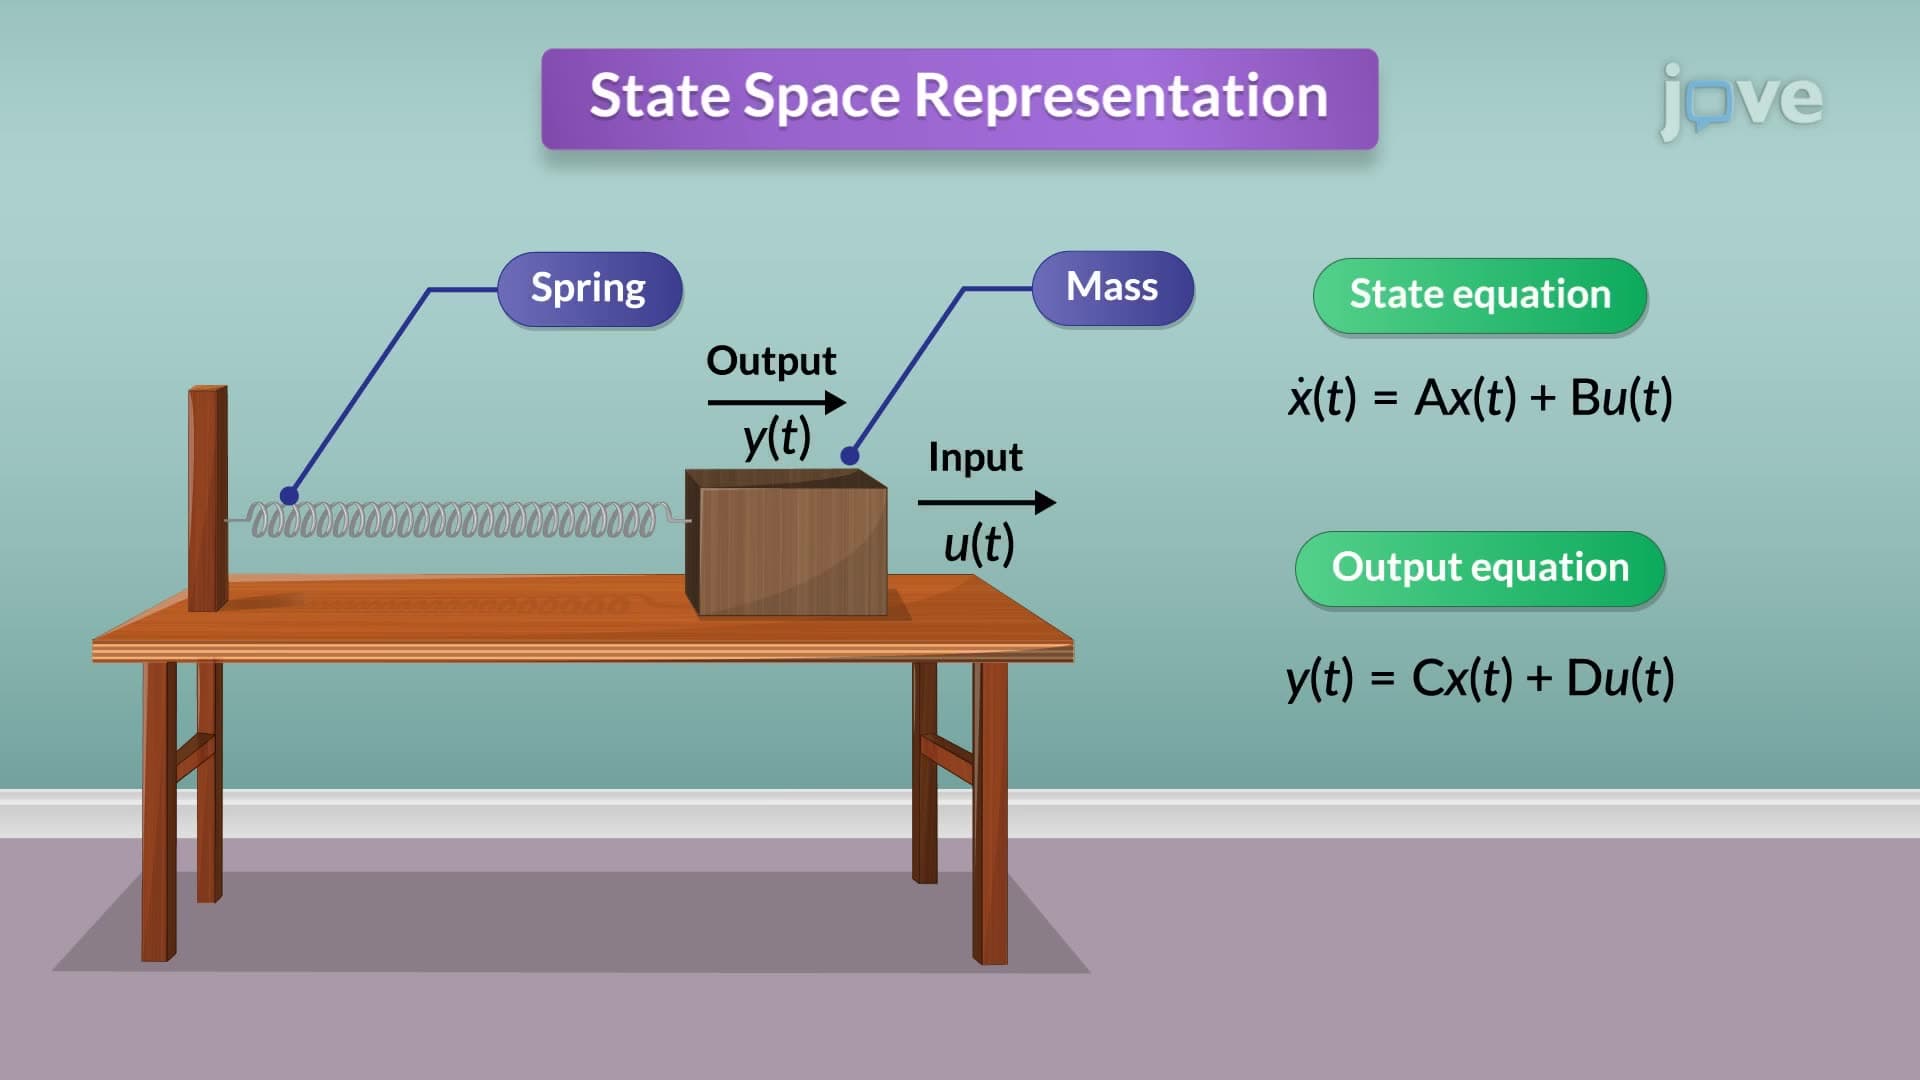
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: