Related Experiment Video
Updated: Nov 15, 2025
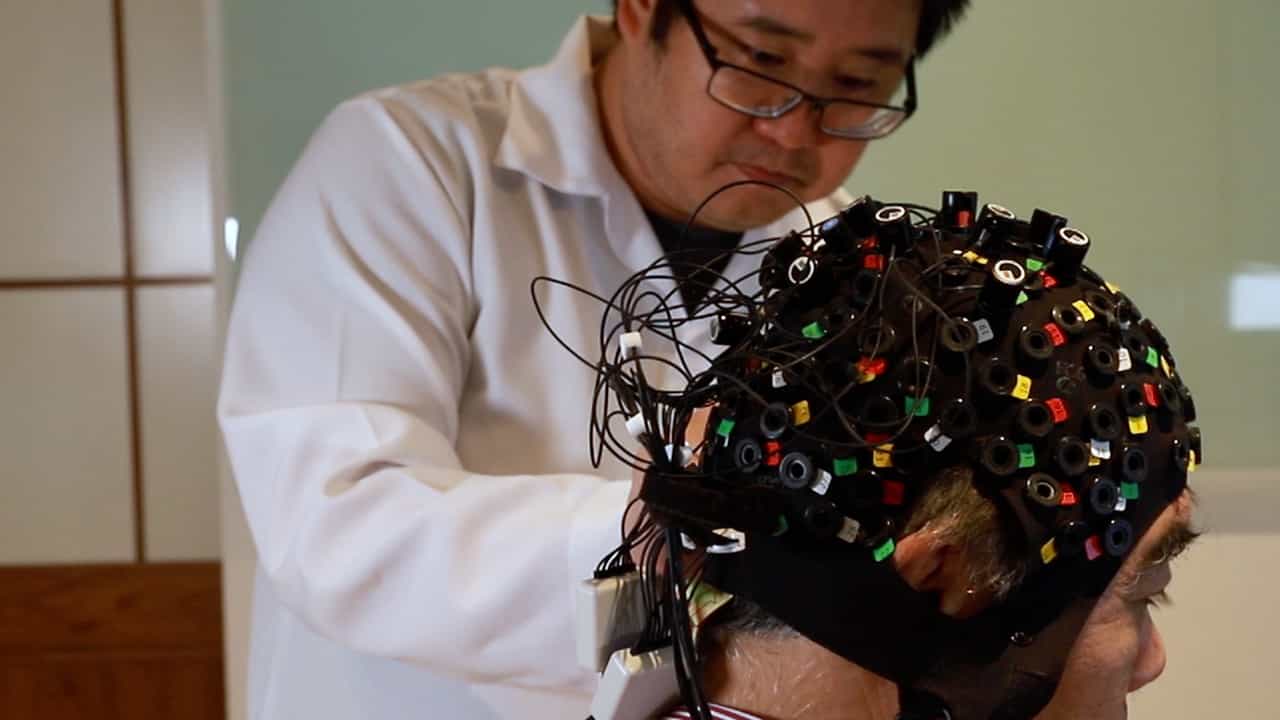
Author Spotlight: Assessing Brain Activity in Robotic-Assisted Lower Limb Rehabilitation Using fNIRS
Published on: June 7, 2024
Simulated muscle activity in locomotion: implications of co-occurrence between effort minimisation and gait
Marco Maddalena1, Mozafar Saadat1
1Department of Mechanical Engineering, School of Engineering, University of Birmingham, Birmingham, UK.

Abstract:
Evolution of gait rehabilitation robotic devices for stroke survivors has aimed at providing transparency to user's efforts and implementing 'assist-as-needed' paradigm. Alteration of muscle activity and synergies recruitment has been noticed in trials involving healthy subjects but no analytic tool has been proposed to understand root causes. In this paper, a simplified neuro-mechanical model is introduced for simulating lower limbs' muscle activity during unrestrained and device-constrained gait, taking into consideration exoskeleton-plus-treadmill and end-effector categories. Muscle control is based on the key hypothesis that optimality criterion pursues co-occurrence between effort minimisation and modularity during regular gait. Results highlight that modelised motion constraints on lower body raise additional redundancies which alter muscle activity and increase intervention external to unrestrained gait synergies. Accordingly, the developed simulations help to identify the inherent limitations of current technology: further degree of freedom addition to exoskeleton-plus-treadmill device could be useful but impractical, while end-effector devices would benefit significantly from an improved interaction management.
More Related Videos
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
 06:00
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025