Related Experiment Video
Updated: Nov 15, 2025


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Soft Finger Modelling and Co-Simulation Control towards Assistive Exoskeleton Hand Glove
Mohammed N El-Agroudy1, Mohammed I Awad1,2, Shady A Maged1
1Mechatronics Engineering Department, Faculty of Engineering, Ain Shams University, Cairo 11566, Egypt.

Abstract:
The soft pneumatic actuators of an assistive exoskeleton hand glove are here designed. The design of the actuators focuses on allowing the actuator to perform the required bending and to restrict elongation or twisting of the actuator. The actuator is then modeled using ABAQUS/CAE, a finite element modeling software, and the open loop response of the model is obtained. The parameters of the actuator are then optimized to reach the optimal parameters corresponding to the best performance. Design of experiment (DOE) techniques are then approached to study the robustness of the system. Software-in-the-loop (SiL) is then approached to control the model variables via a proportional-integral-derivative (PID) control generated by FORTRAN code. The link between the two programs is to be achieved by the user subroutine that is written, where the subroutine receives values from ABAQUS/CAE, performs calculations, and passes values back to the software. The controller's parameters are tuned and then the closed loop response of the model is obtained by setting the desired bending angle and running the model. Furthermore, a concentrated force at the tip of the actuator is added to observe the actuator's response to external disturbance.


Related Concept Videos
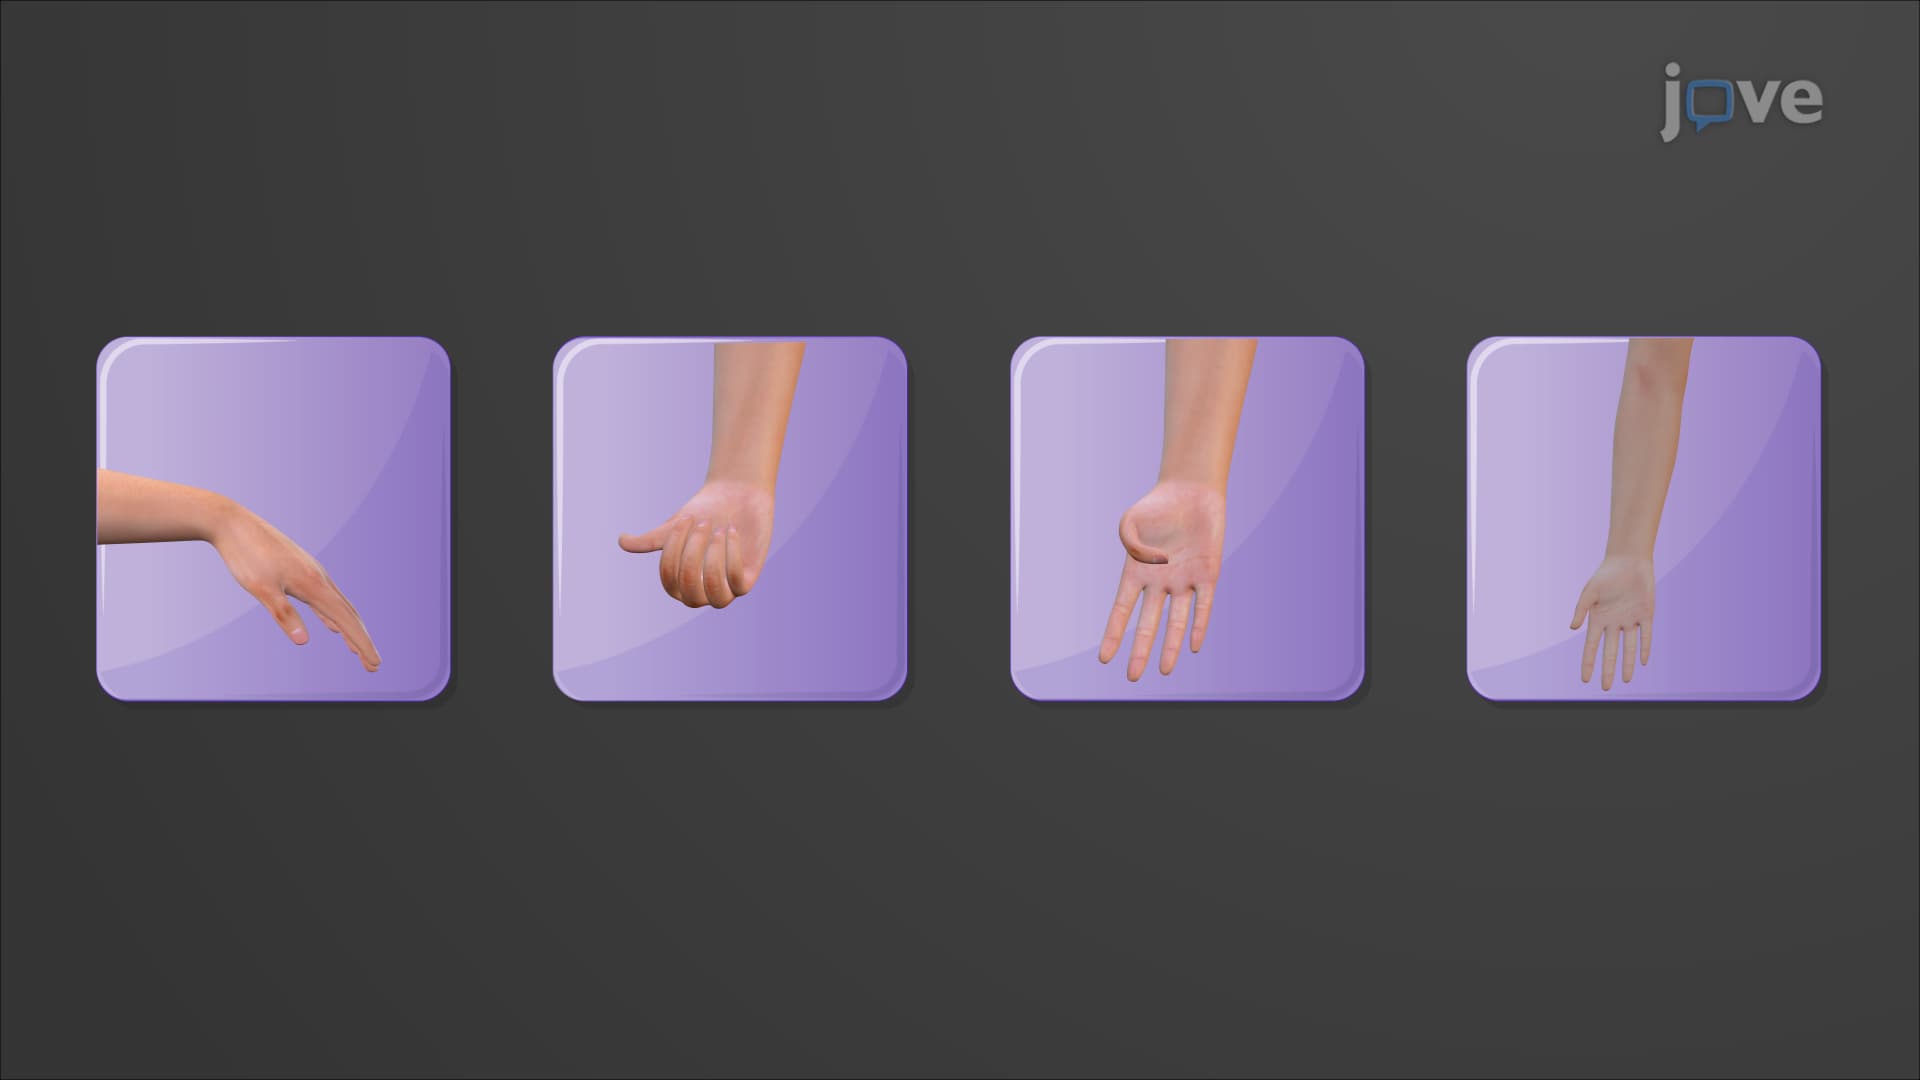 01:17
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...