Related Experiment Video
Updated: Nov 11, 2025
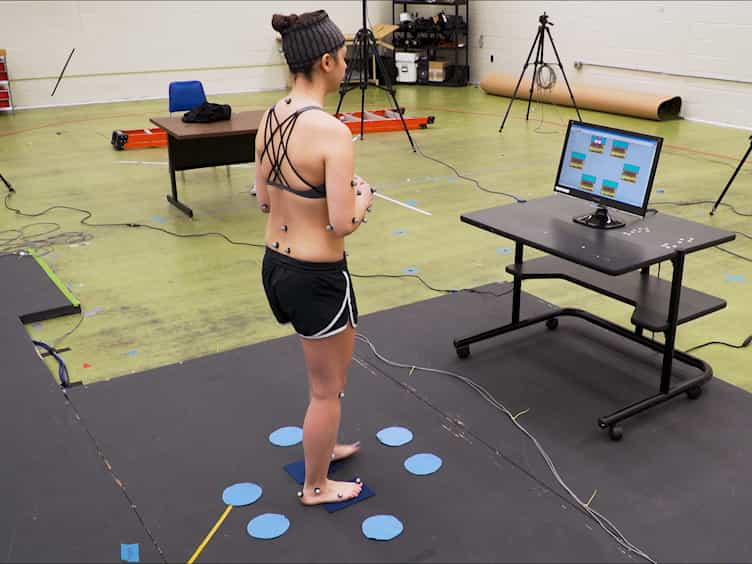

The "Motor" in Implicit Motor Sequence Learning: A Foot-stepping Serial Reaction Time Task
Published on: May 3, 2018
The Planning Horizon for Movement Sequences
Giacomo Ariani1,2, Neda Kordjazi3, J Andrew Pruszynski3,4,5,6
1The Brain and Mind Institute, Western University, London, Ontario N6A 3K7, Canada gariani@uwo.ca.

Abstract:
When performing a long chain of actions in rapid sequence, future movements need to be planned concurrently with ongoing action. However, how far ahead we plan, and whether this ability improves with practice, is currently unknown. Here, we designed an experiment in which healthy volunteers produced sequences of 14 finger presses quickly and accurately on a keyboard in response to numerical stimuli. On every trial, participants were only shown a fixed number of stimuli ahead of the current keypress. The size of this viewing window varied between 1 (next digit revealed with the pressing of the current key) and 14 (full view of the sequence). Participants practiced the task for 5 days, and their performance was continuously assessed on random sequences. Our results indicate that participants used the available visual information to plan multiple actions into the future, but that the planning horizon was limited: receiving information about more than three movements ahead did not result in faster sequence production. Over the course of practice, we found larger performance improvements for larger viewing windows and an expansion of the planning horizon. These findings suggest that the ability to plan future responses during ongoing movement constitutes an important aspect of skillful movement. Based on the results, we propose a framework to investigate the neuronal processes underlying simultaneous planning and execution.

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:15
Kinematic Equations: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...