Validation of smoothness evaluation during standing and sitting motions using an accelerometer
Related Experiment Video
Updated: Nov 10, 2025
A Vibrotactile Feedback Device for Seated Balance Assessment and Training
Published on: January 20, 2019
Takeshi Shimamura1, Hiroshi Katoh2
1Department of Rehabilitation, Kumamoto Kenhoku Hospital: 550 Tamana, Tamana-shi, Kumamoto 865-0005, Japan.

Abstract:
[Purpose] To quantitatively evaluate smoothness during standing and sitting motion analysis using an accelerometer and to clarify the relationship between indices. [Participants and Methods] Seventeen healthy males participated in this study. We attached a 9-axis motion sensor to the spinous process of the third lumbar spine and measured the acceleration of standing and sitting motions under normal and unstable conditions. We estimated and compared the root mean square and entropy in the lateral, vertical, longitudinal, and triaxial composite directions. [Results] On comparing both conditions, the unstable condition indices were significantly high, except for the lateral direction of entropy. The root mean square was significantly negatively correlated with entropy under normal conditions. [Conclusion] The study results suggested that the acceleration index quantitatively evaluates motion smoothness. Since each index had different characteristics, the motion-specific index was observed to be significant.
Related Concept Videos
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:10
Relative Motion Analysis - Acceleration
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:20
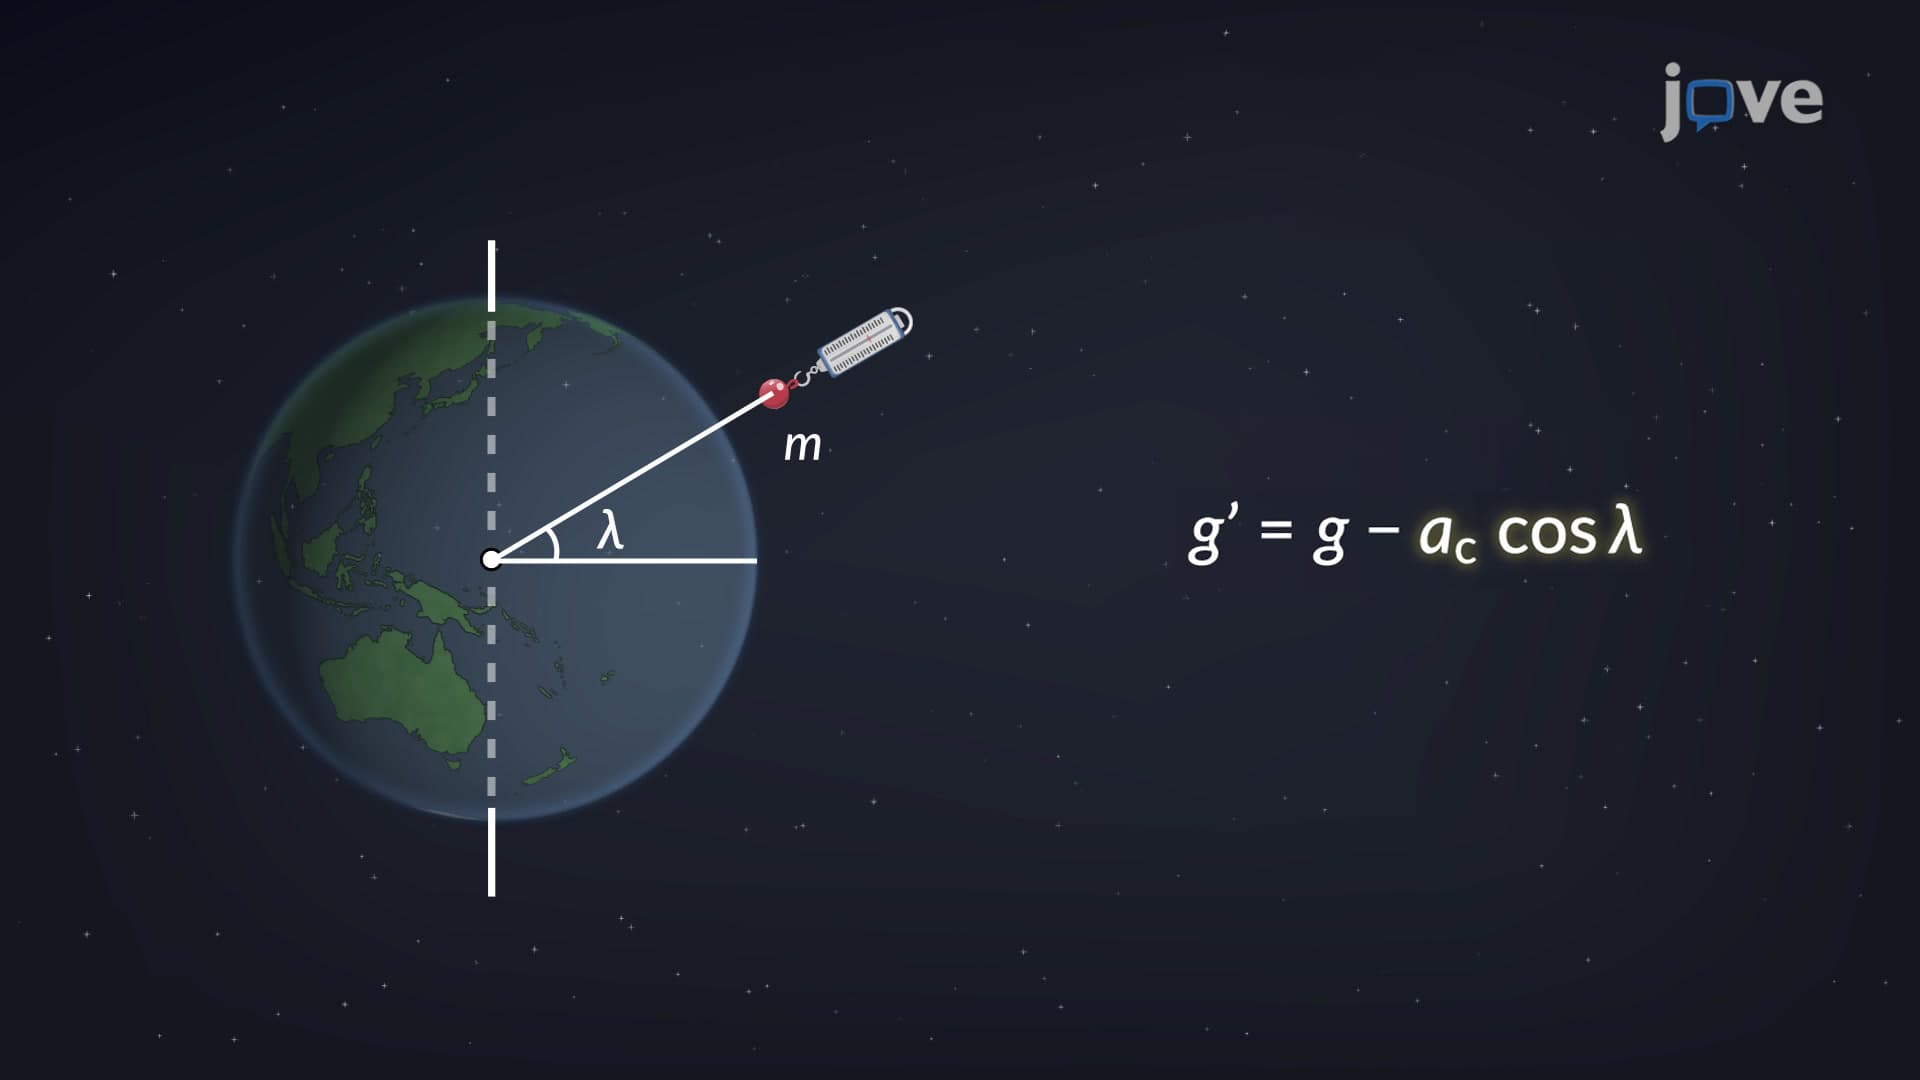
Variation in Acceleration due to Gravity near the Earth's Surface
The difference between the true and apparent weights is proportional to the square of the Earth's...