Related Experiment Video
Updated: Nov 8, 2025
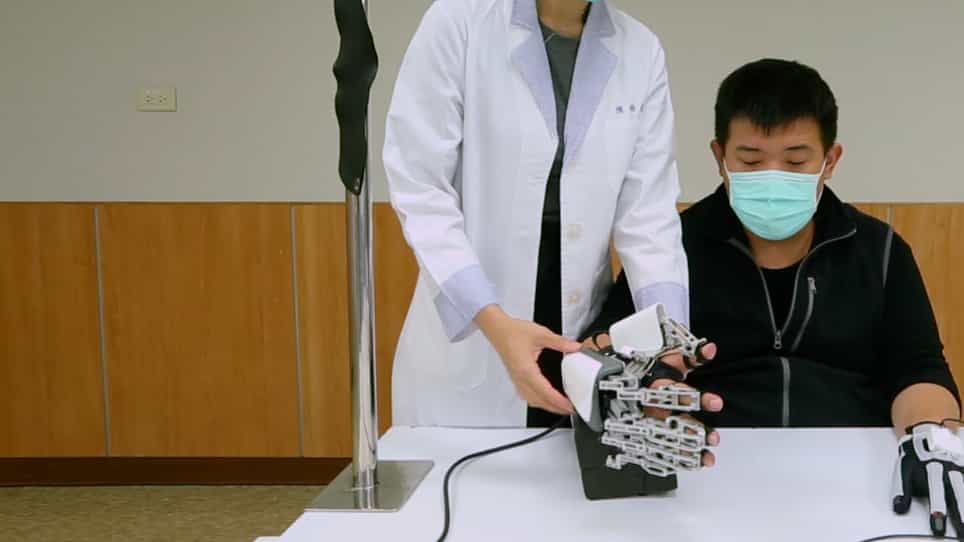
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
A Cable-Driven Three-DOF Wrist Rehabilitation Exoskeleton With Improved Performance
Ke Shi1, Aiguo Song1, Ye Li1
1School of Instrument Science and Engineering, Southeast University, Nanjing, China.

Abstract:
This paper developed a cable-driven three-degree-of-freedom (DOF) wrist rehabilitation exoskeleton actuated by the distributed active semi-active (DASA) system. Compared with the conventional cable-driven robots, the workspace of this robot is increased greatly by adding the rotating compensation mechanism and by optimizing the distribution of the cable attachment points. In the meanwhile, the efficiency of the cable tension is improved, and the parasitic force (the force acting on the joint along the limb) is reduced. Besides, in order to reduce the effects of compliant elements (e.g., cables or Bowden cables) between the actuators and output, and to improve the force bandwidth, we designed the DASA system composed of one geared DC motor and four magnetorheological (MR) clutches, which has low output inertia. A fast unbinding strategy is presented to ensure safety in abnormal conditions. A passive training algorithm and an assist-as-needed (AAN) algorithm were implemented to control the exoskeleton. Several experiments were conducted on both healthy and impaired subjects to test the performance and effectiveness of the proposed system for rehabilitation. The results show that the system can meet the needs of rehabilitation training for workspace and force-feedback, and provide efficient active and passive training.
More Related Videos
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
 03:55
Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023