Related Experiment Video
Updated: Nov 6, 2025

Human Fear Conditioning Conducted in Full Immersion 3-Dimensional Virtual Reality
Published on: August 9, 2010
DOE-SLAM: Dynamic Object Enhanced Visual SLAM
1Faculty of Engineering, University of Ottawa, Ottawa, ON K1N 6N5, Canada.

Abstract:
In this paper, we formulate a novel strategy to adapt monocular-vision-based simultaneous localization and mapping (vSLAM) to dynamic environments. When enough background features can be captured, our system not only tracks the camera trajectory based on static background features but also estimates the foreground object motion from object features. In cases when a moving object obstructs too many background features for successful camera tracking from the background, our system can exploit the features from the object and the prediction of the object motion to estimate the camera pose. We use various synthetic and real-world test scenarios and the well-known TUM sequences to evaluate the capabilities of our system. The experiments show that we achieve higher pose estimation accuracy and robustness over state-of-the-art monocular vSLAM systems.
Related Concept Videos
 01:11
Design Example: Forces in Sluice Gate
Key variables in...
 01:20
Slump Test
Concrete is poured into the mold in three layers to conduct the test. Each layer is compacted 25 times with a steel tamping rod, which has a five-eighths-inch diameter and a rounded end, to ensure even distribution and eliminate...
 01:07
Frictional Force
 01:19
Types of Collisions - II
 01:26
Kinetic Friction
 01:29
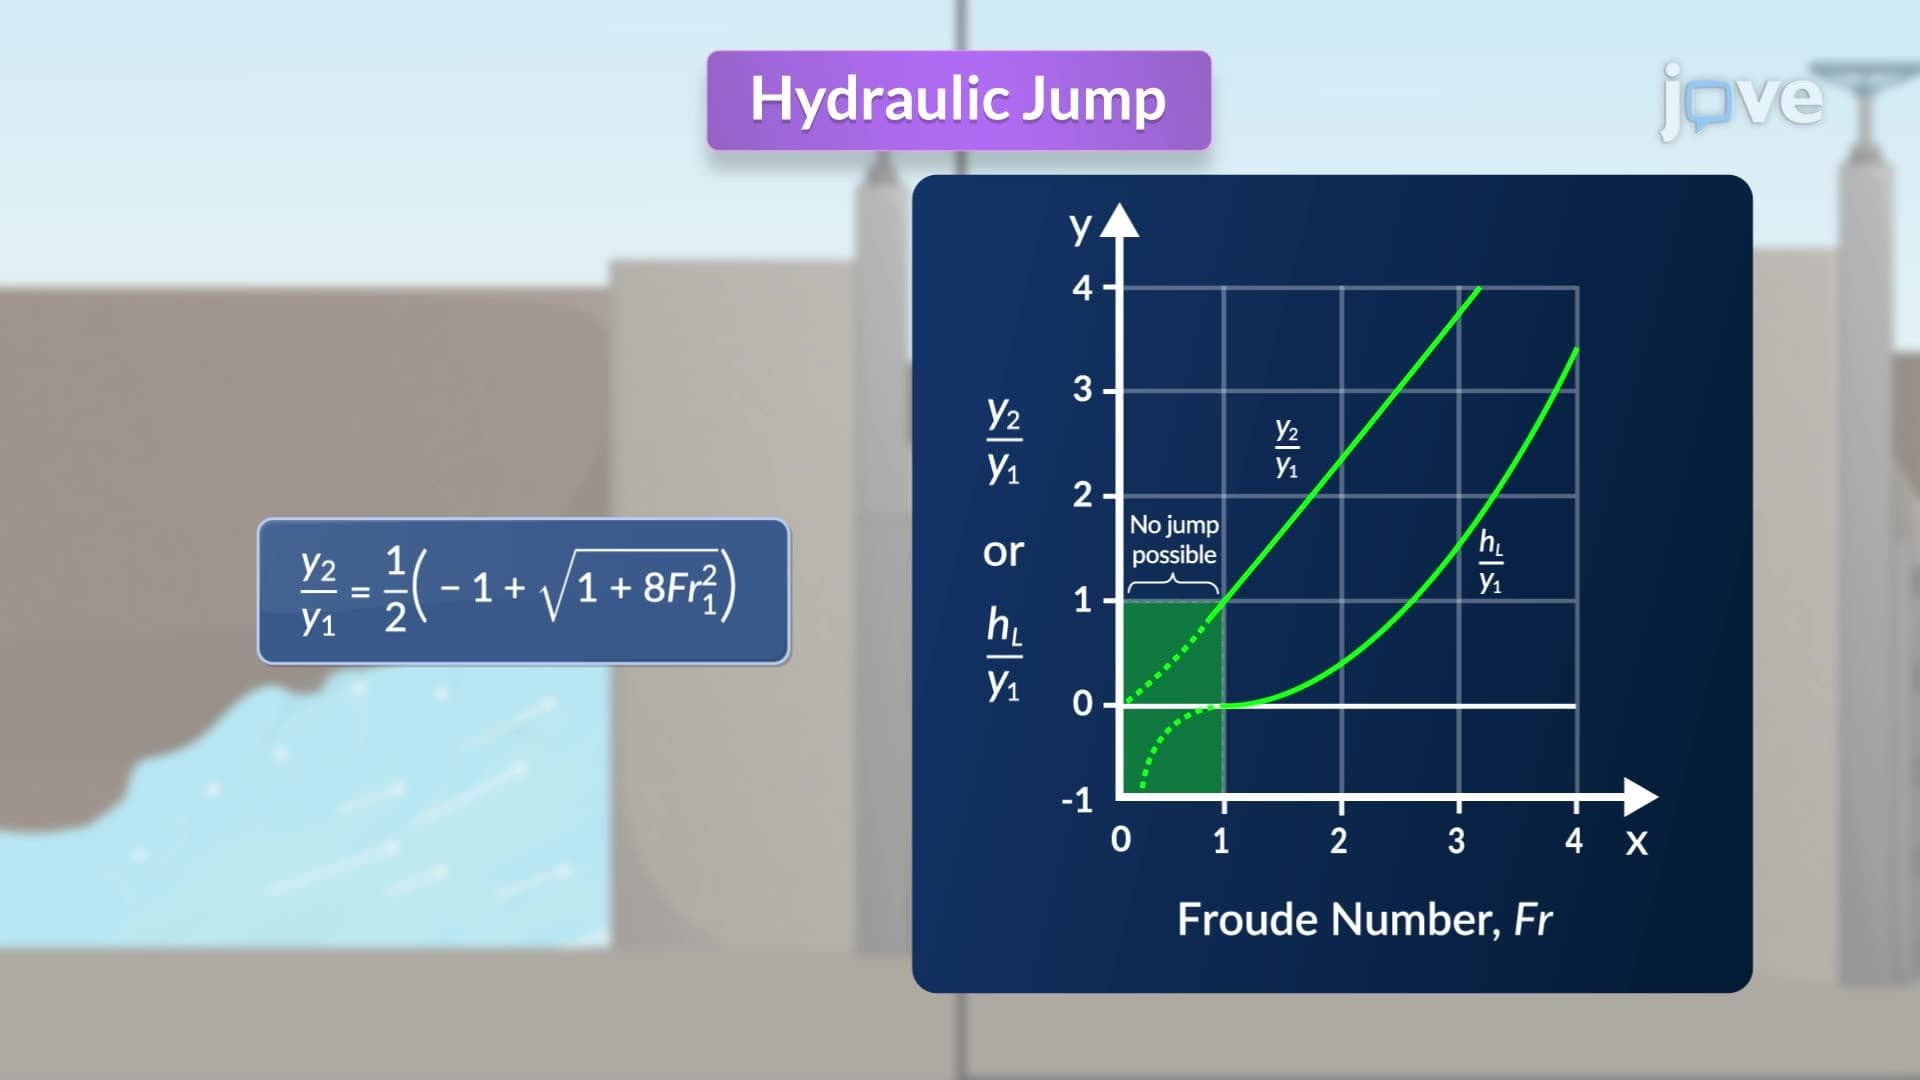
Hydraulic Jump