Related Experiment Video
Updated: Nov 5, 2025

Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Evolutionary design of magnetic soft continuum robots
Liu Wang1,2, Dongchang Zheng1, Pablo Harker3
1Department of Mechanical Engineering, Massachusetts Institute of Technology, Cambridge, MA 02139.

Abstract:
Worldwide cardiovascular diseases such as stroke and heart disease are the leading cause of mortality. While guidewire/catheter-based minimally invasive surgery is used to treat a variety of cardiovascular disorders, existing passive guidewires and catheters suffer from several limitations such as low steerability and vessel access through complex geometry of vasculatures and imaging-related accumulation of radiation to both patients and operating surgeons. To address these limitations, magnetic soft continuum robots (MSCRs) in the form of magnetic field-controllable elastomeric fibers have recently demonstrated enhanced steerability under remotely applied magnetic fields. While the steerability of an MSCR largely relies on its workspace-the set of attainable points by its end effector-existing MSCRs based on embedding permanent magnets or uniformly dispersing magnetic particles in polymer matrices still cannot give optimal workspaces. The design and optimization of MSCRs have been challenging because of the lack of efficient tools. Here, we report a systematic set of model-based evolutionary design, fabrication, and experimental validation of an MSCR with a counterintuitive nonuniform distribution of magnetic particles to achieve an unprecedented workspace. The proposed MSCR design is enabled by integrating a theoretical model and the genetic algorithm. The current work not only achieves the optimal workspace for MSCRs but also provides a powerful tool for the efficient design and optimization of future magnetic soft robots and actuators.

Related Concept Videos
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:18
Magnetic Force
The magnetic force acting on a moving charge...
 01:13
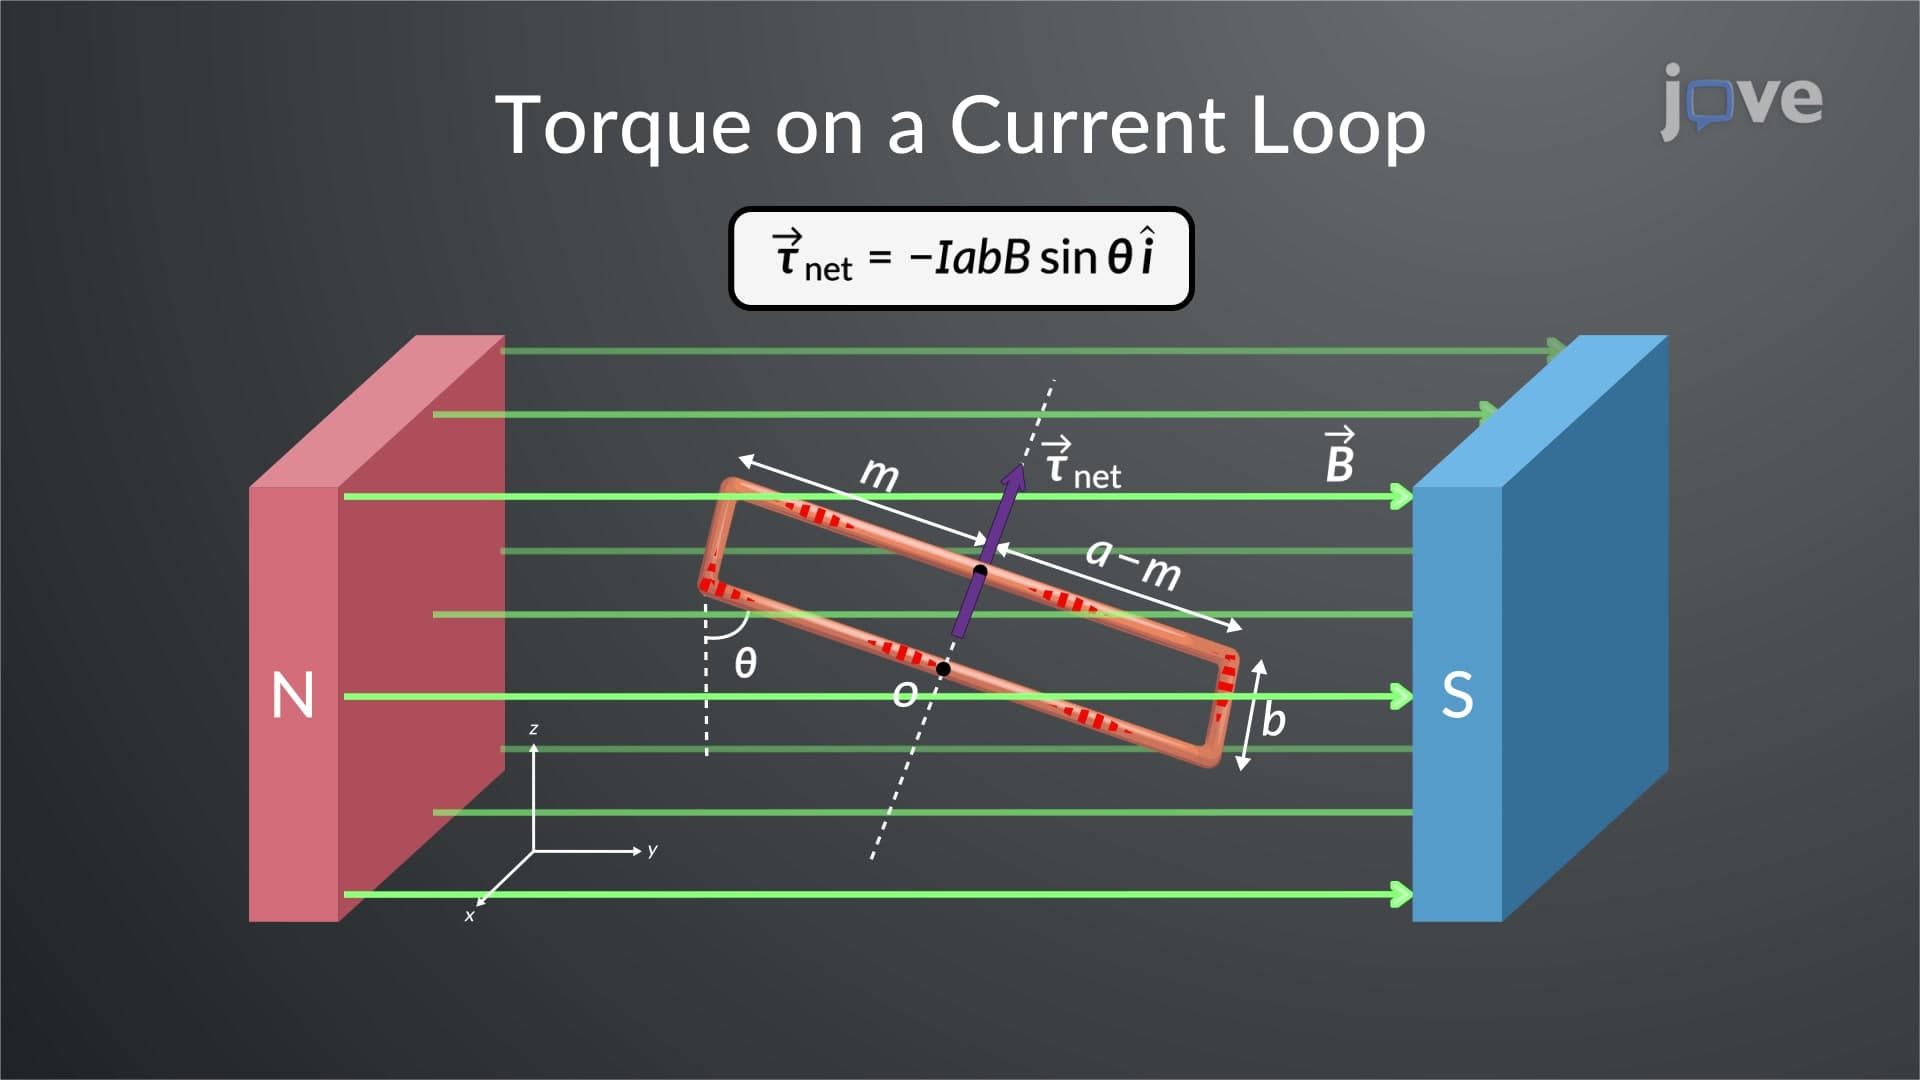
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:15
Magnetic Vector Potential
Consider an ideal solenoid with n turns per unit length and radius R. If I is the current through the solenoid, the magnetic field inside the solenoid is expressed as the product of vacuum...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:17
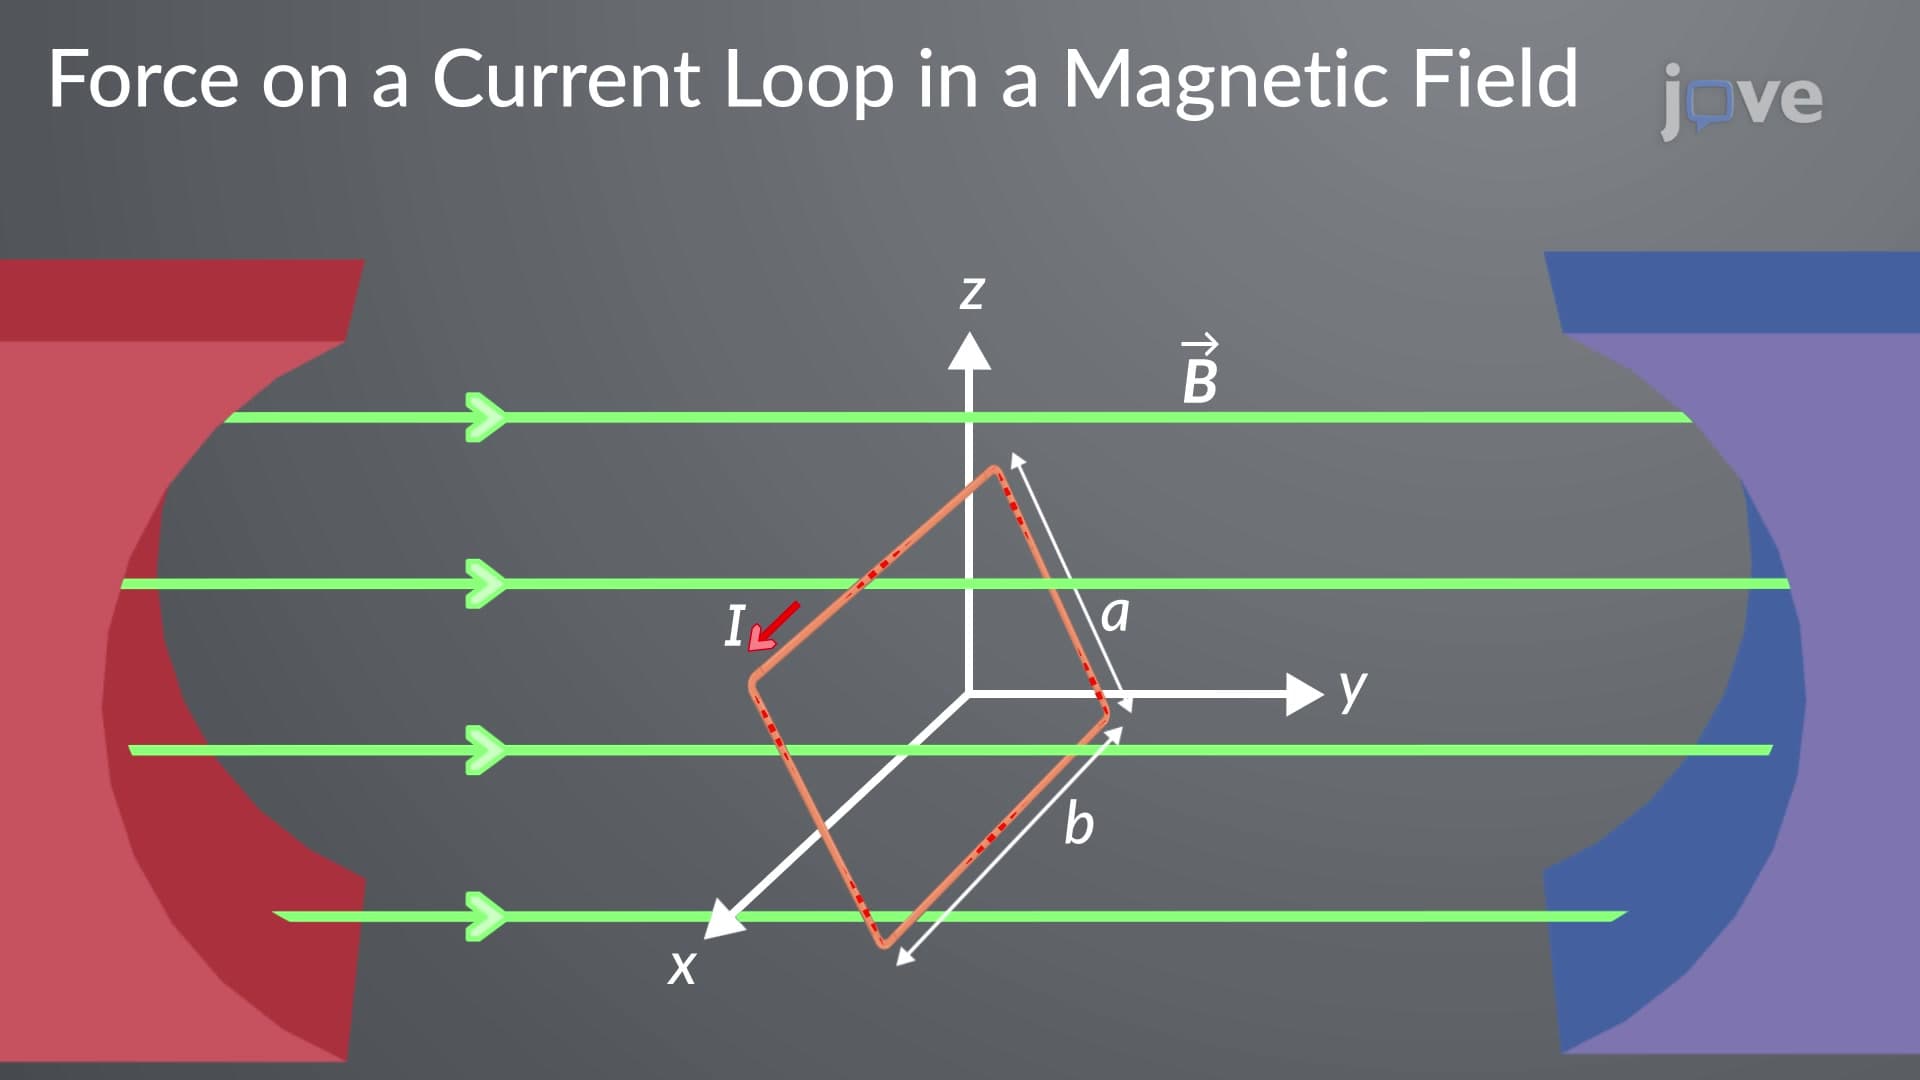
Force On A Current Loop In A Magnetic Field