Related Experiment Video
Updated: Nov 4, 2025
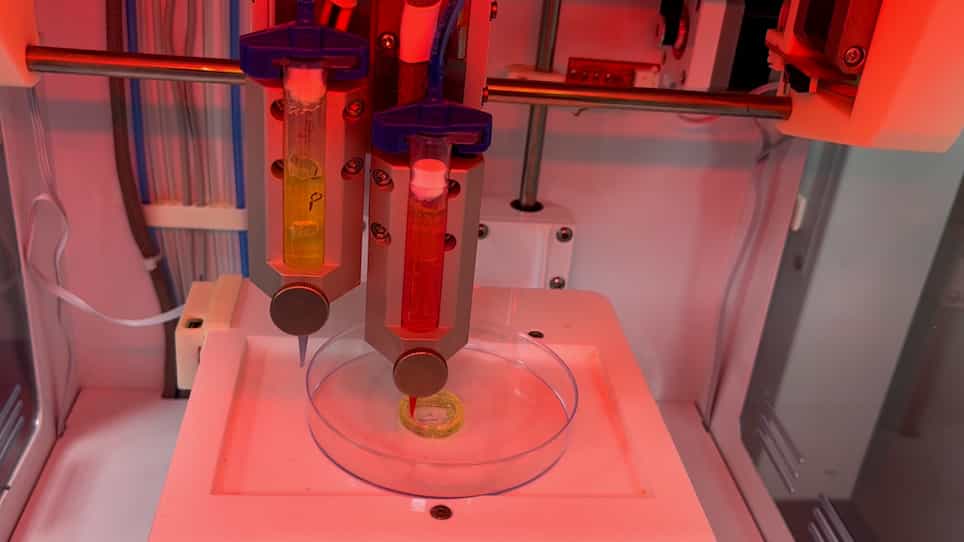

Four-Dimensional Printing of Stimuli-Responsive Hydrogel-Based Soft Robots
Published on: January 13, 2023
Robotic surfaces with reversible, spatiotemporal control for shape morphing and object manipulation
Ke Liu1, Felix Hacker1,2, Chiara Daraio3
1Division of Engineering and Applied Science, California Institute of Technology, 1200 E California Blvd, Pasadena, CA 91105, USA.

Abstract:
Continuous and controlled shape morphing is essential for soft machines to conform, grasp, and move while interacting safely with their surroundings. Shape morphing can be achieved with two-dimensional (2D) sheets that reconfigure into target 3D geometries, for example, using stimuli-responsive materials. However, most existing solutions lack the ability to reprogram their shape, face limitations on attainable geometries, or have insufficient mechanical stiffness to manipulate objects. Here, we develop a soft, robotic surface that allows for large, reprogrammable, and pliable shape morphing into smooth 3D geometries. The robotic surface consists of a layered design composed of two active networks serving as artificial muscles, one passive network serving as a skeleton, and cover scales serving as an artificial skin. The active network consists of a grid of strips made of heat-responsive liquid crystal elastomers (LCEs) containing stretchable heating coils. The magnitude and speed of contraction of the LCEs can be controlled by varying the input electric currents. The 1D contraction of the LCE strips activates in-plane and out-of-plane deformations; these deformations are both necessary to transform a flat surface into arbitrary 3D geometries. We characterize the fundamental deformation response of the layers and derive a control scheme for actuation. We demonstrate that the robotic surface provides sufficient mechanical stiffness and stability to manipulate other objects. This approach has potential to address the needs of a range of applications beyond shape changes, such as human-robot interactions and reconfigurable electronics.

