Related Experiment Video
Updated: Nov 3, 2025
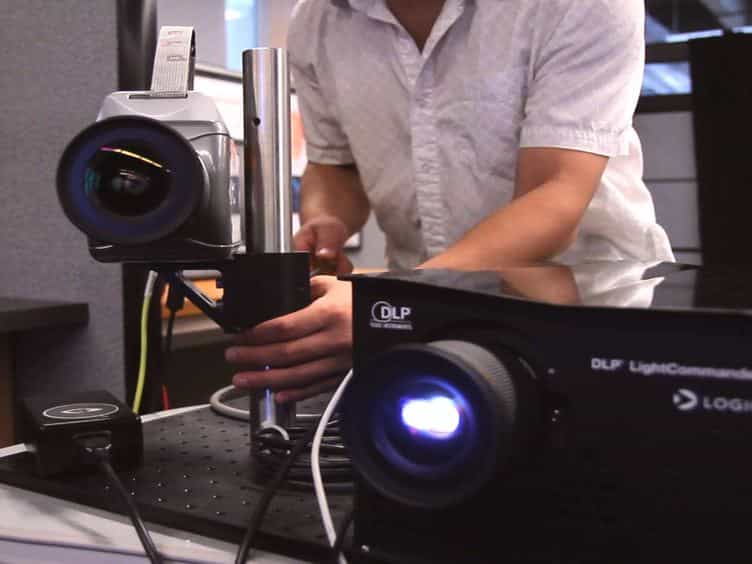

High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
A real-time IGRT method using a Kalman filter framework to extract 3D positions from 2D projections
Doan Trang Nguyen1,2, Paul Keall1, Jeremy Booth3,4
1School of Biomedical Engineering, University of Technology Sydney, Sydney, New South Wales, Australia.

Abstract:
Purpose.To estimate 3D prostate motion in real-time during irradiation from 2D prostate positions acquired from a kV imager on a standard linear accelerator utilising a Kalman filter (KF) framework. The advantage of this novel method is threefold: (1) eliminating the need of an initial learning period, therefore reducing patient imaging dose, (2) more robust against measurement noise and (3) more computationally efficient. In this paper, the novel KF method was evaluatedin silicousing patients' 3D prostate motion and simulated 2D projections.Methods.A KF framework was implemented to estimate 3D motion from 2D projection measurements in real-time during prostate cancer treatments. The noise covariance matrix was adaptively estimated from the previous 10 measurements. This method did not require an initial learning period as the KF process distribution was initialised using a population covariance matrix. This method was evaluated using a ground-truth motion dataset of 17 prostate cancer patients (536 trajectories) measured with electromagnetic transponders. 3D motion was projected onto a rotating imager (SID = 180 cm) (pixel size = 0.388 mm) and rotation speed of 6°/s and 2°/s to simulate VMAT treatments. Gantry-varying additive random noise (≤5 mm) was added to ground-truth measurements to simulate segmentation error and image quality degradation due to the patient's pelvic bones. For comparison, motion was also estimated using the clinically implemented Gaussian probability density function (PDF) method initialised with 600 projections.Results.Without noise, the 3D root mean square-errors (3D RMSEs) of motion estimated by the KF method were 0.4 ± 0.1 mm and 0.3 ± 0.2 mm for 2°/s and 6°/s gantry rotation, respectively. With noise, 3D RMSEs of KF estimated motion were 1.1 ± 0.1 mm for both slow and fast gantry rotation scenarios. In comparison, using a Gaussian PDF method, with noise, 3D RMSE was 2 ± 0.1 mm for both gantry rotation scenarios.Conclusion.This work presents a fast and accurate method for real-time 2D to 3D motion estimation using a KF approach to handle the random-walk component of prostate cancer motion. This method has sub-mm accuracy and is highly robust against measurement noise.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...