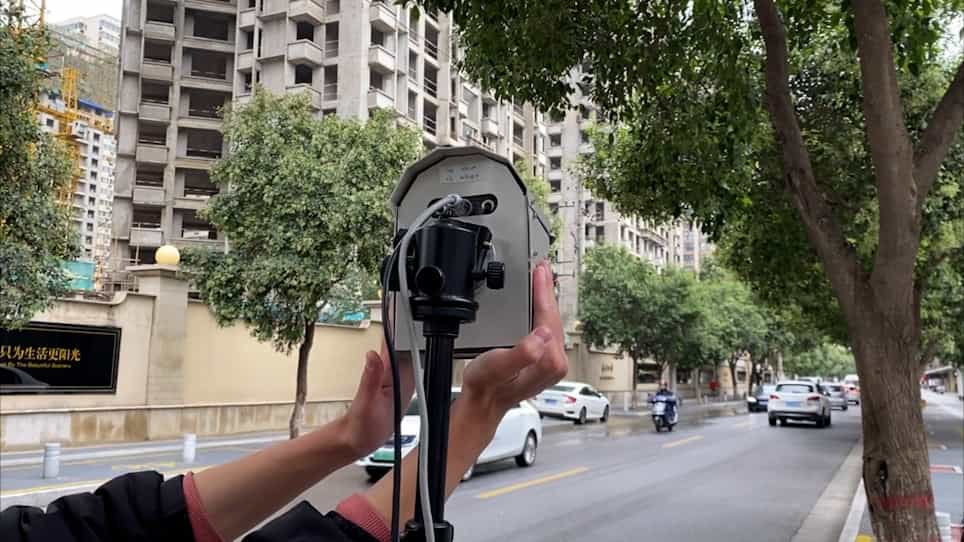
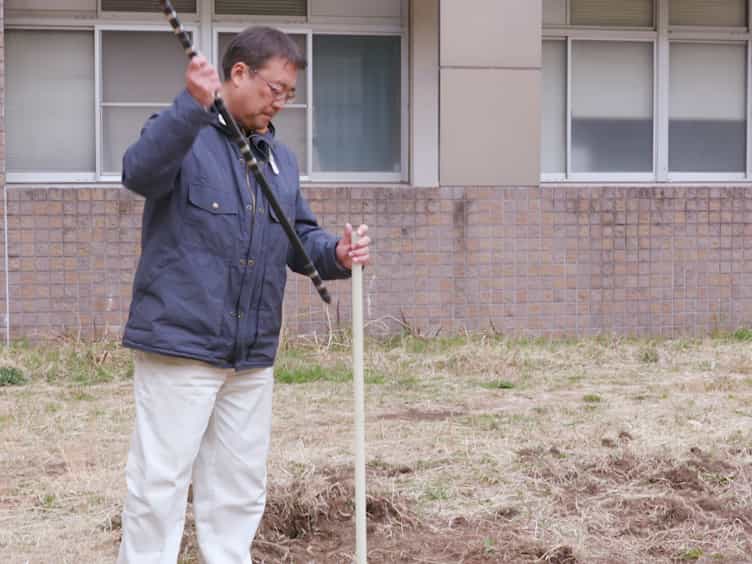
Related Experiment Video
Updated: Nov 3, 2025


Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
Pedestrian Detection in Blind Area and Motion Classification Based on Rush-Out Risk Using Micro-Doppler Radar
Sora Hayashi1, Kenshi Saho1,2, Daiki Isobe1
1Department of Electronic and Computer Engineering, Ritsumeikan University, Shiga 525-8577, Japan.

Abstract:
Various remote sensing technologies have been applied in intelligent vehicles and robots for surrounding-environment recognition. However, these technologies experience difficulties in detecting pedestrians in blind areas and their motions, such as rush-out behaviors. To address this issue, we present a radar-based technique for the detection of pedestrians in blind areas and the classification of different risks of rush-out behaviors among detected pedestrians. We verify their ability to detect pedestrian motion in blind areas by conducting experiments in two environments with blind areas formed by outdoor cars and indoor walls. Then, the classification of motions with different risks of rush-out behaviors among pedestrians detected in the blind areas is demonstrated. We use the clustering method to accurately classify several types of behaviors with different rush-out risks in both environments.