Related Experiment Video
Updated: Nov 3, 2025

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Collision Avoidance and Stability Study of a Self-Reconfigurable Drainage Robot
Rizuwana Parween1, M A Viraj J Muthugala1, Manuel V Heredia2
1Engineering Product Development, Singapore University of Technology and Design, 8 Somapah Road, Singapore 487372, Singapore.

Abstract:
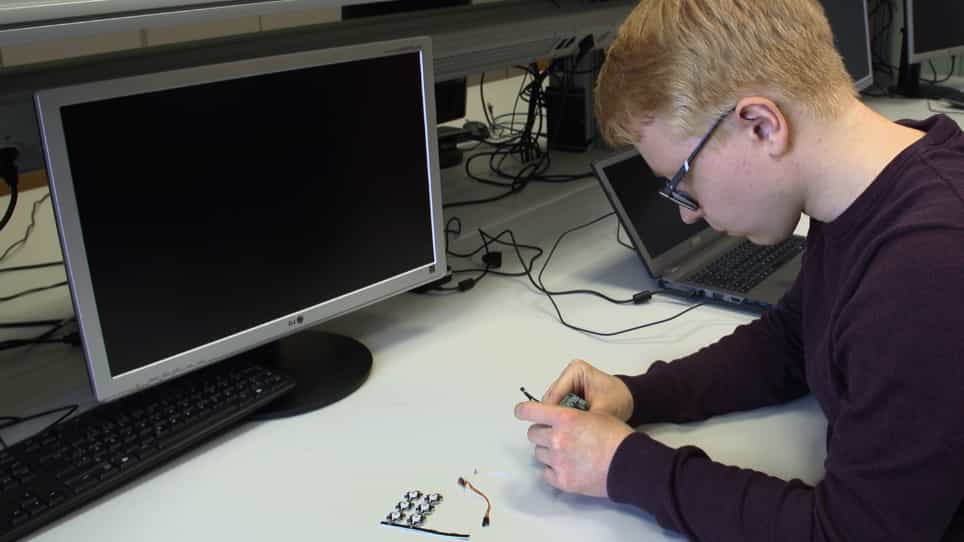
The inspection and maintenance of drains with varying heights necessitates a drain mapping robot with trained labour to maintain community hygiene and prevent the spread of diseases. For adapting to level changes and navigating in the narrow confined environments of drains, we developed a self-configurable hybrid robot, named Tarantula-II. The platform is a quadruped robot with hybrid locomotion and the ability to reconfigure to achieve variable height and width. It has four legs, and each leg is made of linear actuators and modular rolling wheel mechanisms with bi-directional movement. The platform has a fuzzy logic system for collision avoidance of the side wall in the drain environment. During level shifting, the platform achieves stability by using the pitch angle as the feedback from the inertial measuring unit (IMU) mounted on the platform. This feedback helps to adjust the accurate height of the platform. In this paper, we describe the detailed mechanical design and system architecture, kinematic models, control architecture, and stability of the platform. We deployed the platform both in a lab setting and in a real-time drain environment to demonstrate the wall collision avoidance, stability, and level shifting capabilities of the platform.

Related Concept Videos
 01:16
Hydraulic Jump: Problem Solving
 01:17
Rolling Resistance: Problem Solving
 01:21
Design Example: Creating a Hydraulic Model of a Dam Spillway
 01:27
Design Example: Design of an Irrigation Channel
 01:11
Design Example: Forces in Sluice Gate
Key variables in...