Related Experiment Video
Updated: Nov 3, 2025
Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
A Novel Graph-Based Trajectory Predictor With Pseudo-Oracle

Abstract:
Pedestrian trajectory prediction in dynamic scenes remains a challenging and critical problem in numerous applications, such as self-driving cars and socially aware robots. Challenges concentrate on capturing pedestrians' motion patterns and social interactions, as well as handling the future uncertainties. Recent studies focus on modeling pedestrians' motion patterns with recurrent neural networks, capturing social interactions with pooling- or graph-based methods, and handling future uncertainties by using the random Gaussian noise as the latent variable. However, they do not integrate specific obstacle avoidance experiences (OAEs) that may improve prediction performance. For example, pedestrians' future trajectories are always influenced by others in front. Here, we propose the Graph-based Trajectory Predictor with Pseudo-Oracle (GTPPO), an encoder-decoder-based method conditioned on pedestrians' future behaviors. Pedestrians' motion patterns are encoded with a long short-term memory unit, which introduces temporal attention to highlight specific time steps. Their interactions are captured by a graph-based attention mechanism, which draws OAE into the data-driven learning process of graph attention. Future uncertainties are handled by generating multimodal outputs with an informative latent variable. Such a variable is generated by a novel pseudo-oracle predictor, which minimizes the knowledge gap between historical and ground-truth trajectories. Finally, the GTPPO is evaluated on ETH, UCY, and Stanford Drone datasets, and the results demonstrate state-of-the-art performance. Besides, the qualitative evaluations show successful cases of handling sudden motion changes in the future. Such findings indicate that GTPPO can peek into the future.
Related Concept Videos
 01:07
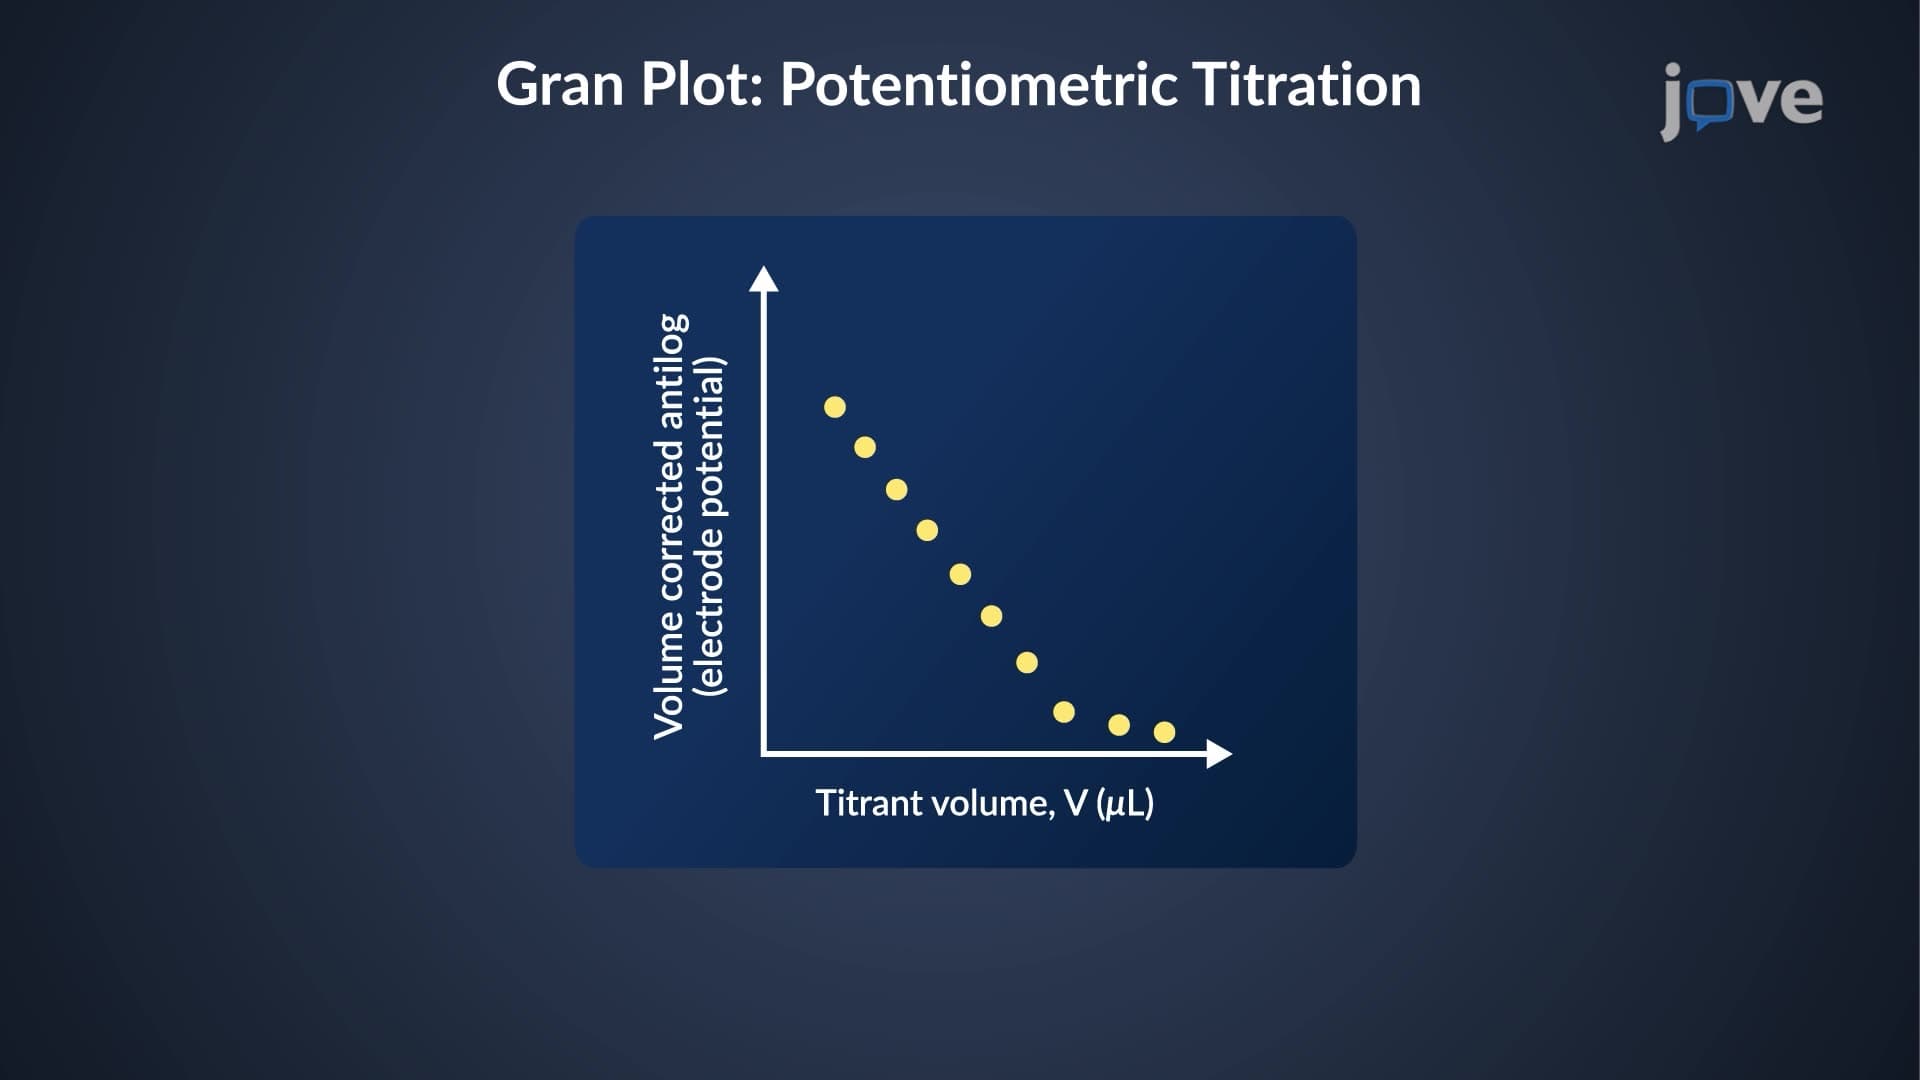
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting...
 01:34
Velocity and Position by Graphical Method
 01:03
Prediction Intervals
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 02:07
Improving Translational Accuracy
02:07Improving Translational Accuracy