Related Experiment Video
Updated: Nov 2, 2025
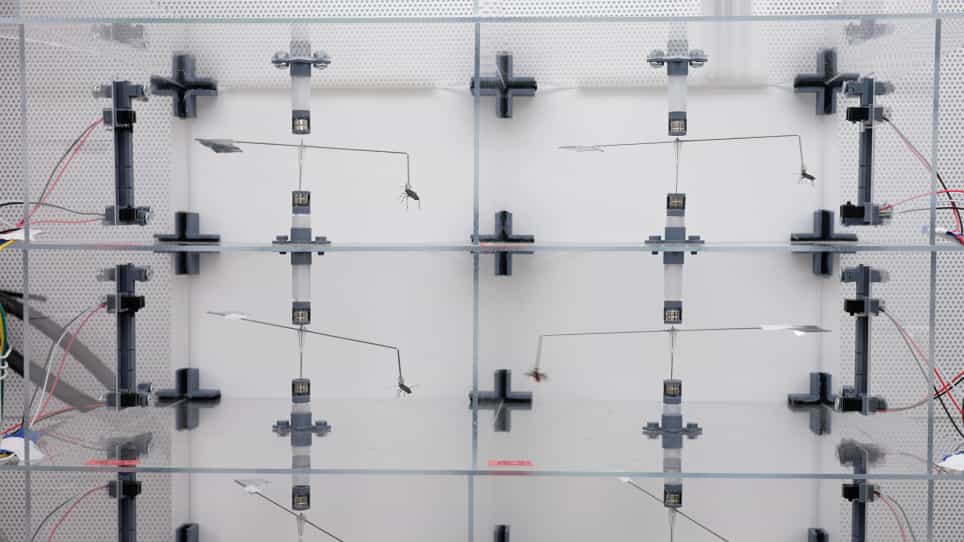

Building an Enhanced Flight Mill for the Study of Tethered Insect Flight
Published on: March 10, 2021
Gull-inspired joint-driven wing morphing allows adaptive longitudinal flight control
C Harvey1, V B Baliga2, C D Goates3
1Department of Aerospace Engineering, University of Michigan, Ann Arbor, MI 48109, USA.

Abstract:
Birds dynamically adapt to disparate flight behaviours and unpredictable environments by actively manipulating their skeletal joints to change their wing shape. This in-flight adaptability has inspired many unmanned aerial vehicle (UAV) wings, which predominately morph within a single geometric plane. By contrast, avian joint-driven wing morphing produces a diverse set of non-planar wing shapes. Here, we investigated if joint-driven wing morphing is desirable for UAVs by quantifying the longitudinal aerodynamic characteristics of gull-inspired wing-body configurations. We used a numerical lifting-line algorithm (MachUpX) to determine the aerodynamic loads across the range of motion of the elbow and wrist, which was validated with wind tunnel tests using three-dimensional printed wing-body models. We found that joint-driven wing morphing effectively controls lift, pitching moment and static margin, but other mechanisms are required to trim. Within the range of wing extension capability, specific paths of joint motion (trajectories) permit distinct longitudinal flight control strategies. We identified two unique trajectories that decoupled stability from lift and pitching moment generation. Further, extension along the trajectory inherent to the musculoskeletal linkage system produced the largest changes to the investigated aerodynamic properties. Collectively, our results show that gull-inspired joint-driven wing morphing allows adaptive longitudinal flight control and could promote multifunctional UAV designs.
Related Concept Videos
 01:54
Convergent Evolution
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:16
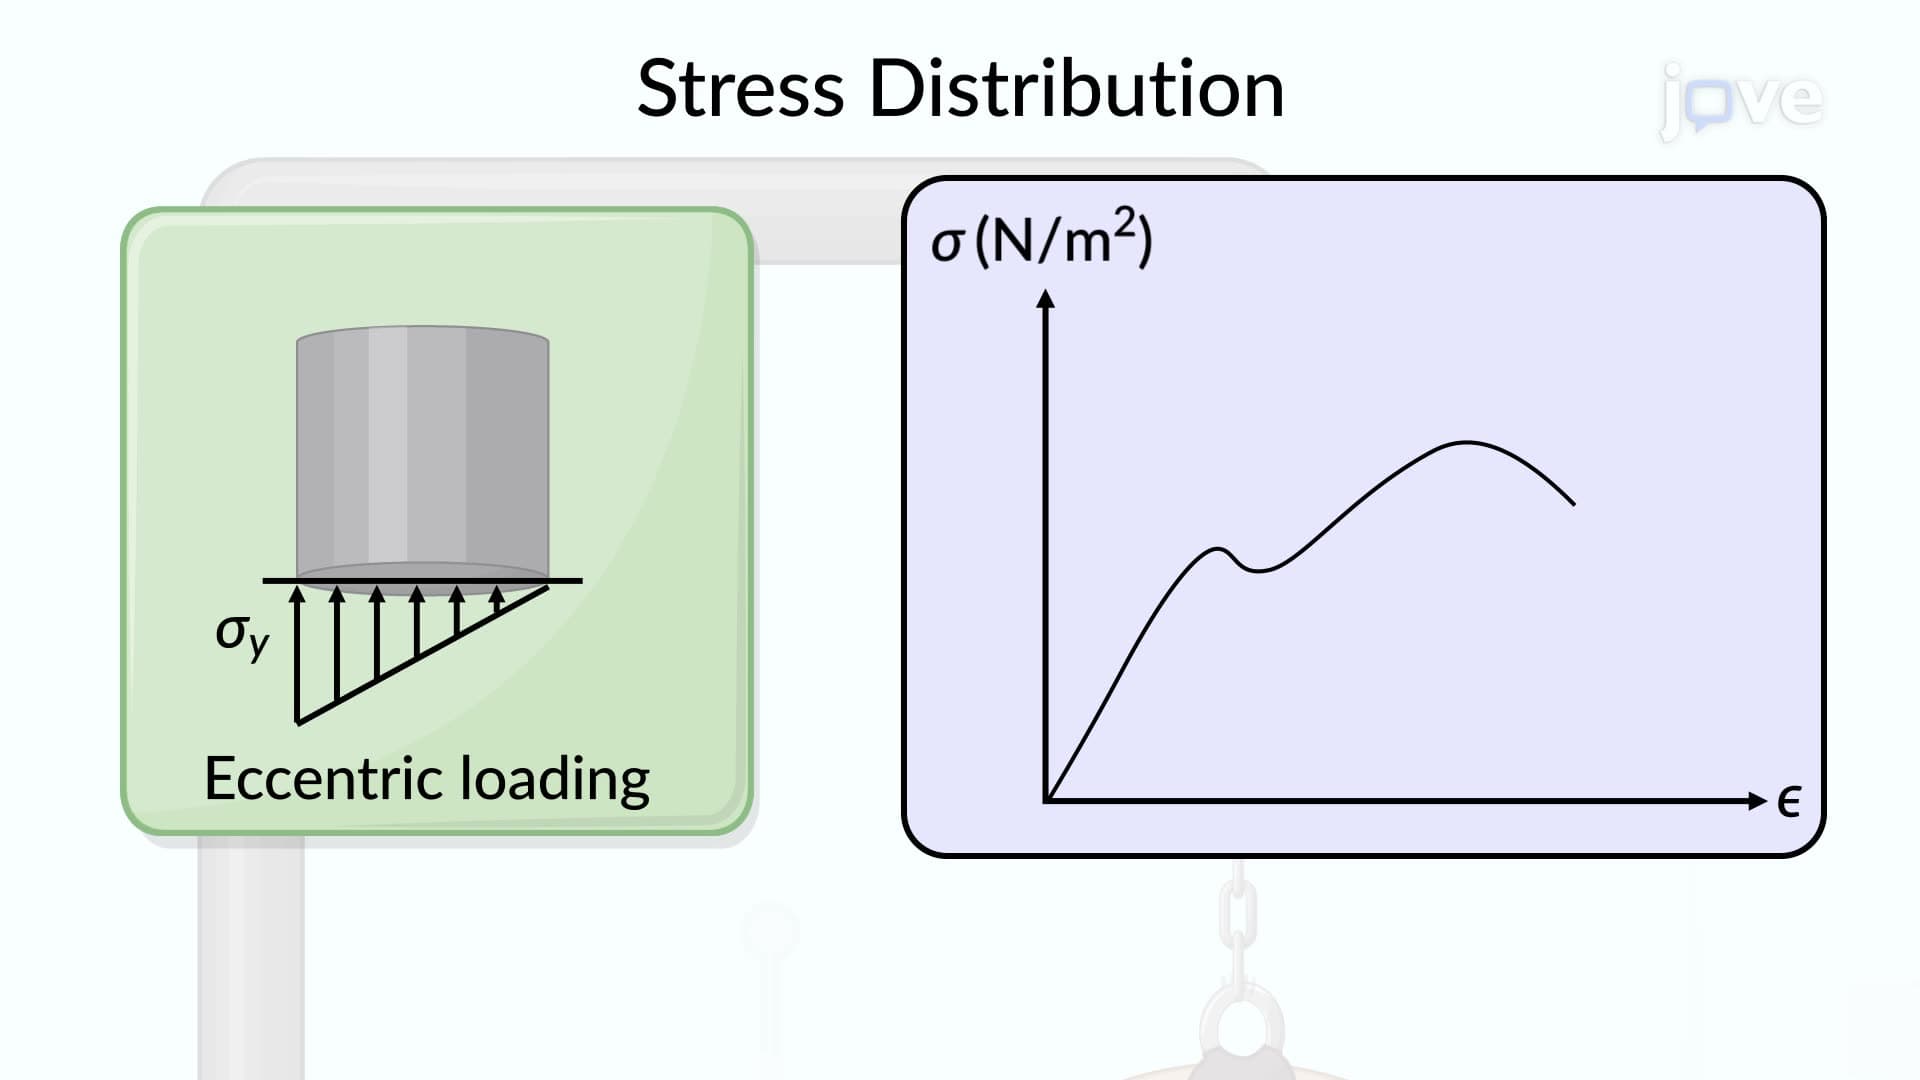
Eccentric Axial Loading in a Plane of Symmetry
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...