Robust Isometric Non-Rigid Structure-From-Motion
Related Experiment Video
Updated: Nov 2, 2025
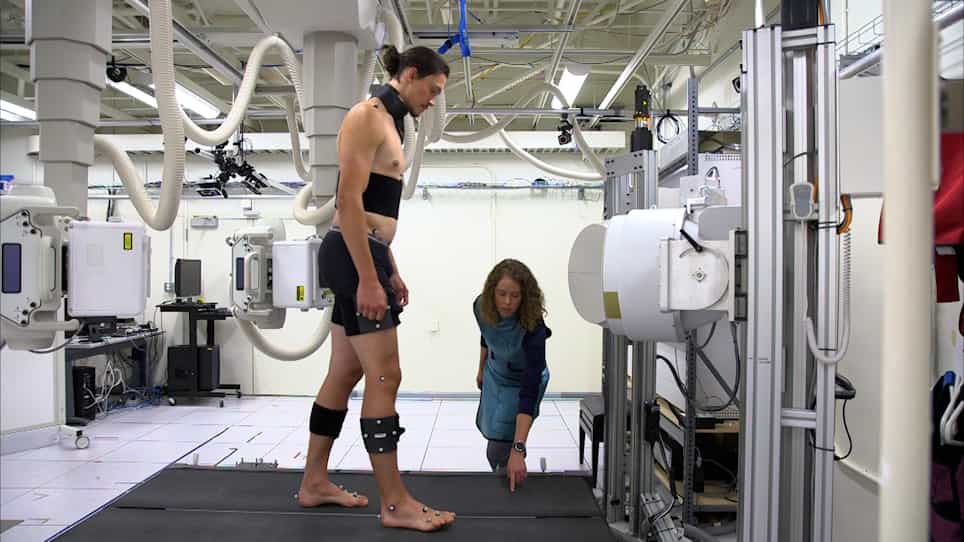
In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021

Abstract:
Non-Rigid Structure-from-Motion (NRSfM) reconstructs a deformable 3D object from keypoint correspondences established between monocular 2D images. Current NRSfM methods lack statistical robustness, which is the ability to cope with correspondence errors. This prevents one to use automatically established correspondences, which are prone to errors, thereby strongly limiting the scope of NRSfM. We propose a three-step automatic pipeline to solve NRSfM robustly by exploiting isometry. Step (i) computes the optical flow from correspondences, step (ii) reconstructs each 3D point's normal vector using multiple reference images and integrates them to form surfaces with the best reference and step (iii) rejects the 3D points that break isometry in their local neighborhood. Importantly, each step is designed to discard or flag erroneous correspondences. Our contributions include the robustification of optical flow by warp estimation, new fast analytic solutions to local normal reconstruction and their robustification, and a new scale-independent measure of 3D local isometric coherence. Experimental results show that our robust NRSfM method consistently outperforms existing methods on both synthetic and real datasets.
Related Concept Videos
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:20
Structural Classification of Joints
A fibrous joint is where the adjacent bones are united by fibrous connective...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...