Related Experiment Video
Updated: Oct 31, 2025

Microfluidic Platform with Multiplexed Electronic Detection for Spatial Tracking of Particles
Published on: March 13, 2017
An Optimized Vector Tracking Architecture for Pseudo-Random Pulsing CDMA Signals
Lin Tao1, Guangchen Li1, Junren Sun1
1School of Electronics Engineering and Computer Science, Peking University, Beijing 100871, China.

Abstract:
The vector tracking loop (VTL) has high tracking accuracy and a superior ability to track weak signals in GNSS. However, traditional VTL architecture is established on continuous Code Division Multiple Access (CDMA) signal and is incompatible with pseudolite positioning systems (PLPS) because PLPS generally adopts a pseudo-random pulsing CDMA signal structure to mitigate the near-far effect. Therefore, this paper proposes an optimized VTL architecture for pseudo-random pulsing CDMA signals. To avoid estimation biases in PLPS, the proposed VTL adopts irregular update periods (IUP) pre-filters which adjust the update cycles according to the active timeslot intervals. Meanwhile, as the active timeslots of different pseudolites do not overlap, the sampling time of the navigation filter inputs is inconsistent and time-varying, causing jitter degradation. Thus, the proposed VTL predicts the measurements so that they can be sampled at the same time, which improves tracking accuracy. Simulation is carried out to evaluate the performance of the proposed VTL. The results suggest that the proposed VTL outperforms the traditional pre-filter-based VTL and IUP pre-filter-based VTL.

Related Concept Videos
 01:11
Sampling Continuous Time Signal
In the...
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:16
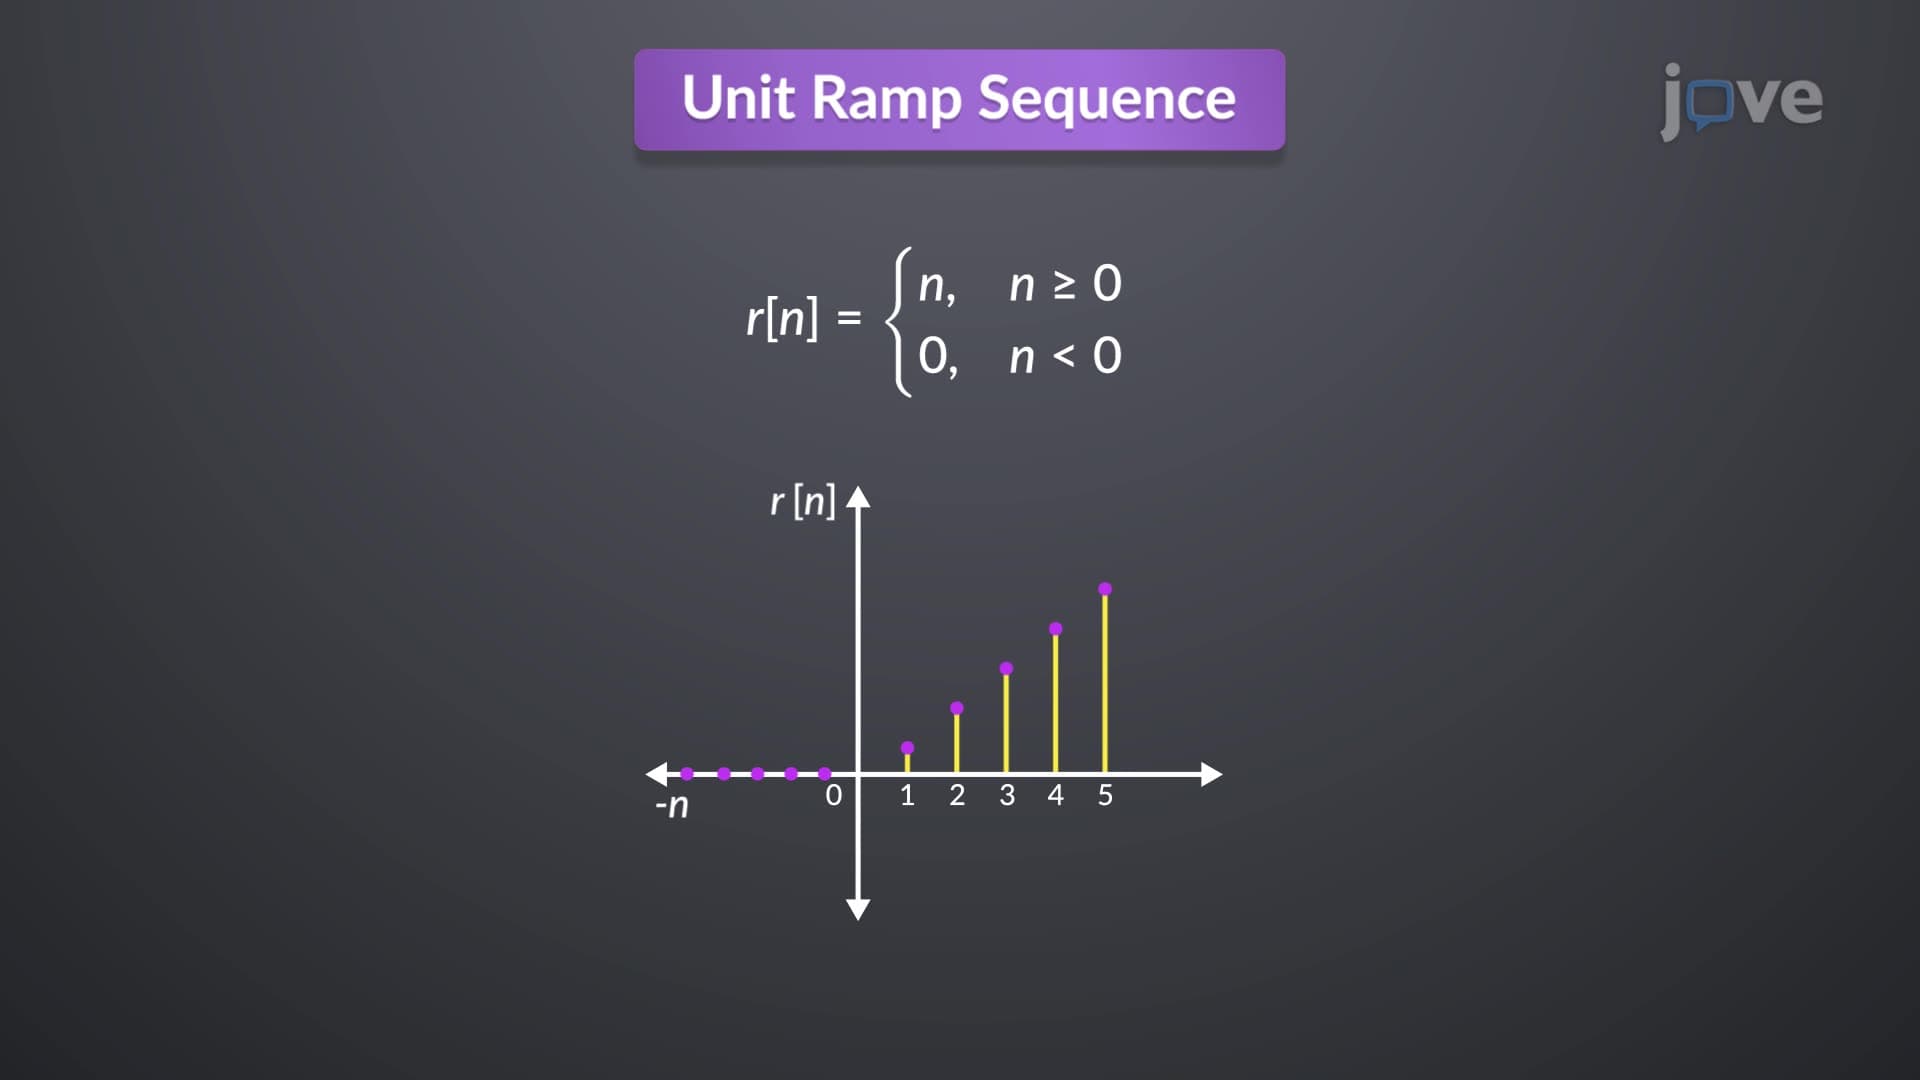
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is...
 01:10
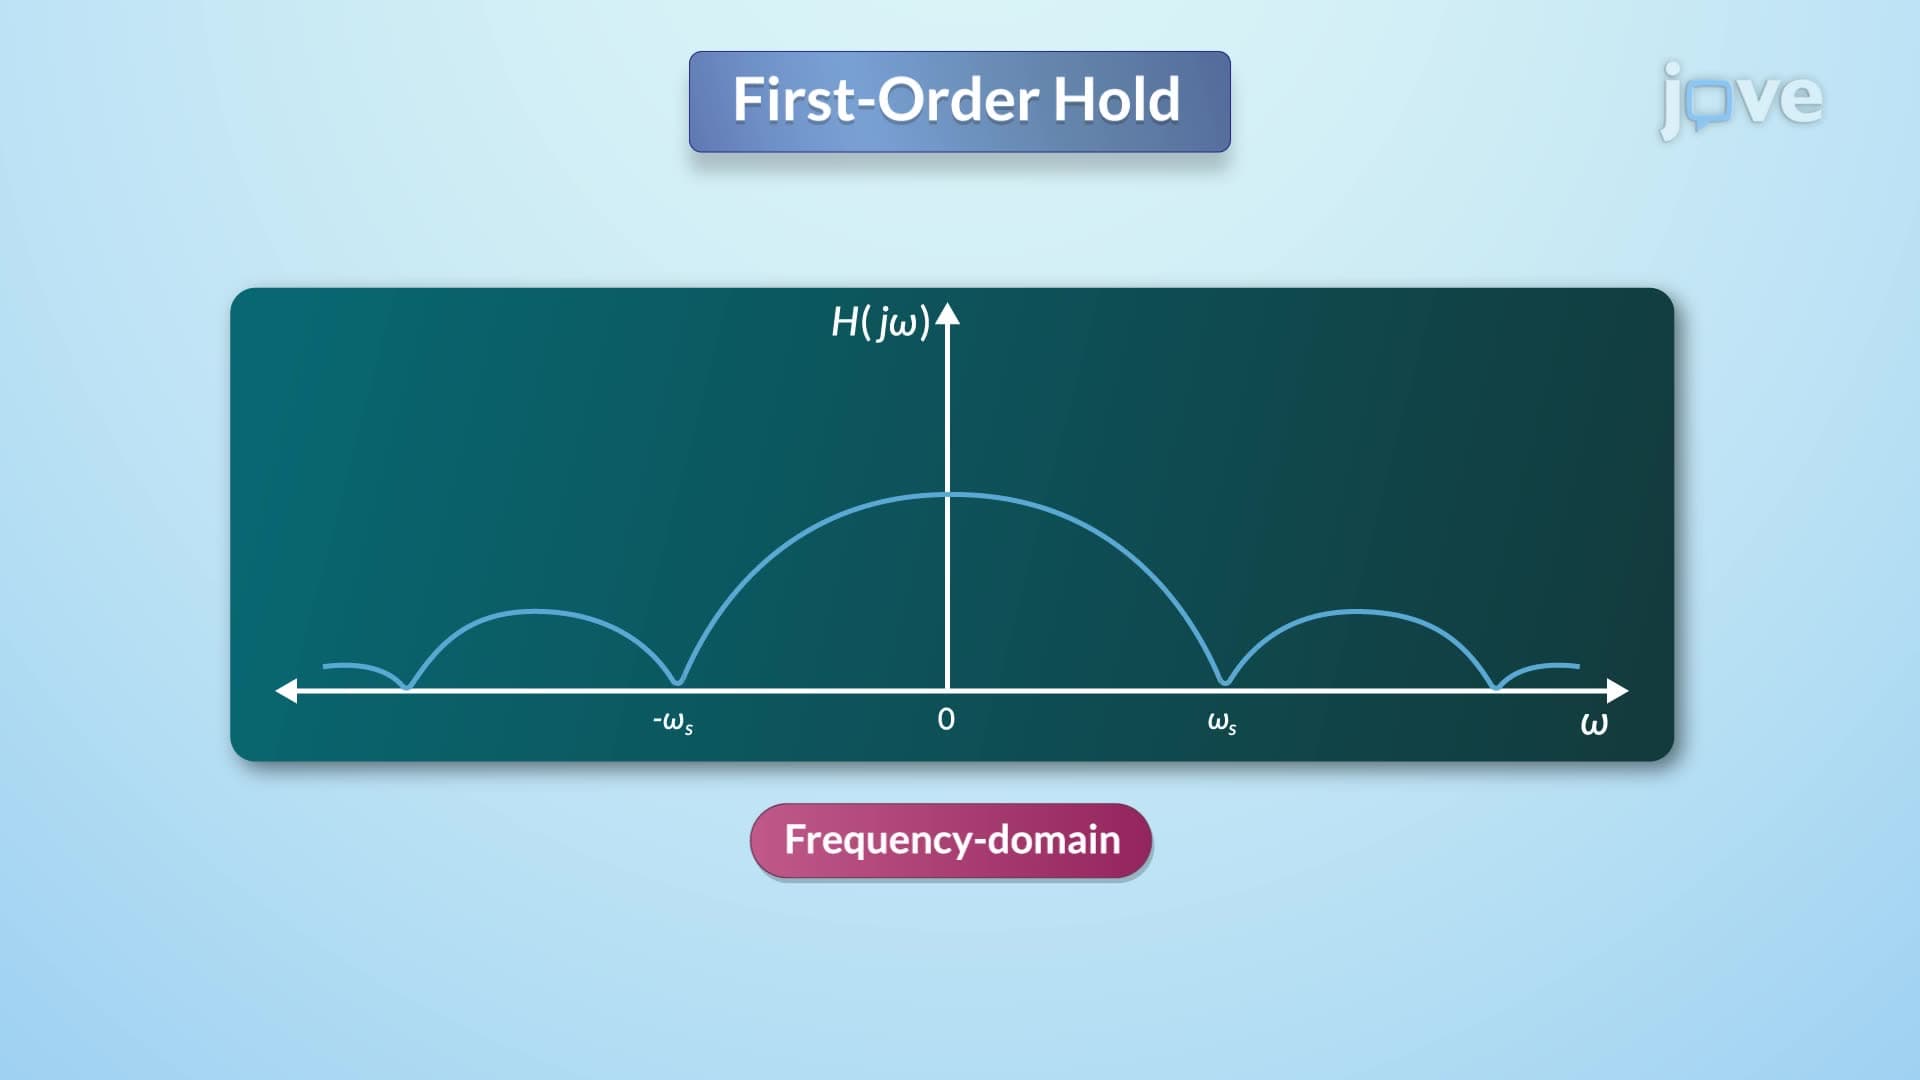
Reconstruction of Signal using Interpolation
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...