

Hysteresis Modeling and Compensation of Fast Steering Mirrors with Hysteresis Operator Based Back Propagation Neural
Kairui Cao1, Guanglu Hao1, Qingfeng Liu1
1School of Astronautics, Harbin Institute of Technology, Harbin 150001, China.

Abstract:
Fast steering mirrors (FSMs), driven by piezoelectric ceramics, are usually used as actuators for high-precision beam control. A FSM generally contains four ceramics that are distributed in a crisscross pattern. The cooperative movement of the two ceramics along one radial direction generates the deflection of the FSM in the same orientation. Unlike the hysteresis nonlinearity of a single piezoelectric ceramic, which is symmetric or asymmetric, the FSM exhibits complex hysteresis characteristics. In this paper, a systematic way of modeling the hysteresis nonlinearity of FSMs is proposed using a Madelung's rules based symmetric hysteresis operator with a cascaded neural network. The hysteresis operator provides a basic hysteresis motion for the FSM. The neural network modifies the basic hysteresis motion to accurately describe the hysteresis nonlinearity of FSMs. The wiping-out and congruency properties of the proposed method are also analyzed. Moreover, the inverse hysteresis model is constructed to reduce the hysteresis nonlinearity of FSMs. The effectiveness of the presented model is validated by experimental results.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:34
Woodward–Hoffmann Selection Rules and Microscopic Reversibility
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:23
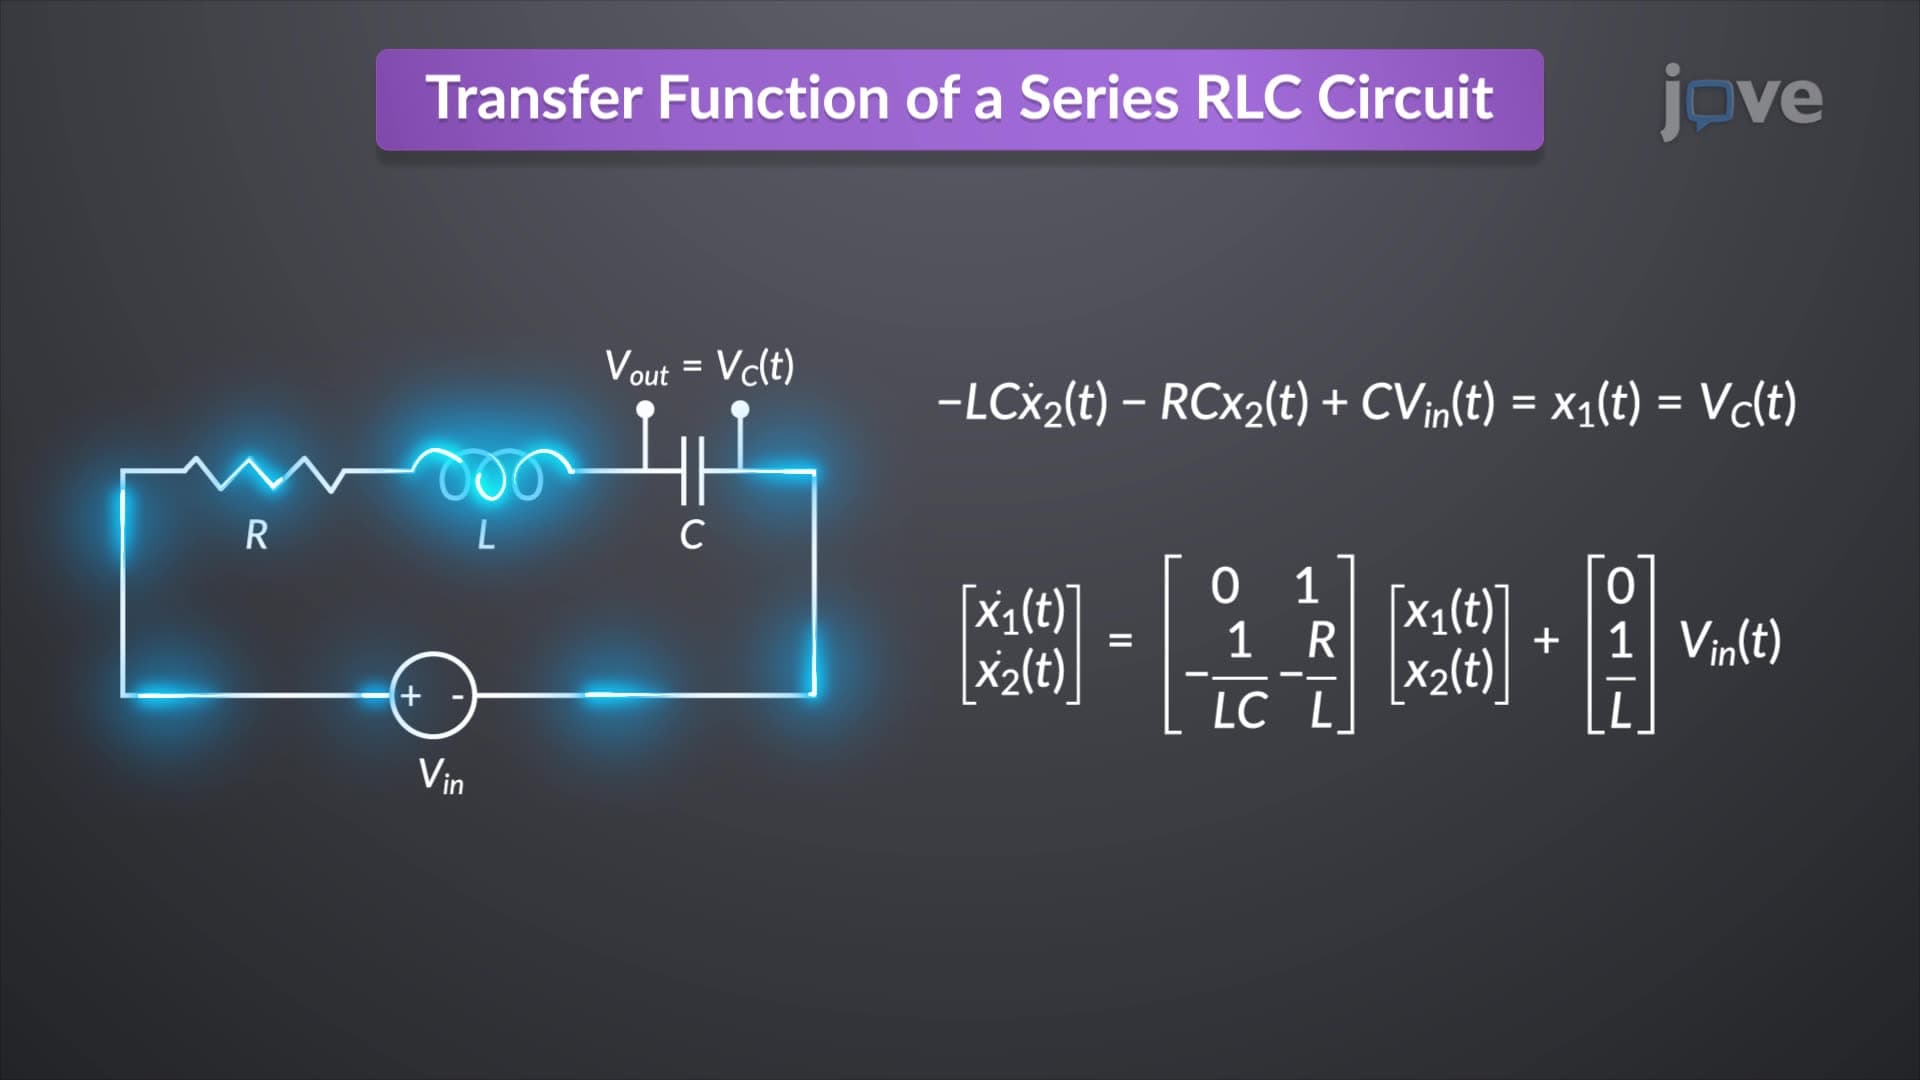
Transfer Function to State Space
In an...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...