Consensus control of multi-agent systems with P-one-sided Lipschitz
Related Experiment Video
Updated: Oct 30, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Jun Huang1, Ming Yang1, Yueyuan Zhang1
1School of Mechanical and Electrical Engineering, Soochow University, Suzhou 215131, China.

Abstract:
This paper investigates the consensus problem for a class of multi-agent systems with P-one-sided Lipschitz nonlinearity. This nonlinearity offers a significant extension to application range of existing consensus control protocol design methods, which removes the assumption of the quadratic inner-boundedness. To solve this problem, a strongly connected graph topology is applied within the consensus protocol design framework. Moreover, the leader-following scenario is addressed under the graph topology. Under the above objectives, sufficient conditions are employed to yield consensus. Two examples are performed to illustrate the properties.


Related Concept Videos
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:14
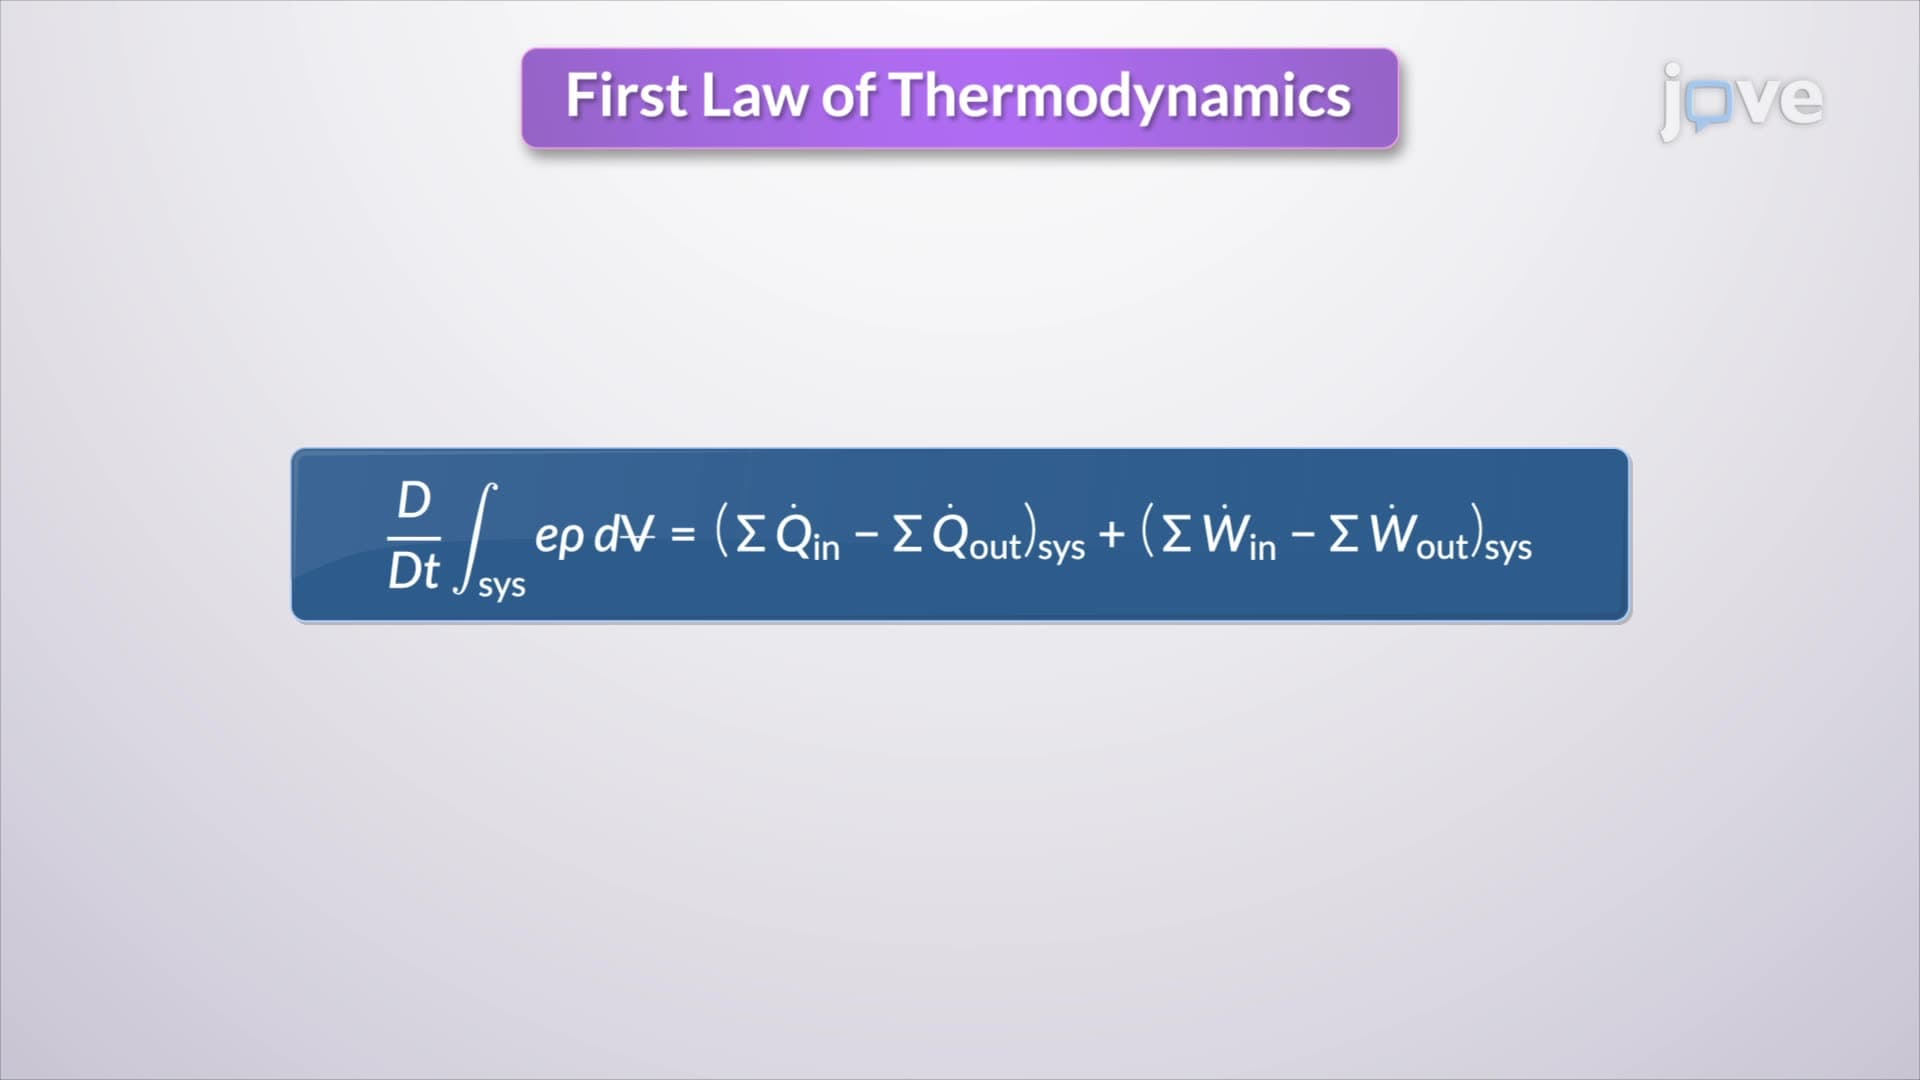
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:31
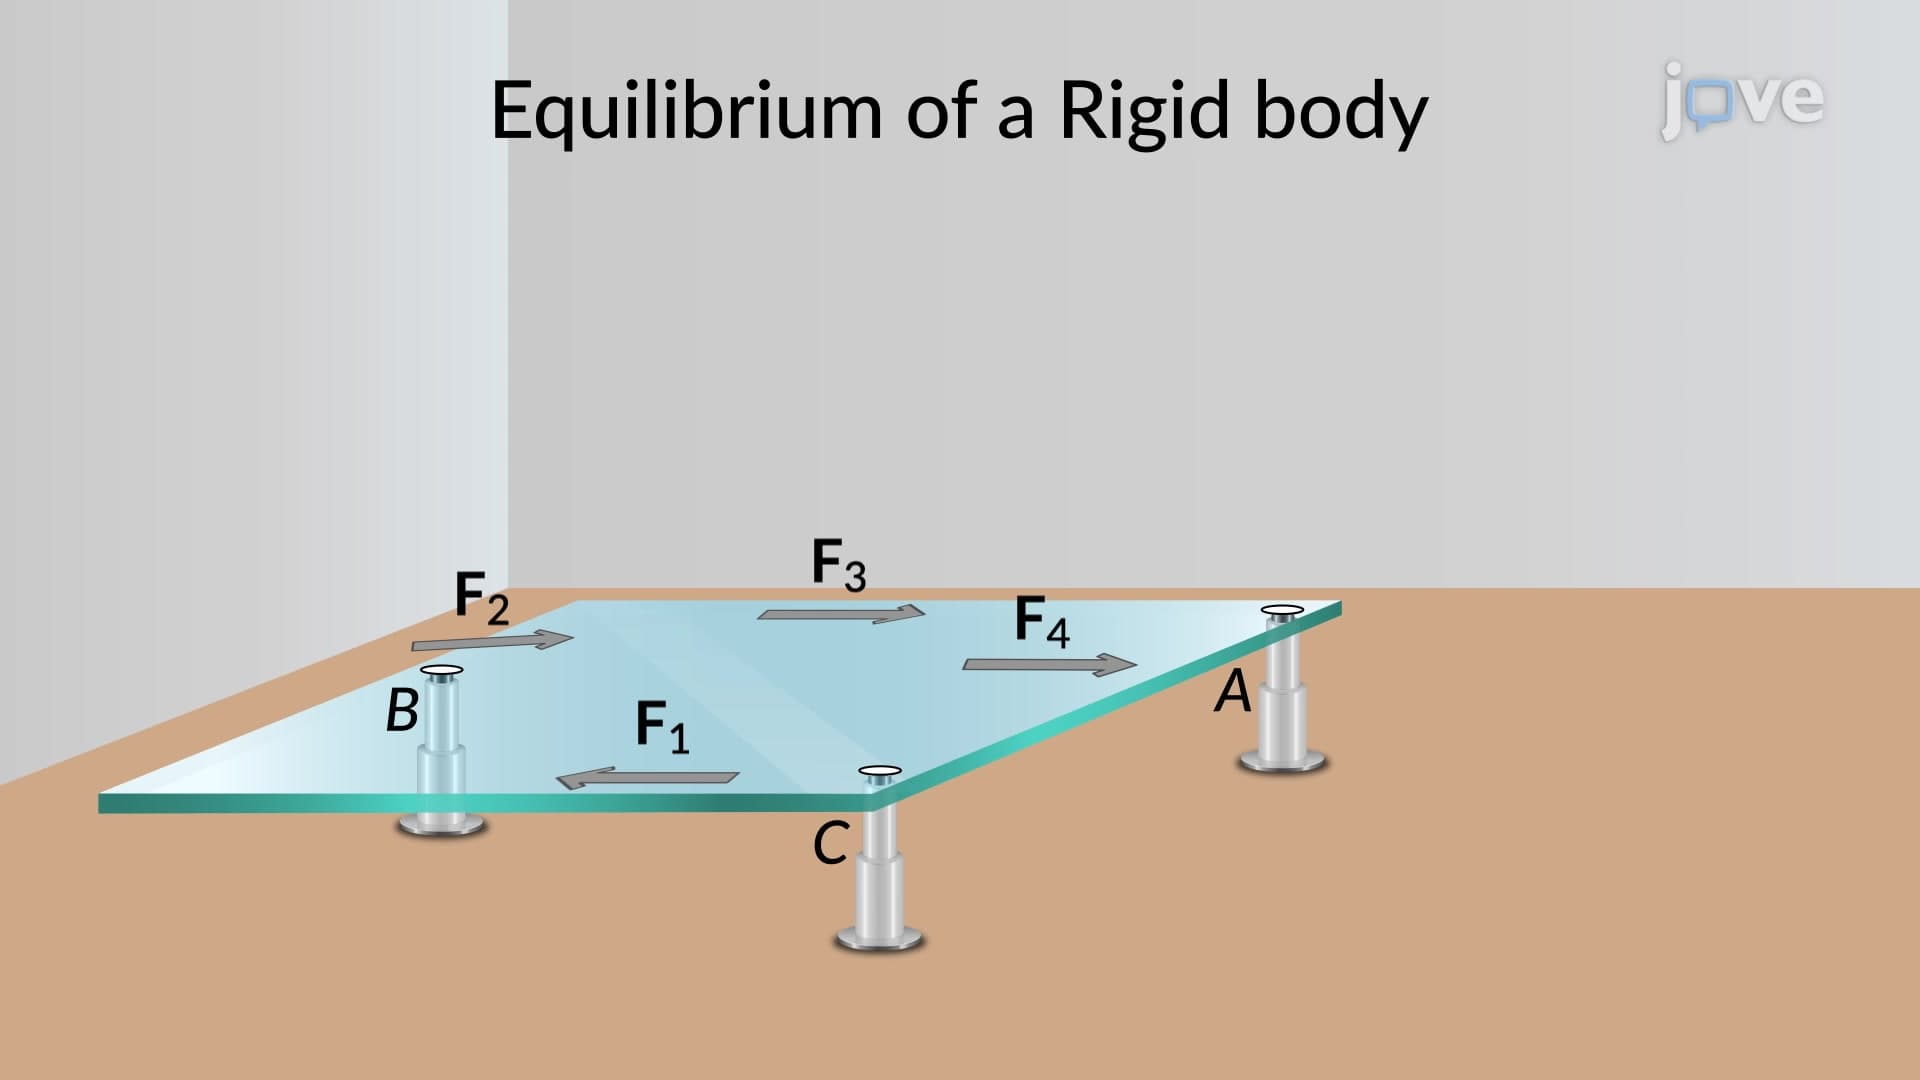
Alternative Sets of Equilibrium Equations
One example of such a situation can be observed in a...
 01:59
Solution Equilibrium and Saturation
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....