Related Experiment Video
Updated: Oct 30, 2025


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Characterizing the Validity of the Inverted Pendulum Model for Quiet Standing
Jia-Li Sung1, Chih-Yuan Hong1, Chin-Hsuan Liu2
1Department of Mechanical and Electro-Mechanical Engineering, National Sun Yat-Sen University, Kaohsiung 80424, Taiwan.

Abstract:
By assuming that the human body rotates primarily around the ankle joint in the sagittal plane, the human body has been modelled as a single inverted pendulum (IP) to simulate the human quiet stance. Despite its popularity, the validity of the IP model has been challenged in many studies. Rather than testing the validity of the IP model as a true or false question, this work proposes a feature to quantify the degree of validity of the IP model. The development of the proposed feature is based on the fact that the IP model predicts that the horizontal acceleration of COM is proportional to the COP error which is defined as the difference between the center of pressure (COP) and the vertical projection of the center of mass (COM). Since the horizontal components of the acceleration of COM and the ground reaction force (GRF) are always proportional, the proposed feature is the correlation coefficient between the anterior-posterior (AP) components of GRF and the COP error. The efficacy of the proposed feature is demonstrated by comparing its differences for individuals in two age groups (18-24 and 65-73 years) in quiet standing. The experimental results show that the IP model is more suited for predicting the motion of the older group than the younger group. Our results also show that the proposed feature is more sensitive to aging effects than one of the most reliable and accurate COP-based postural stability features.
Related Concept Videos
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum...
 01:09
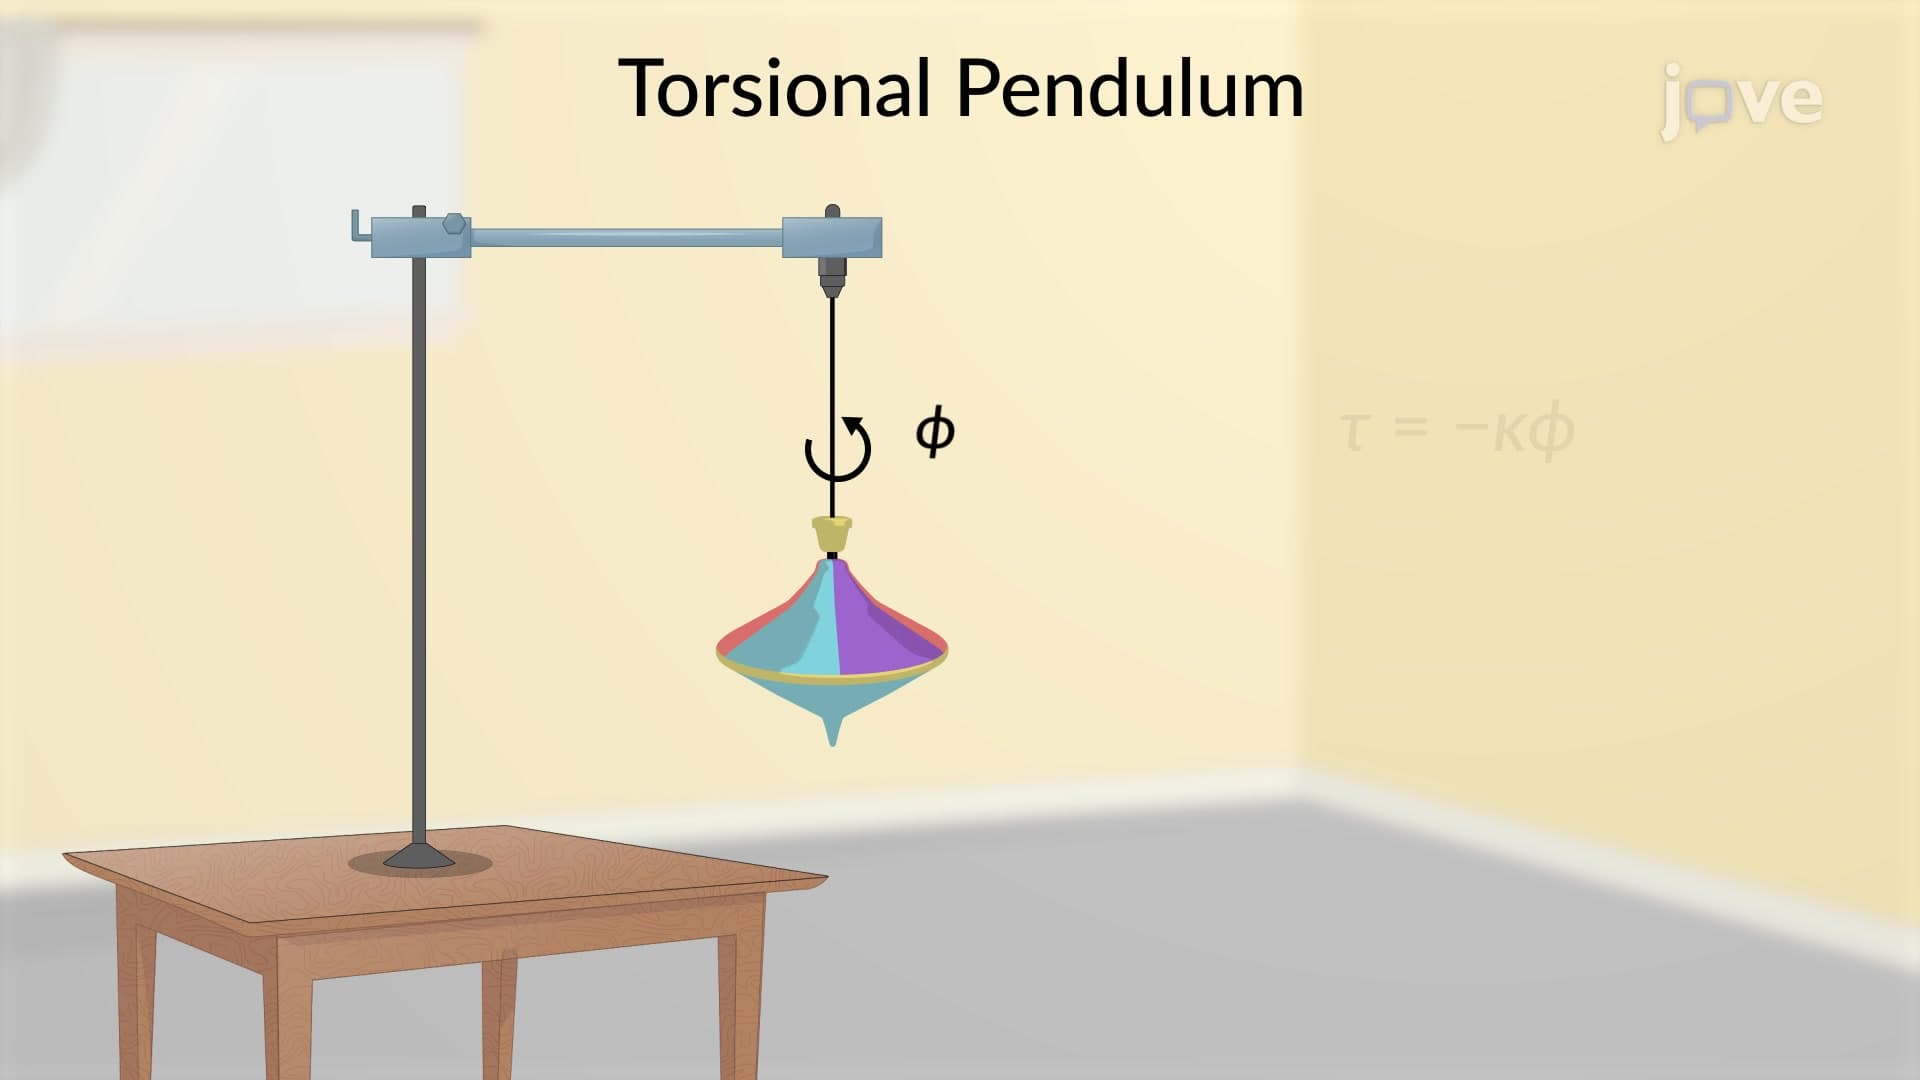
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:17
Standing Waves
 01:04
Oscillations about an Equilibrium Position