Related Experiment Video
Updated: Oct 30, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Event-Triggered Approximate Optimal Path-Following Control for Unmanned Surface Vehicles With State Constraints

Abstract:
This article investigates the problem of path following for the underactuated unmanned surface vehicles (USVs) subject to state constraints. A useful control algorithm is proposed by combining the backstepping technique, adaptive dynamic programming (ADP), and the event-triggered mechanism. The presented approach consists of three modules: guidance law, dynamic controller, and event triggering. First, to deal with the "singularity" problem, the guidance-based path-following (GBPF) principle is introduced in the guidance law loop. In contrast to the traditional barrier Lyapunov function (BLF) method, this article converts the USV's constraint model to a class of nonlinear systems without state constraints by introducing a nonlinear mapping. The control signal generated by the dynamic controller module consists of a backstepping-based feedforward control signal and an ADP-based approximate optimal feedback control signal. Therefore, the presented scheme can guarantee the approximate optimal performance. To approximate the cost function and its partial derivative, a critic neural network (NN) is constructed. By considering the event-triggered condition, the dynamic controller is further improved. Compared with traditional time-triggered control methods, the proposed approach can greatly reduce communication and computational burdens. This article proves that the closed-loop system is stable, and the simulation results and experimental validation are given to illustrate the effectiveness of the proposed approach.

Related Concept Videos
 01:19
Root-Locus Method
This system can be represented by a block...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:16
Statically Indeterminate Problem Solving
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:21
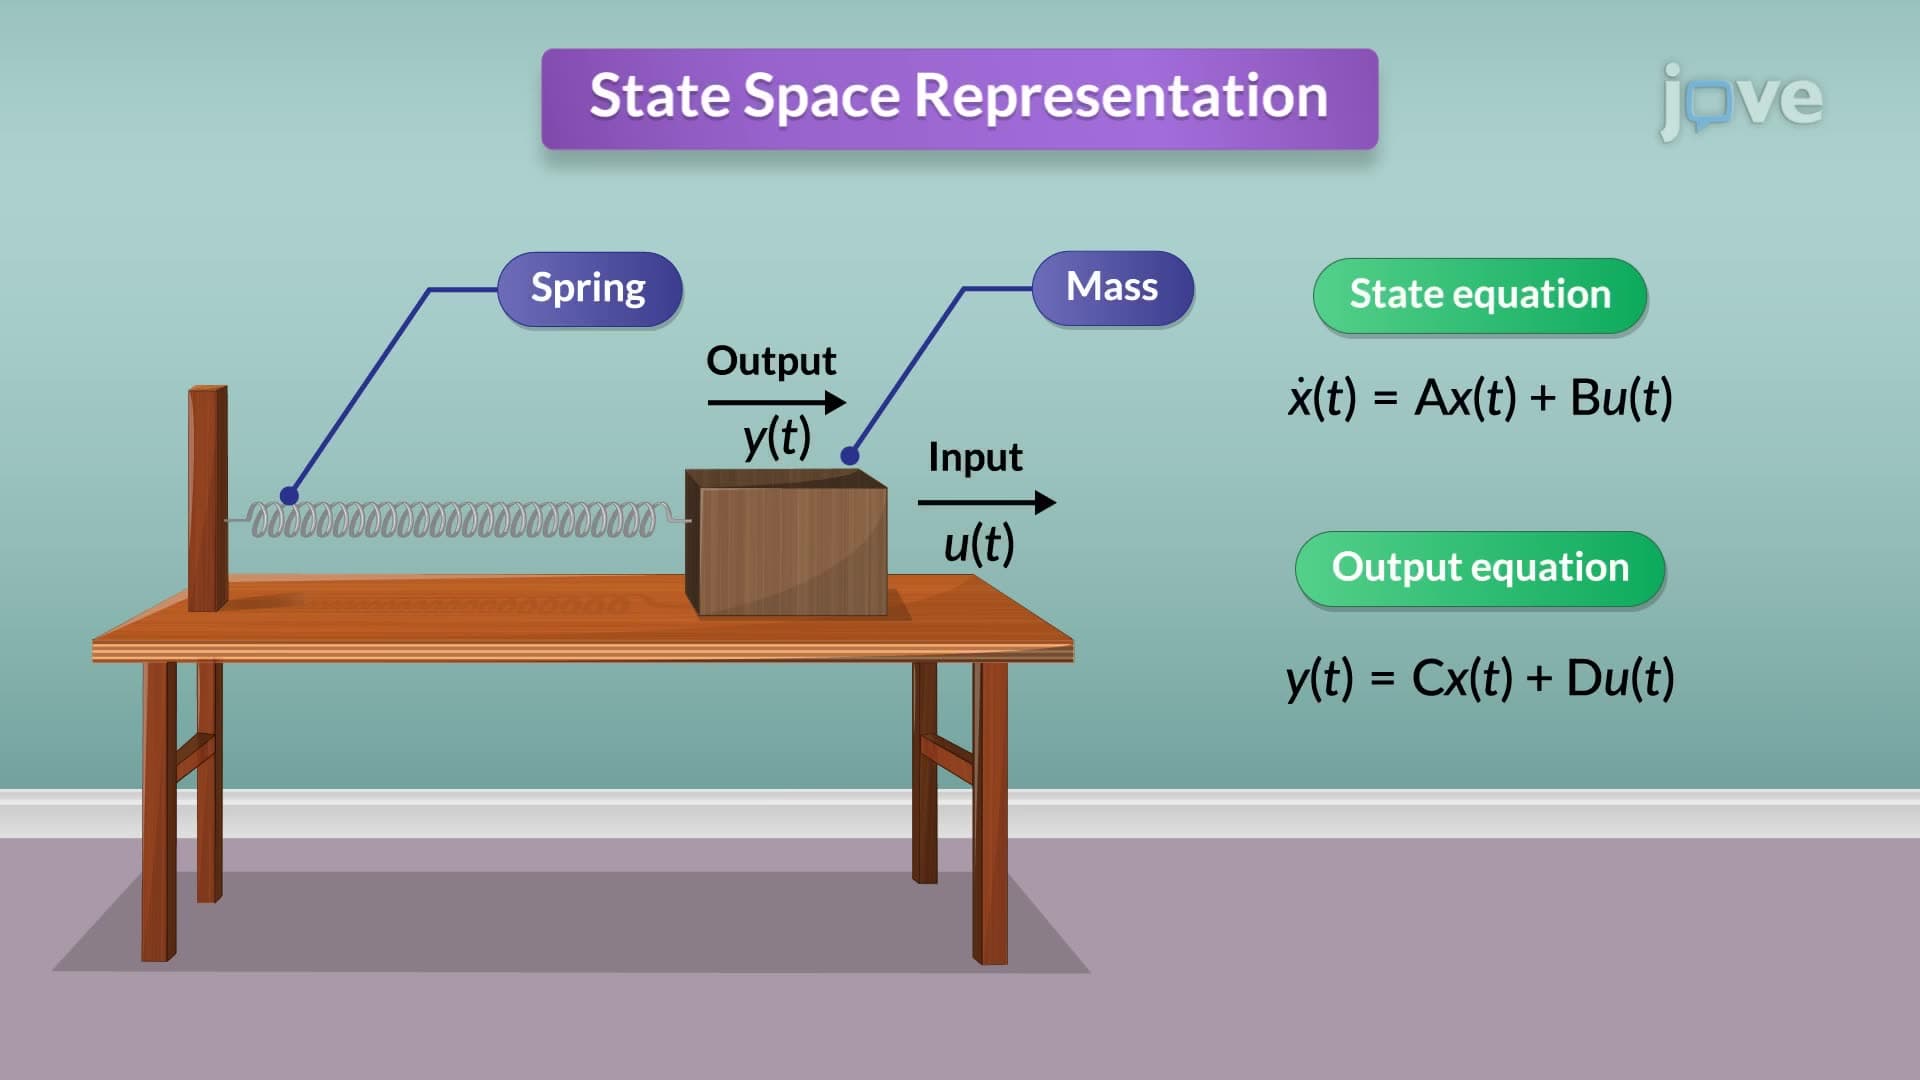
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...