Related Experiment Video
Updated: Oct 27, 2025


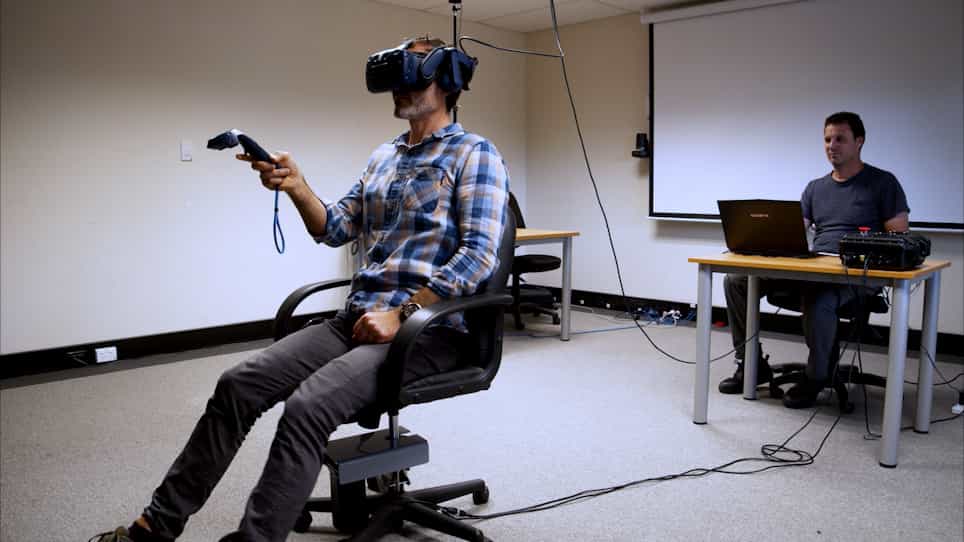
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Virtual Sensoring of Motion Using Pontryagin's Treatment of Hamiltonian Systems
1Sibley School of Mechanical and Aerospace Engineering, Cornell University, Ithaca, NY 14850, USA.

Abstract:
To aid the development of future unmanned naval vessels, this manuscript investigates algorithm options for combining physical (noisy) sensors and computational models to provide additional information about system states, inputs, and parameters emphasizing deterministic options rather than stochastic ones. The computational model is formulated using Pontryagin's treatment of Hamiltonian systems resulting in optimal and near-optimal results dependent upon the algorithm option chosen. Feedback is proposed to re-initialize the initial values of a reformulated two-point boundary value problem rather than using state feedback to form errors that are corrected by tuned estimators. Four algorithm options are proposed with two optional branches, and all of these are compared to three manifestations of classical estimation methods including linear-quadratic optimal. Over ten-thousand simulations were run to evaluate each proposed method's vulnerability to variations in plant parameters amidst typically noisy state and rate sensors. The proposed methods achieved 69-72% improved state estimation, 29-33% improved rate improvement, while simultaneously achieving mathematically minimal costs of utilization in guidance, navigation, and control decision criteria. The next stage of research is indicated throughout the manuscript: investigation of the proposed methods' efficacy amidst unknown wave disturbances.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:15
Kinematic Equations: Problem Solving