Bone collision detection method for robot assisted fracture reduction based on force curve slope
Related Experiment Video
Updated: Oct 25, 2025
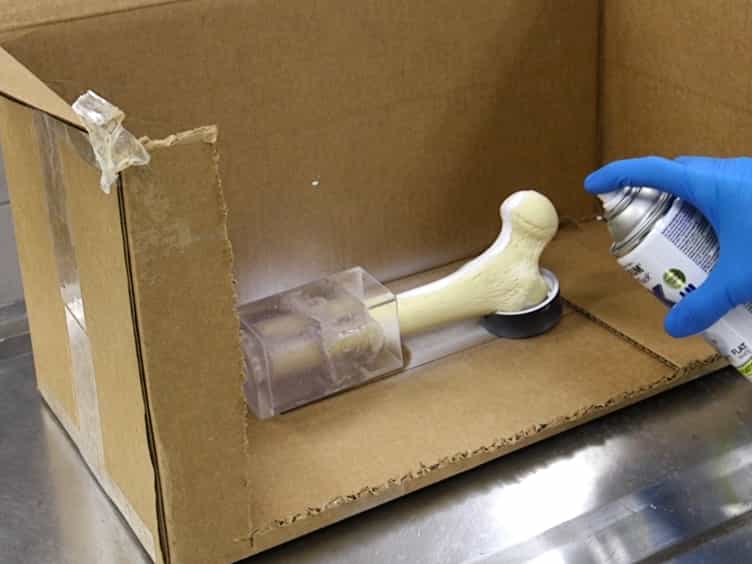
A Method to Estimate Cadaveric Femur Cortical Strains During Fracture Testing Using Digital Image Correlation
Published on: September 14, 2017
Chenxu Cai1, Congyu Sun1, Yixuan Song1
1Key Laboratory of High Efficiency and Clean Mechanical Manufacture (Ministry of Education), School of Mechanical Engineering, Shandong University, Jinan 250061, China; National Demonstration Center for Experimental Mechanical Engineering Education, Shandong University, Jinan 250061, China.

Background And Objective:
The application of robot technology in fracture reduction ensures the minimal invasiveness and accurate operation process. Most of the existing robot assisted fracture reduction systems don't have the function of bone collision detection, which is very important for system safety. In view of the deficiencies in the research of this field, a broken bone collision detection method based on the slope ratio of force curve was proposed in this paper, which could realize the real-time detection.
Methods:
In order to analyze the factors influencing the slope of force curve, a collision mechanical model based on three-element viscoelastic model was established. The effects of four factors on the slope ratio of the force curve were studied based on the mechanical model. The proposed collision detection model was analyzed in detail. By drawing slope ratio curves under various experimental conditions, the universality of the collision detection model was proved; by comparative simulation, the differences between the slope ratio curves before and after optimization were analyzed. The factors that affect the performance of the detection model were also analyzed.
Results:
The results of collision experiments show that the increase of moving speed of distal bone and soft tissue mass reduces the slope ratio, while the increase of collision angle increases the slope ratio. In the verification experiment, the minimum main peak of KRopt curve is 14.16 and the maximum is 220.7, the maximum interference value before the peak is 6.1. When the detection threshold is 10, the model can detect the collision state of the broken bone. It is also proved that after optimization, the model can effectively filter out invalid waveforms and reduce the occurrence of false detections. When a=5 and b=40, the detection model has sufficient stability and a low detection time delay.
Conclusion:
This research developed a broken bone collision detection method based on the slope ratio of the force curve. After optimization, the method has good adaptability under a variety of experimental conditions. The collision of broken bones can be judged by setting an appropriate detection threshold. The application of this method in the robot fracture reduction system will improve the safety of the system.
Related Concept Videos
 01:27
Fractures: Bone Repair
Minor fractures with no bone displacement are treated by immobilizing the fractured bone using a cast or splint. However, in the case of fractures with displaced bones, the broken bones are repositioned before immobilization to ensure successful healing without deformation and loss of function. The realignment of fractured bone ends is performed through a process called reduction. If the...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
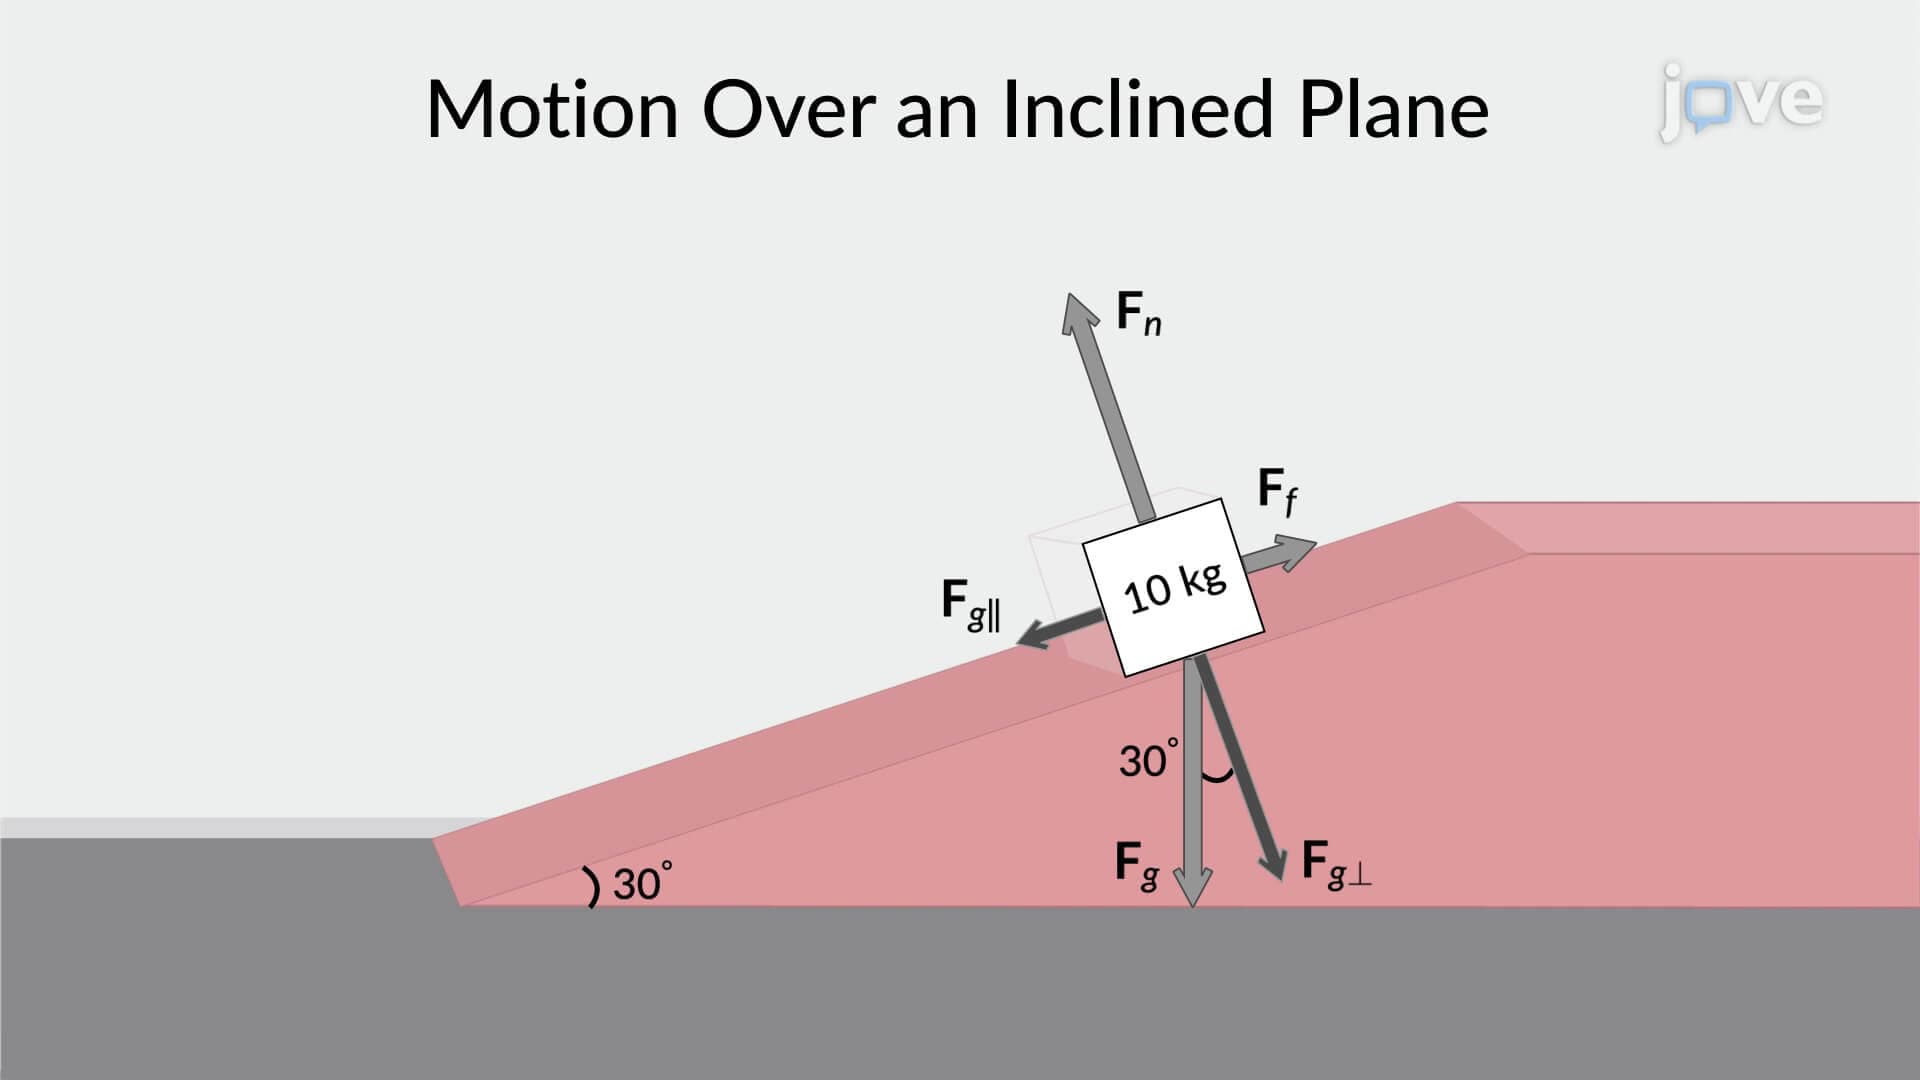
Free-body Diagrams: Problem Solving
For example, consider a block with a mass of 10 kg released on an inclined plane at an angle of 30° to the horizontal, where...