Related Experiment Video
Updated: Oct 25, 2025

Automatic Laser-based Geometry Capture for Finite Element Analysis of Weld Beads
Published on: July 25, 2025
Sensor-Enabled Multi-Robot System for Automated Welding and In-Process Ultrasonic NDE
Momchil Vasilev1, Charles N MacLeod1, Charalampos Loukas1
1Centre for Ultrasonic Engineering (CUE), Department of Electronic & Electrical Engineering, University of Strathclyde, Glasgow G1 1XQ, UK.

Abstract:
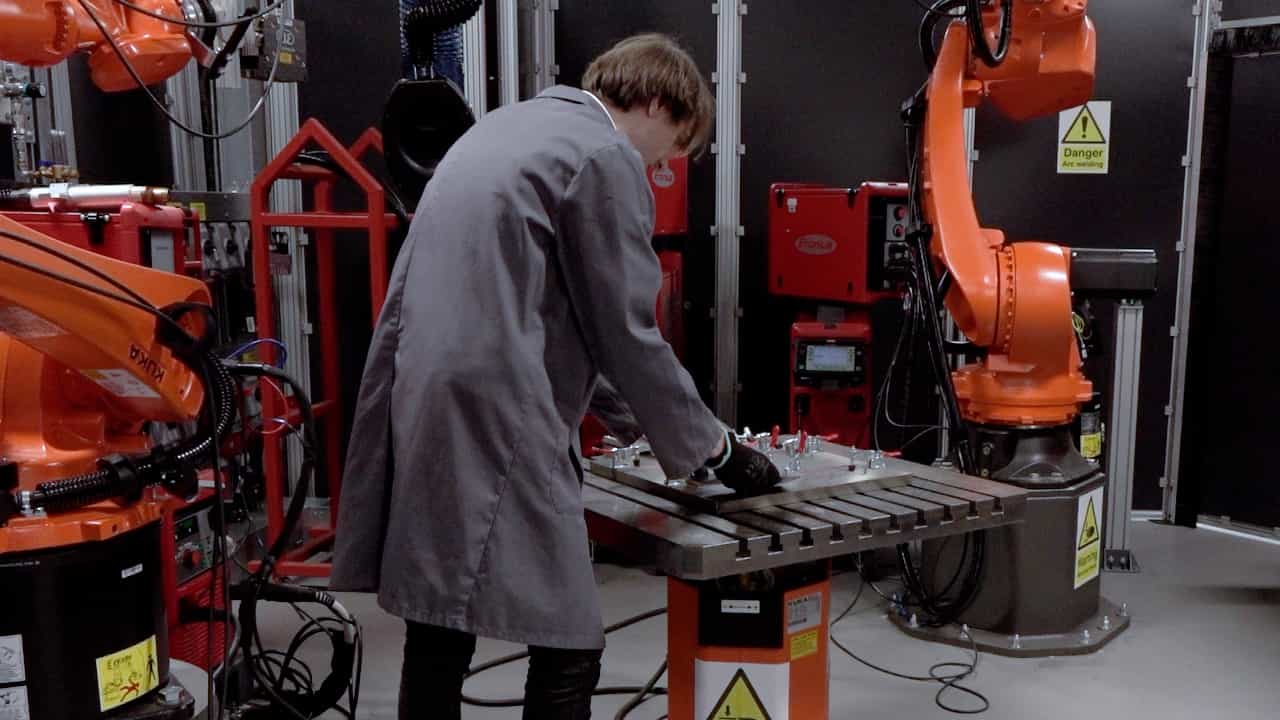
The growth of the automated welding sector and emerging technological requirements of Industry 4.0 have driven demand and research into intelligent sensor-enabled robotic systems. The higher production rates of automated welding have increased the need for fast, robotically deployed Non-Destructive Evaluation (NDE), replacing current time-consuming manually deployed inspection. This paper presents the development and deployment of a novel multi-robot system for automated welding and in-process NDE. Full external positional control is achieved in real time allowing for on-the-fly motion correction, based on multi-sensory input. The inspection capabilities of the system are demonstrated at three different stages of the manufacturing process: after all welding passes are complete; between individual welding passes; and during live-arc welding deposition. The specific advantages and challenges of each approach are outlined, and the defect detection capability is demonstrated through inspection of artificially induced defects. The developed system offers an early defect detection opportunity compared to current inspection methods, drastically reducing the delay between defect formation and discovery. This approach would enable in-process weld repair, leading to higher production efficiency, reduced rework rates and lower production costs.


