

Finite-time stabilization and H∞ control of Port-controlled Hamiltonian systems with disturbances and saturation
Baozeng Fu1,2, Qingzhi Wang1,2, Ping Li3
1Institute of Complexity Science, School of Automation, Qingdao University, Qingdao, Shandong Province, China.

Abstract:
The finite-time stabilization and finite-time H∞ control problems of Port-controlled Hamiltonian (PCH) systems with disturbances and input saturation (IS) are studied in this paper. First, by designing an appropriate output feedback, a strictly dissipative PCH system is obtained and finite-time stabilization result for nominal system is given. Second, with the help of the Hamilton function method and truncation inequality technique, a novel output feedback controller is developed to make the PCH system finite-time stable when IS occurs. Further, a finite-time H∞ controller is designed to attenuate disturbances for PCH systems with IS, and sufficient conditions are presented. Finally, a numerical example and a circuit example are given to reveal the feasibility of the obtained theoretical results.


Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:28
Stability
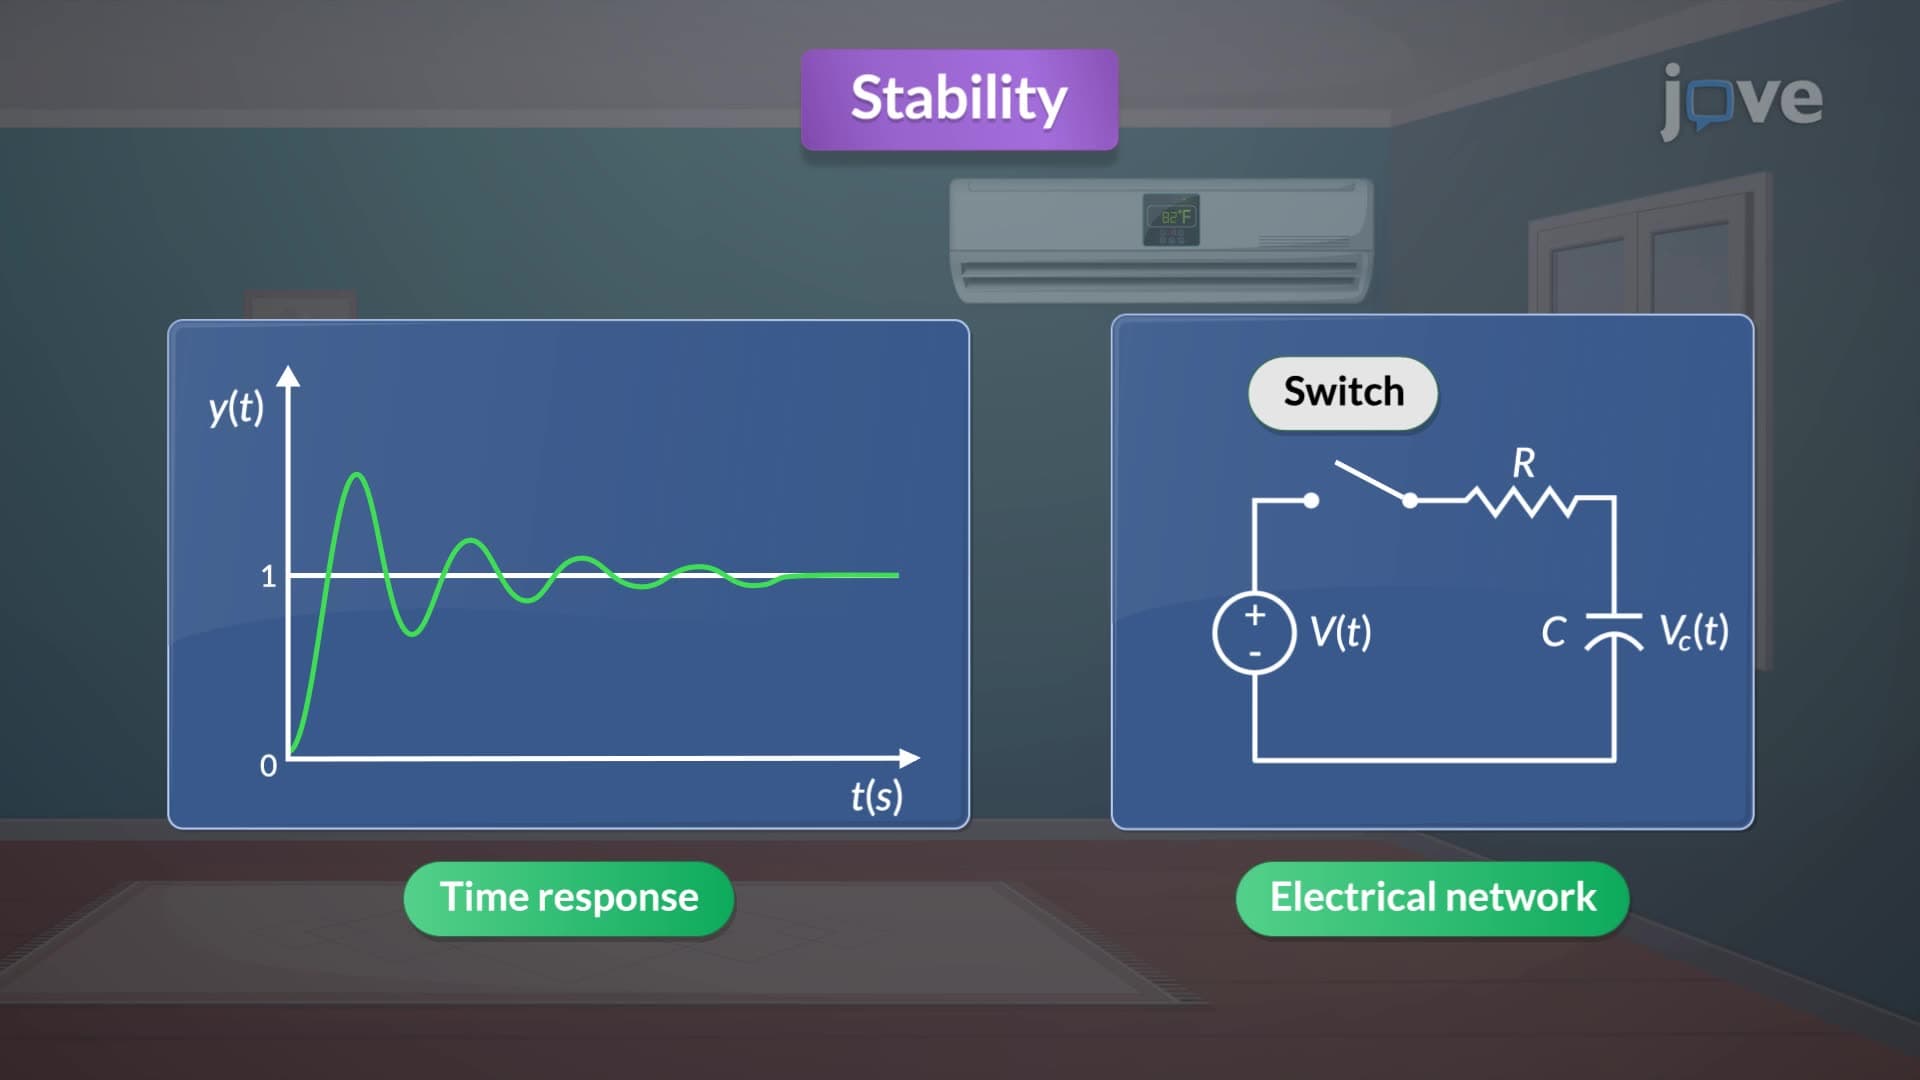
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....