Related Experiment Video
Updated: Sep 2, 2025

08:18

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
5.0K
Correction: Finite-time stabilization and H∞ control of Port-controlled Hamiltonian systems with disturbances and
Plos One
|August 4, 2022

Abstract:
[This corrects the article DOI: 10.1371/journal.pone.0255797.].


Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
174
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
174
 01:28
Stability
185
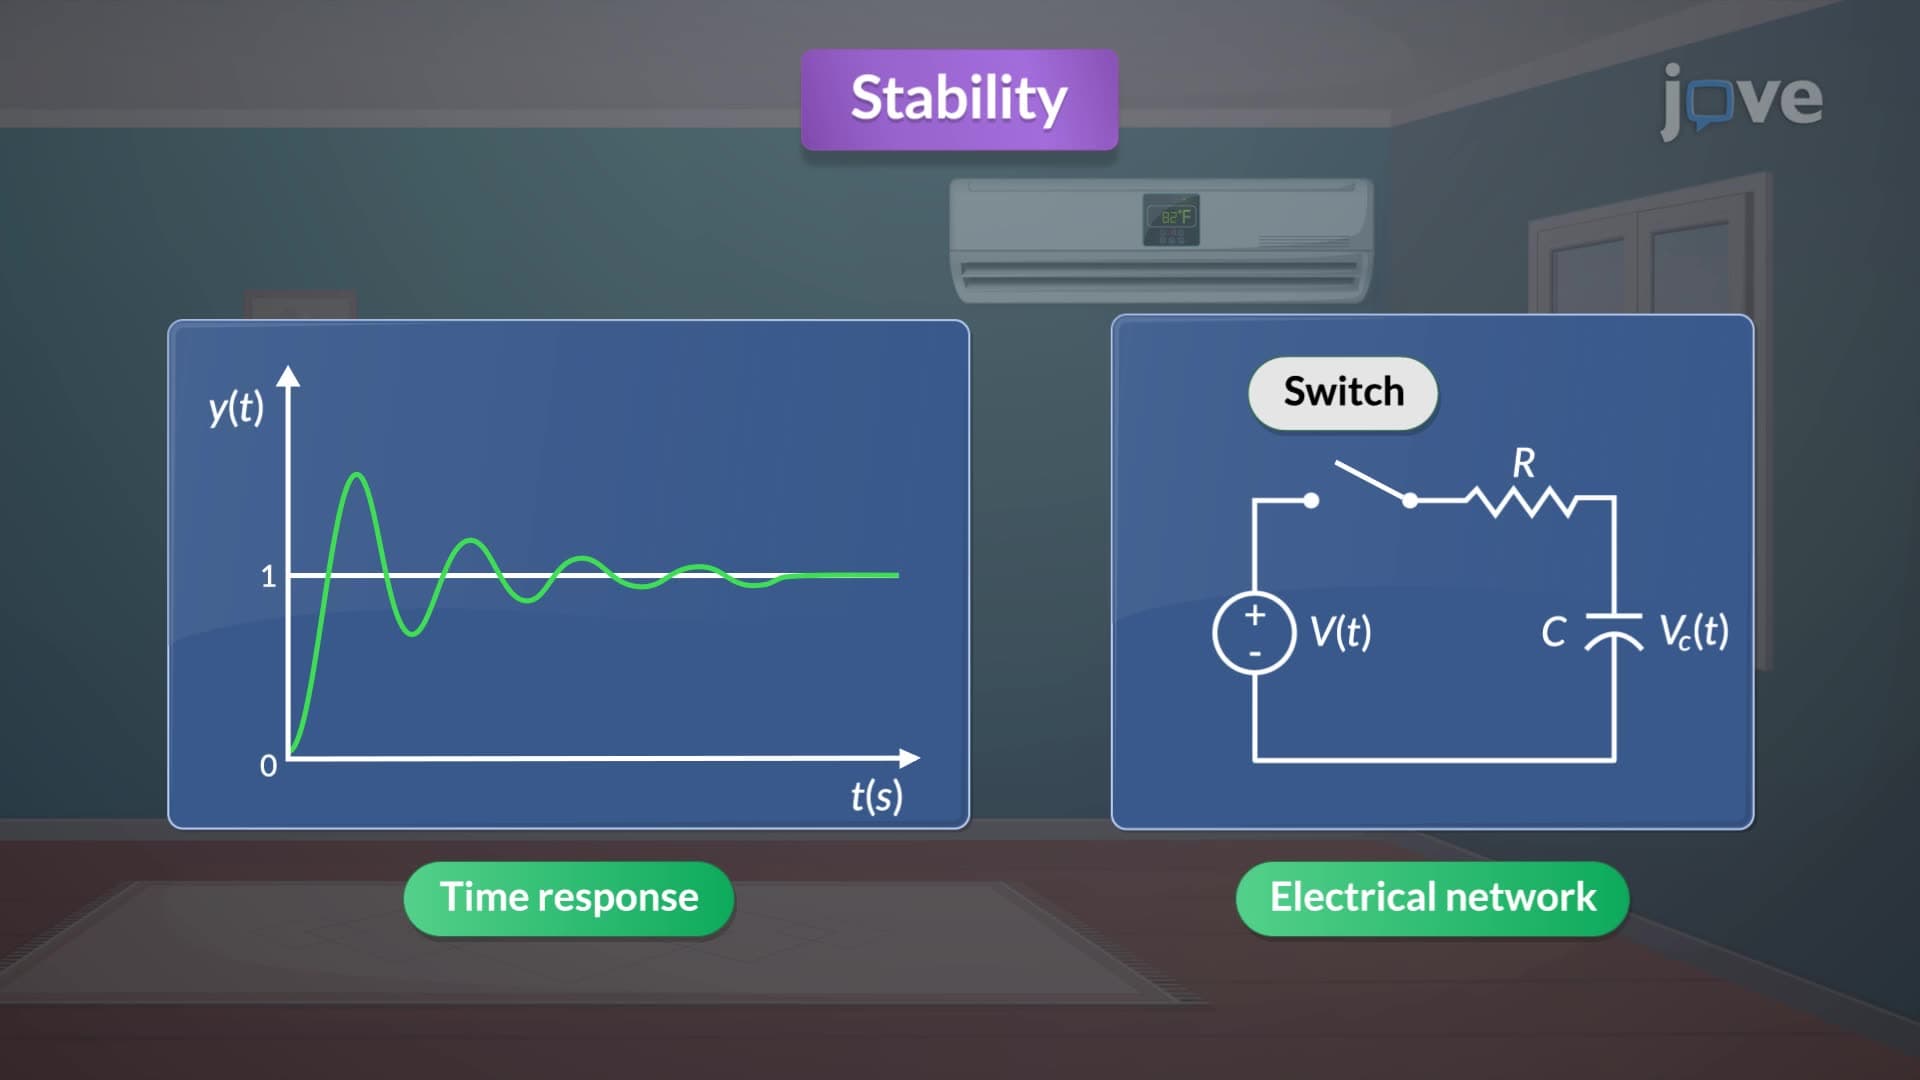
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
185
 01:24
Pole and System Stability
407
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
407
 01:21
Control System Problem
171
In an open-loop system, such as a basic thermostat, the poles of the transfer function influence the system's response but do not determine its stability. However, when feedback is introduced to form a closed-loop system, such as an advanced thermostat that adjusts heating based on room temperature, stability is governed by the new poles of the closed-loop transfer function.
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
171
 01:27
Time and frequency -Domain Interpretation of PI Control
195
Proportional-Integral (PI) controllers are essential in many control systems to improve stability and performance. They are commonly used in everyday devices like thermostats to enhance system damping and reduce steady-state error. When the zero in the controller's transfer function is optimally placed, the system benefits significantly in terms of stability and accuracy.
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
195
 01:21
Linear Approximation in Time Domain
120
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
120