Related Experiment Video
Updated: Oct 20, 2025

Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
TIF-Reg: Point Cloud Registration with Transform-Invariant Features in SE(3)
Baifan Chen1, Hong Chen1, Baojun Song1
1School of Automation, Central South University, Changsha 410083, China.

Abstract:
Three-dimensional point cloud registration (PCReg) has a wide range of applications in computer vision, 3D reconstruction and medical fields. Although numerous advances have been achieved in the field of point cloud registration in recent years, large-scale rigid transformation is a problem that most algorithms still cannot effectively handle. To solve this problem, we propose a point cloud registration method based on learning and transform-invariant features (TIF-Reg). Our algorithm includes four modules, which are the transform-invariant feature extraction module, deep feature embedding module, corresponding point generation module and decoupled singular value decomposition (SVD) module. In the transform-invariant feature extraction module, we design TIF in SE(3) (which means the 3D rigid transformation space) which contains a triangular feature and local density feature for points. It fully exploits the transformation invariance of point clouds, making the algorithm highly robust to rigid transformation. The deep feature embedding module embeds TIF into a high-dimension space using a deep neural network, further improving the expression ability of features. The corresponding point cloud is generated using an attention mechanism in the corresponding point generation module, and the final transformation for registration is calculated in the decoupled SVD module. In an experiment, we first train and evaluate the TIF-Reg method on the ModelNet40 dataset. The results show that our method keeps the root mean squared error (RMSE) of rotation within 0.5∘ and the RMSE of translation error close to 0 m, even when the rotation is up to [-180∘, 180∘] or the translation is up to [-20 m, 20 m]. We also test the generalization of our method on the TUM3D dataset using the model trained on Modelnet40. The results show that our method's errors are close to the experimental results on Modelnet40, which verifies the good generalization ability of our method. All experiments prove that the proposed method is superior to state-of-the-art PCReg algorithms in terms of accuracy and complexity.
More Related Videos
 07:13
Author Spotlight: An Efficient and Robust Software for Automated Fusion of Multiple Preclinical Imaging Modalities
Published on: October 27, 2023
 02:09
Multi-modal Pulmonary Imaging: Using Complementary Information from CT and Hyperpolarized 129Xe MRI to Evaluate Lung Structure-Function
Published on: April 12, 2024
Related Concept Videos
 01:12
Transformation of Plane Strain
Under plane strain conditions, typical for members where one dimension significantly exceeds the others, deformations and resultant strains are...
 01:23
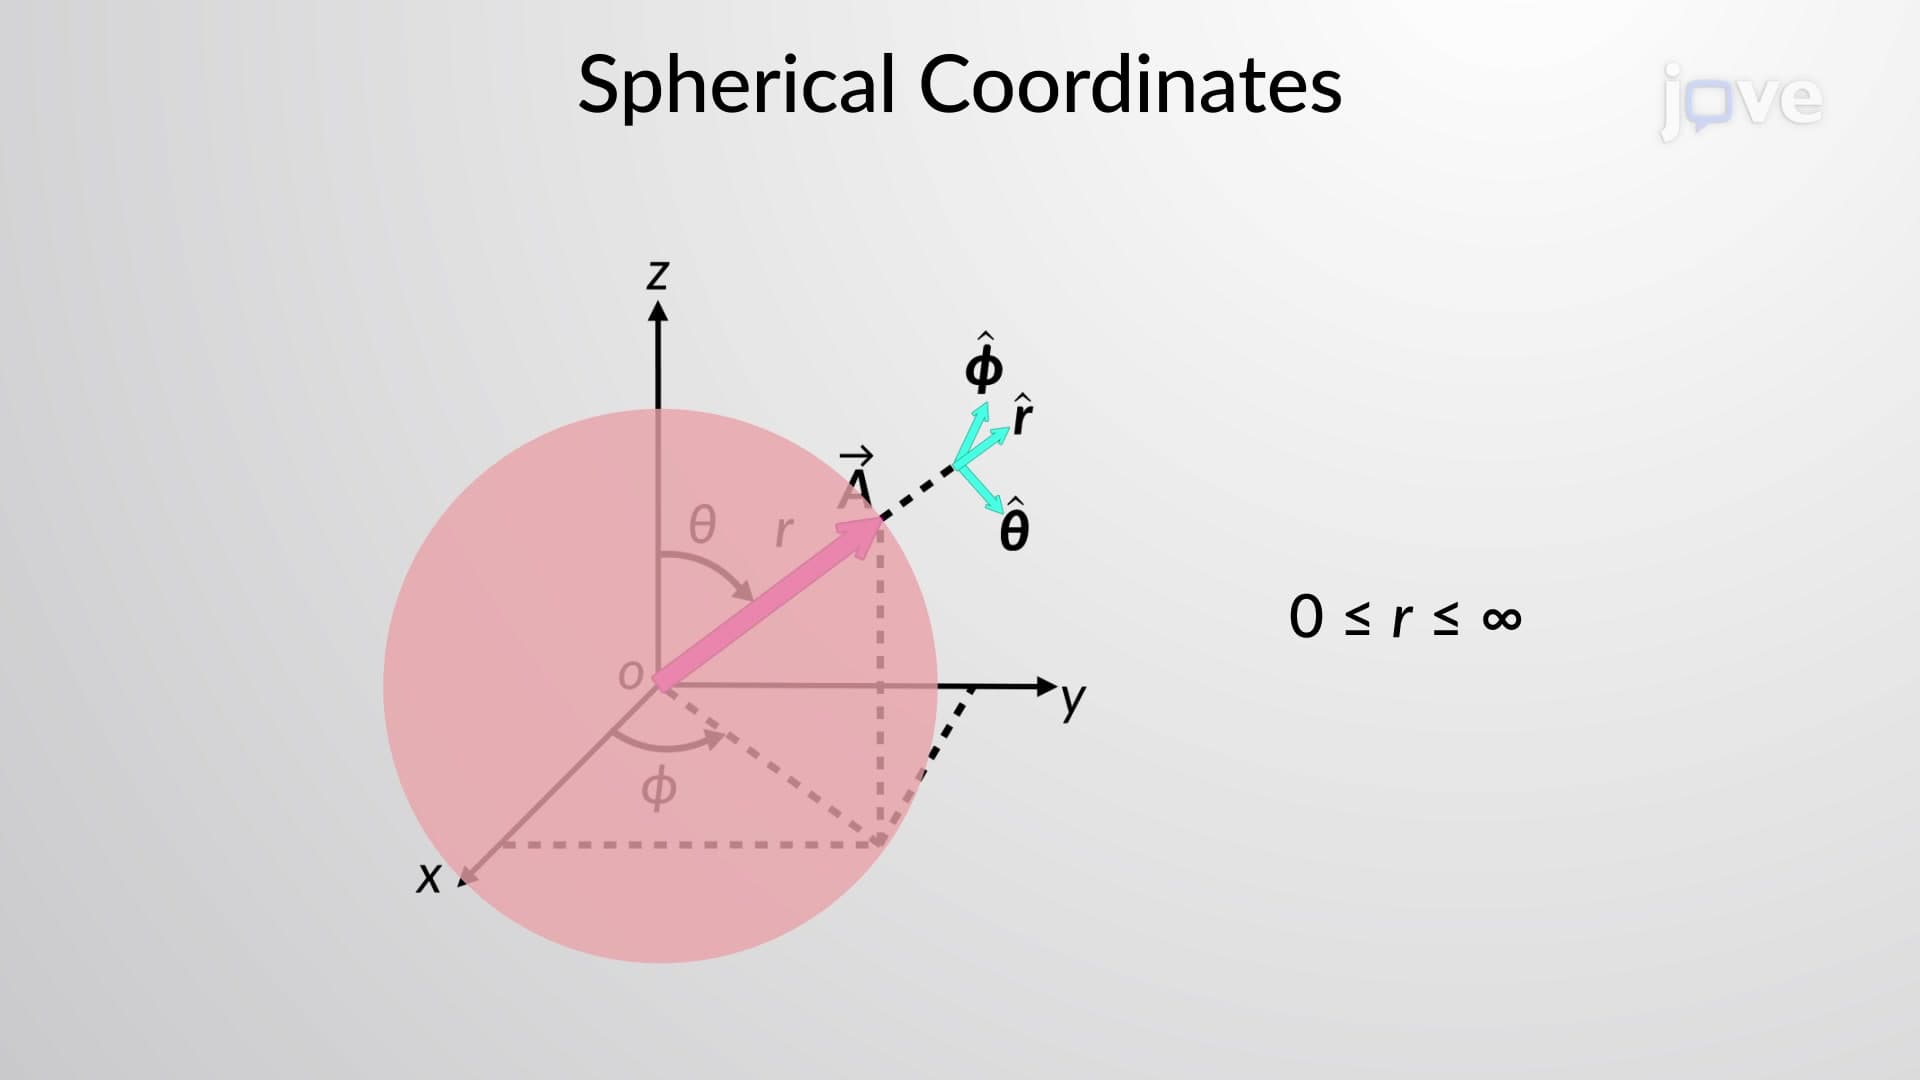
Spherical Coordinates
 01:28
Geoid and Ellipsoid
 01:18
Transformation of Plane Stress
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...