Related Experiment Video
Updated: Oct 19, 2025
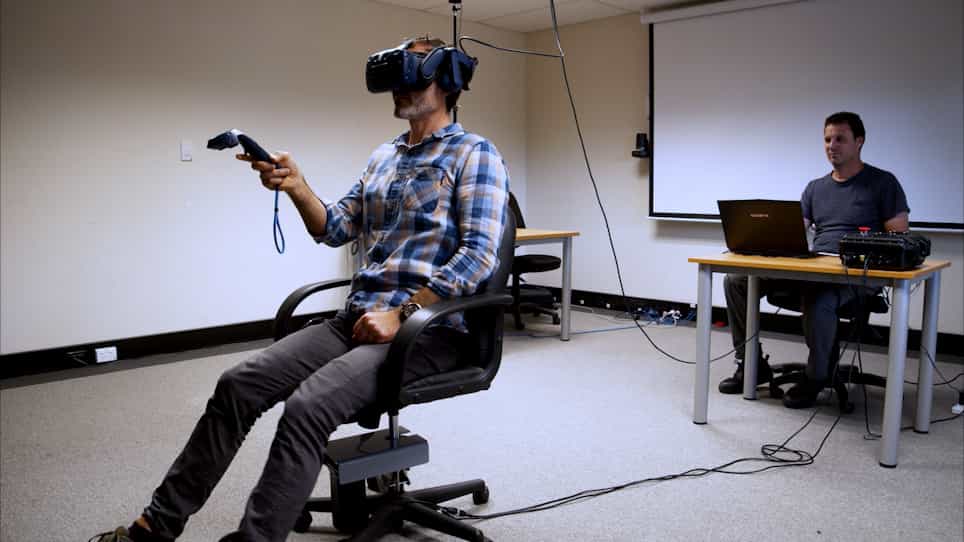

Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
Motion Polytopes in Virtual Reality for Shared Control in Remote Manipulation Applications
Mark Zolotas1, Murphy Wonsick1, Philip Long1,2
1Northeastern University, Boston, MA, United States.

Abstract:
In remote applications that mandate human supervision, shared control can prove vital by establishing a harmonious balance between the high-level cognition of a user and the low-level autonomy of a robot. Though in practice, achieving this balance is a challenging endeavor that largely depends on whether the operator effectively interprets the underlying shared control. Inspired by recent works on using immersive technologies to expose the internal shared control, we develop a virtual reality system to visually guide human-in-the-loop manipulation. Our implementation of shared control teleoperation employs end effector manipulability polytopes, which are geometrical constructs that embed joint limit and environmental constraints. These constructs capture a holistic view of the constrained manipulator's motion and can thus be visually represented as feedback for users on their operable space of movement. To assess the efficacy of our proposed approach, we consider a teleoperation task where users manipulate a screwdriver attached to a robotic arm's end effector. A pilot study with prospective operators is first conducted to discern which graphical cues and virtual reality setup are most preferable. Feedback from this study informs the final design of our virtual reality system, which is subsequently evaluated in the actual screwdriver teleoperation experiment. Our experimental findings support the utility of using polytopes for shared control teleoperation, but hint at the need for longer-term studies to garner their full benefits as virtual guides.
Related Concept Videos
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...