A Safety Reinforced Cooperative Adaptive Cruise Control Strategy Accounting for Dynamic Vehicle-to-Vehicle Communication Failure
Related Experiment Video
Updated: Oct 18, 2025
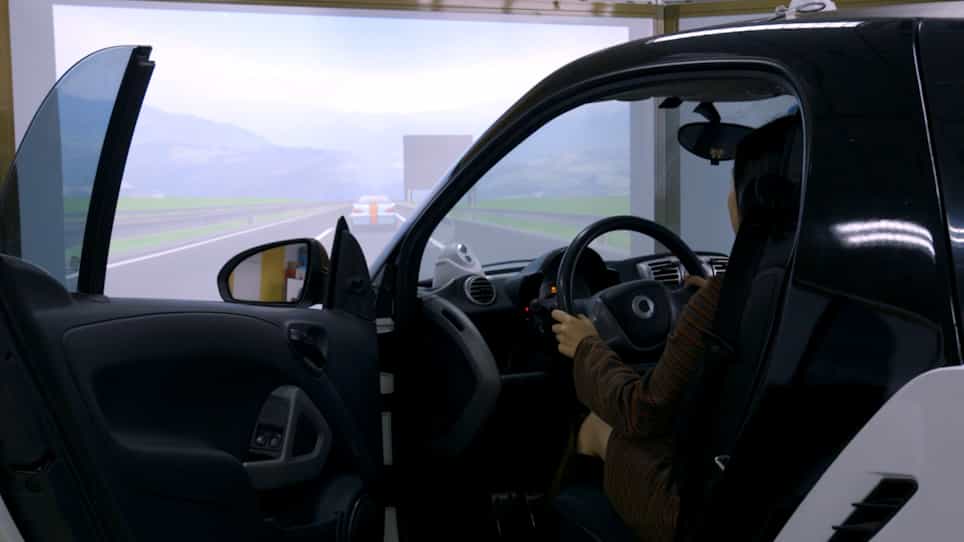
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
1Jiangsu Key Laboratory of Urban ITS, Southeast University, Si Pai Lou #2, Nanjing 210096, China.

Abstract:
Cooperative Adaptive Cruise Control (CACC) is an advanced technique for organizing and managing a vehicle platoon, which employs the Vehicle-to-Vehicle/Vehicle-to-Infrastructure (V2V/V2I, or V2X) wireless communication to minimize the inter-vehicle distance while guaranteeing string-stability. Consequently, the conventional CACC system relies heavily on the quality of communications, which means that the regular CACC platoon is sensitive to the communication failure. Therefore, in this paper, a Safety Reinforced Cooperative Adaptive Cruise Control (SR-CACC) strategy is proposed to resist unexpected communication failure. Different from the regular CACC system, the safety enhanced platoon control system is embedded with a dual-branch control strategy. When a fatal wireless communication failure is detected and confirmed, the SR-CACC system will automatically activate the alternative sensor-based adaptive cruise control strategy. Moreover, to make the transforming process smooth, a linear smooth transition algorithm is added to the SR-CACC system. Then, to verify the performance of the proposed SR-CACC system, we conducted a simulation experiment with a heterogonous platoon constructed with eight vehicles. The experiments results reveal that, under the extremely poor communication environment, the proposed SR-CACC strategy can significantly improve the safety performance of the organized vehicle platoon.

Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:17
Rolling Resistance: Problem Solving
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:10
Propagation of Uncertainty from Systematic Error
 01:19
Root-Locus Method
This system can be represented by a block...