Dynamic movements facilitate extreme gap crossing in flying snakes
Related Experiment Video
Updated: Oct 18, 2025
Author Spotlight: Bridging the Gap Between In Vivo and Ex Vivo Studies with the "Avatar" Technique to Advance Muscle Mechanics Research
Published on: August 18, 2023
Michelle Graham1, John J Socha1
1Department of Biomedical Engineering and Mechanics, Virginia Tech, Blacksburg, VA 24061, USA.

Abstract:
In arboreal habitats, direct routes between two locations can be impeded by gaps in the vegetation. Arboreal animals typically use dynamic movements, such as jumping, to navigate these gaps if the distance between supports exceeds their reaching ability. In contrast, most snakes only use the cantilever crawl to cross gaps. This behavior imposes large torques on the animal, inhibiting their gap-crossing capabilities. Flying snakes (Chrysopelea), however, are known to use dynamic behaviors in a different arboreal context: they use a high-acceleration jump to initiate glides. We hypothesized that flying snakes also use jumping take-off behaviors to cross gaps, allowing them to cross larger distances. To test this hypothesis, we used a six-camera motion-capture system to investigate the effect of gap size on crossing behavior in Chrysopelea paradisi, and analyzed the associated kinematics and torque requirements. We found that C. paradisi typically uses cantilevering for small gaps (<47.5% snout-vent length, SVL). Above this distance, C. paradisi were more likely to use dynamic movements than cantilevers, either arching upward or employing a below-branch loop of the body. These dynamic movements extended the range of horizontal crossing to ∼120% SVL. The behaviors used for the largest gaps were kinematically similar to the J-loop jumps used in gliding, and involved smaller torques than the cantilevers. These data suggest that the ability to jump allows flying snakes to access greater resources in the arboreal environment, and supports the broader hypothesis that arboreal animals jump across gaps only when reaching is not mechanically possible.
Related Concept Videos
 01:54
Convergent Evolution
 01:29
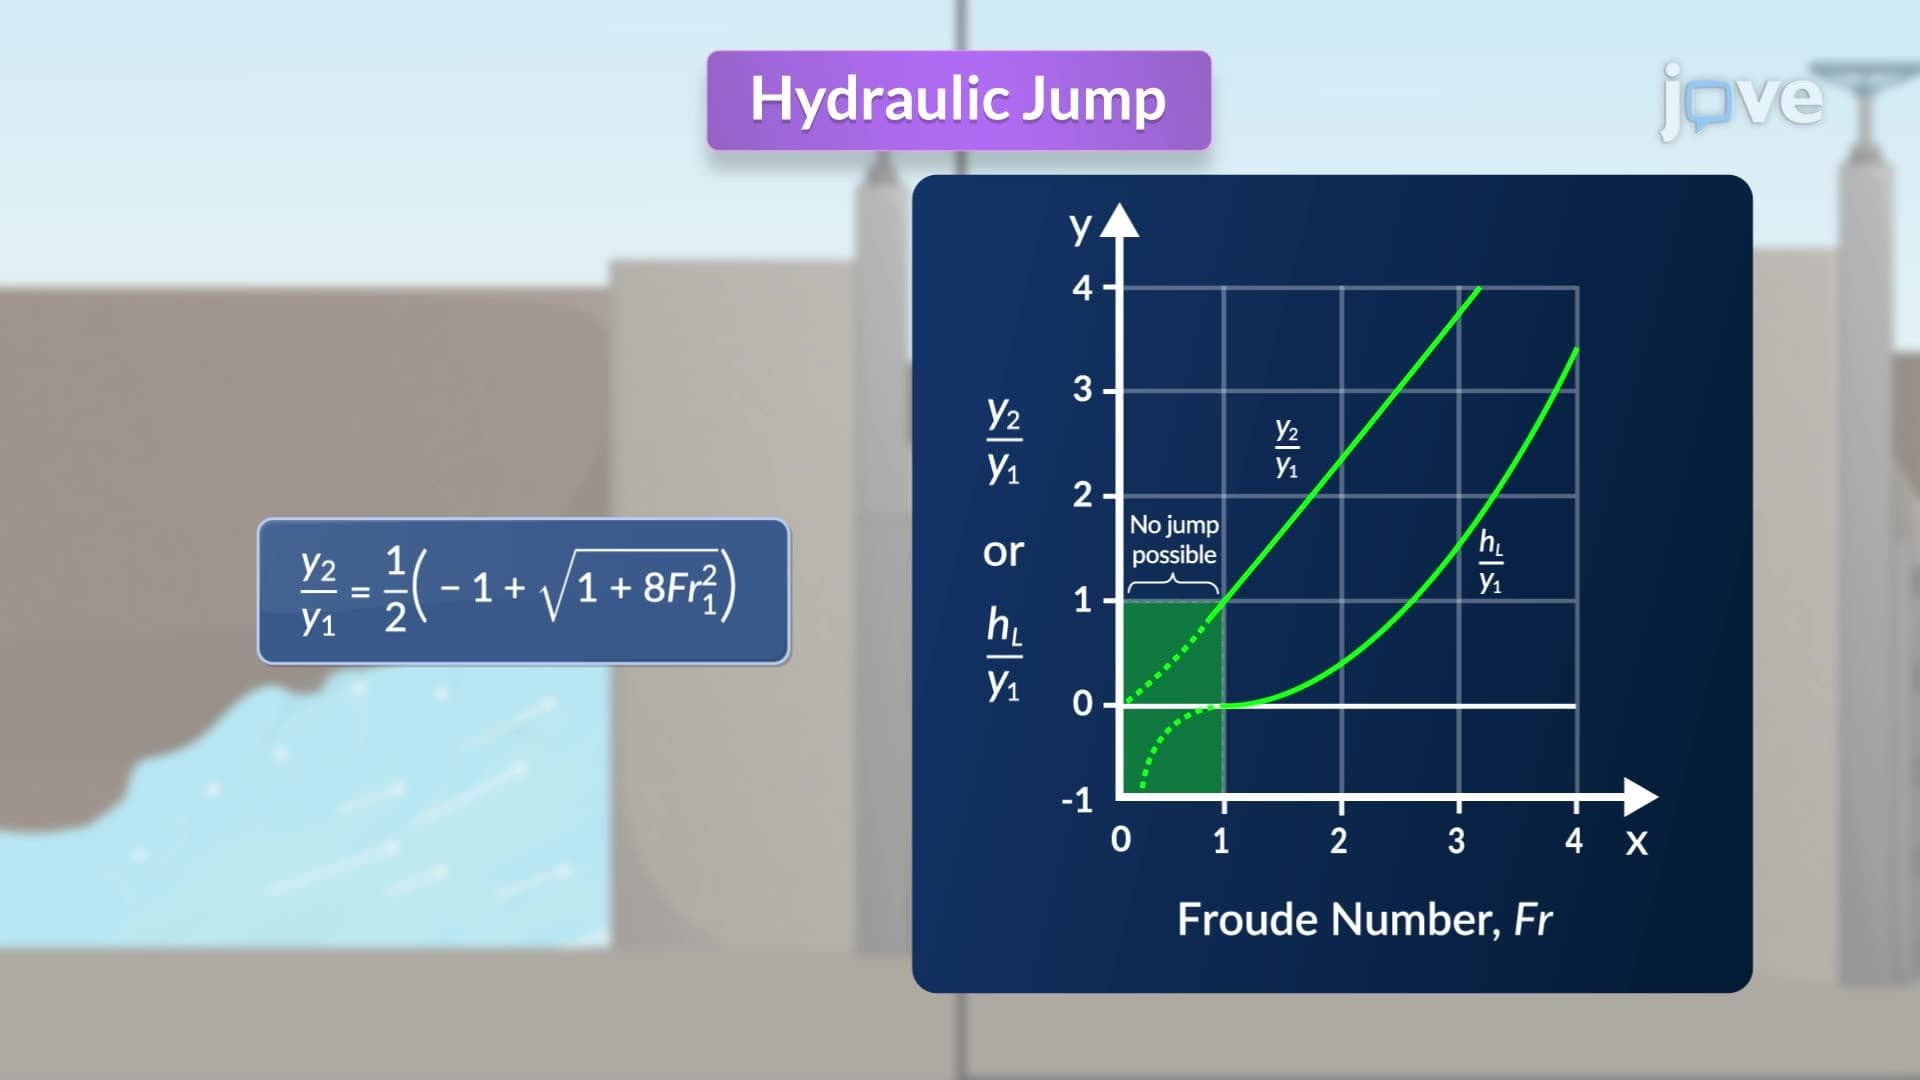
Hydraulic Jump
 01:16
Hydraulic Jump: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:18
Fluid Movement Between Compartments
 01:38
Limits to Natural Selection