Substrate-dependent friction and climbing performance in a flying snake
Related Experiment Video
Updated: Oct 31, 2026
FLEX: Flight Exercise Training Protocol for the Fruit Fly Drosophila
Published on: October 14, 2025
Jonas Scherer1, Hodjat Pendar2, John Socha3
1Biology, Bielefeld University, Universitätsstraße 25, Bielefeld, NRW, 33615, Germany.

Abstract:
Locomotion in limbless animals depends on friction between the body and substrate. In snakes, the skin-substrate interface can generate frictional anisotropy, lowering resistance during forward motion while increasing resistance during backward or transverse motion. These properties have inspired models and robots that rely on directional friction, yet empirical measurements remain limited across species and substrates. We measured static and dynamic coefficients of friction in a flying snake,Chrysopelea paradisi, using an inclined-plane method on four artificial substrates and one natural substrate, poplar bark. We quantified passive friction in forward, backward, and transverse directions in anesthetized snakes and estimated critical slip angles and whole-animal effective slip resistance in awake snakes, and examined climbing kinematics across platform inclinations. Across substrates, forward friction was lower than backward and transverse friction, and static friction differed strongly among substrates, with bark producing the highest resistance. In some trials on bark, ventral scales engaged asperities and intermittently caught the substrate, producing elevated apparent resistance not readily described as conventional friction. Awake snakes climbed progressively steeper inclines on high-purchase substrates and climbed vertically on bark. As purchase decreased on smoother substrates or steeper inclines, snakes increased lateral excursions, locomotion became less regular, and animals transitioned to an impulsive push gait with irregular anchors and intermittent slip. We also used a planar simulation to test how the transverse/forward friction ratio, μT/μF, influences net displacement. Increasing μT/μFincreased simulated displacement, but ratios near the biologically measured range produced limited displacement relative to higher-anisotropy conditions. Together, these results show that snake skin-substrate interactions depend not only on directional friction coefficients but also on discrete mechanical interaction with asperities. For bioinspired locomotor systems, effective anisotropic friction may require multiscale surface structure, intermittent anchoring, and modulation of body-substrate contact rather than simple Coulomb friction alone.
Related Concept Videos
 01:18
Drag Force and Terminal Speed
 01:05
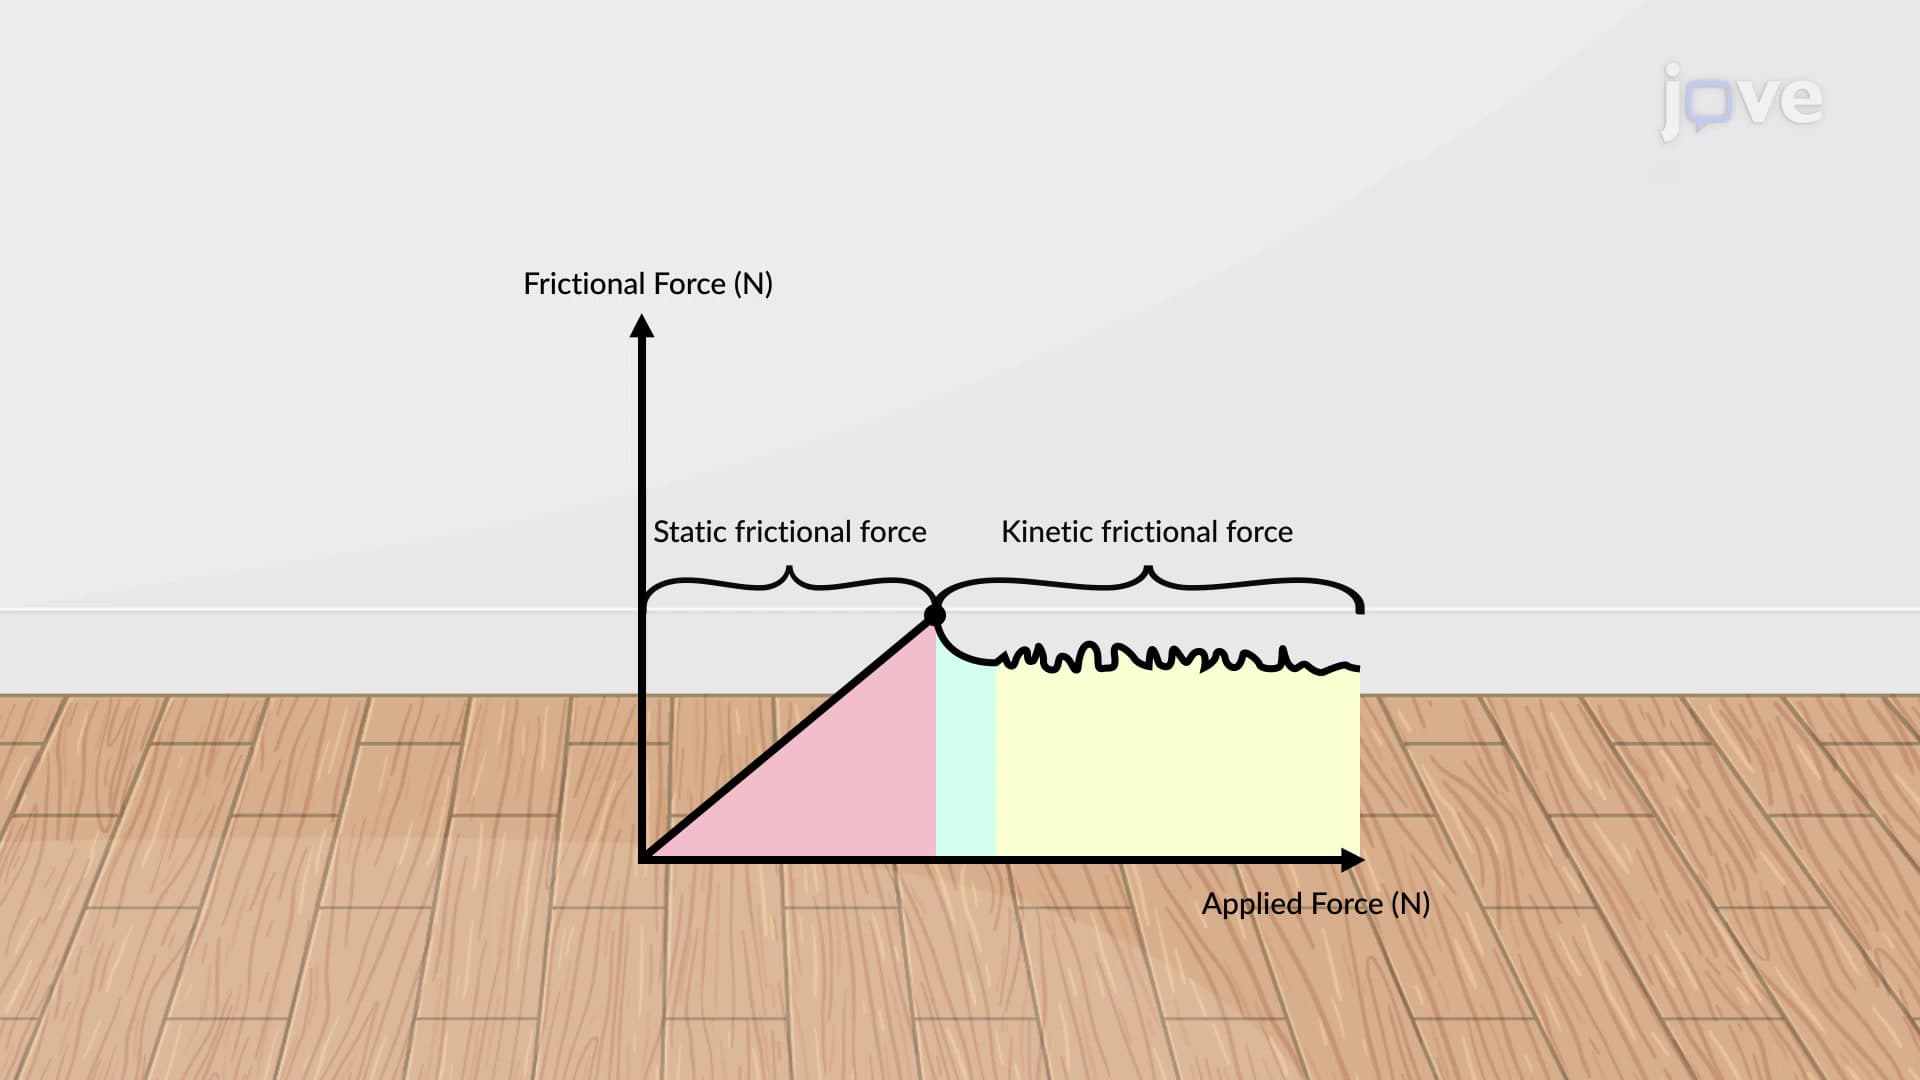
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...