Aerodynamic Robustness of Asynchronous Powered Wingbeats with Increasing Advance Ratios
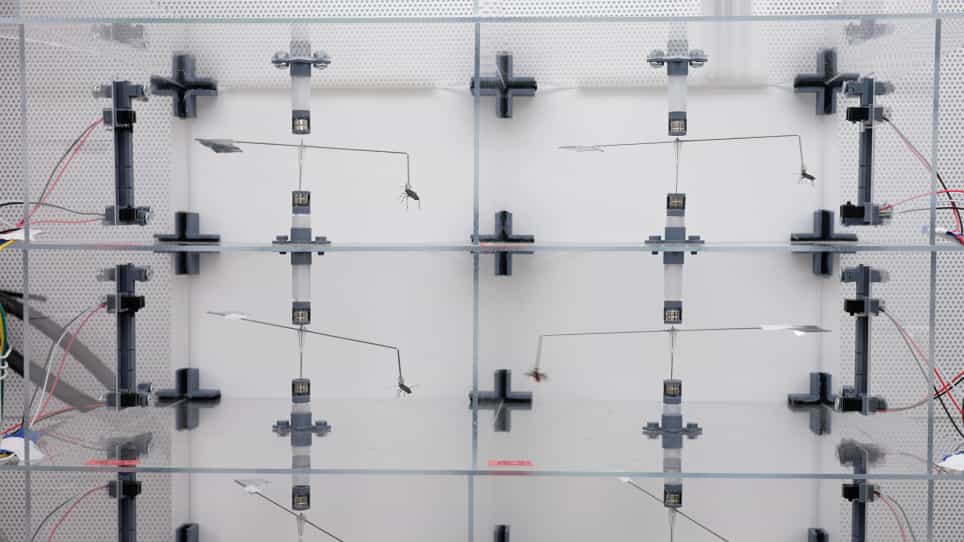
Related Experiment Video
Updated: Oct 31, 2026
Experimental Investigation of the Flow Structure over a Delta Wing Via Flow Visualization Methods
Published on: April 23, 2018
Ellen Liu1, Ethan Wold2, Rundong Yang3
1Physics, Georgia Institute of Technology, Howey Physics Bldg, 837 State St NW, Atlanta, Georgia, 30332-0002, United States.

Abstract:
Flapping insects produce wingbeats for steady flight by employing one of two actuation strategies. In synchronous actuation, each wingbeat is triggered by a time-periodic neural signal, like an externally forced oscillator. This exogenous forcing is not intrinsically dependent on the wingstroke kinematics. It is the strategy used by current flapping-wing micro air vehicles (FWMAVs). In contrast, asynchronous actuation involves wingbeats that self-excite due to an antagonistic pair of muscles that are activated by stretch, like an intrinsic oscillator where kinematics depend on aeromechanical interactions. Previous work has established how to predict these emergent asynchronous kinematics using the parameters of resonant flapping flight and muscle stretch activation. Wingstroke amplitude and frequency vary with wing inertia but, it is unclear how these kinematics would vary due to changing aerodynamic conditions such as varying freestream velocity (advance ratio). Using a robophysical model, we found that amplitude decreased significantly from comparable synchronous regimes. Asynchronous emergent kinematics automatically adjust due to aeromechanical interactions in forward flight. However, asynchronous frequency remained constant at low advance ratios, implying we do not require an additional timescale to model this phenomena. Asynchronous frequency did significantly decrease at higher freestream velocities comparable to insect forward flight speeds, but due to large reductions in amplitude the resulting advance ratio was beyond the range typically experienced by insects. At these high advance ratios, more complex aeromechanical interactions that affect flow structures may contribute to these reductions. The point at which these large reductions in amplitude occurred was dependent on the chosen asynchronous parameters. Additionally, the stability of asynchronous wing oscillations could be tuned to be higher or lower than those of synchronous oscillations at low amplitudes suggesting potential performance benefits. The tuning of asynchronous parameters to elicit a desired behavior may be useful to FWMAVs to automatically adapt to their environment.
Related Concept Videos
 01:23
Lift
 01:24
Wind Turbine Machine Models
Induction machines interact through the rotating magnetic field generated by the stator and the rotor. The key parameter is slip, which is the difference between synchronous speed and rotor speed relative to synchronous speed. Slip is...
 01:17
Design Example: Calculating Safe Diameter for Wind-Exposed Disc
 01:01
Bernoulli's Principle
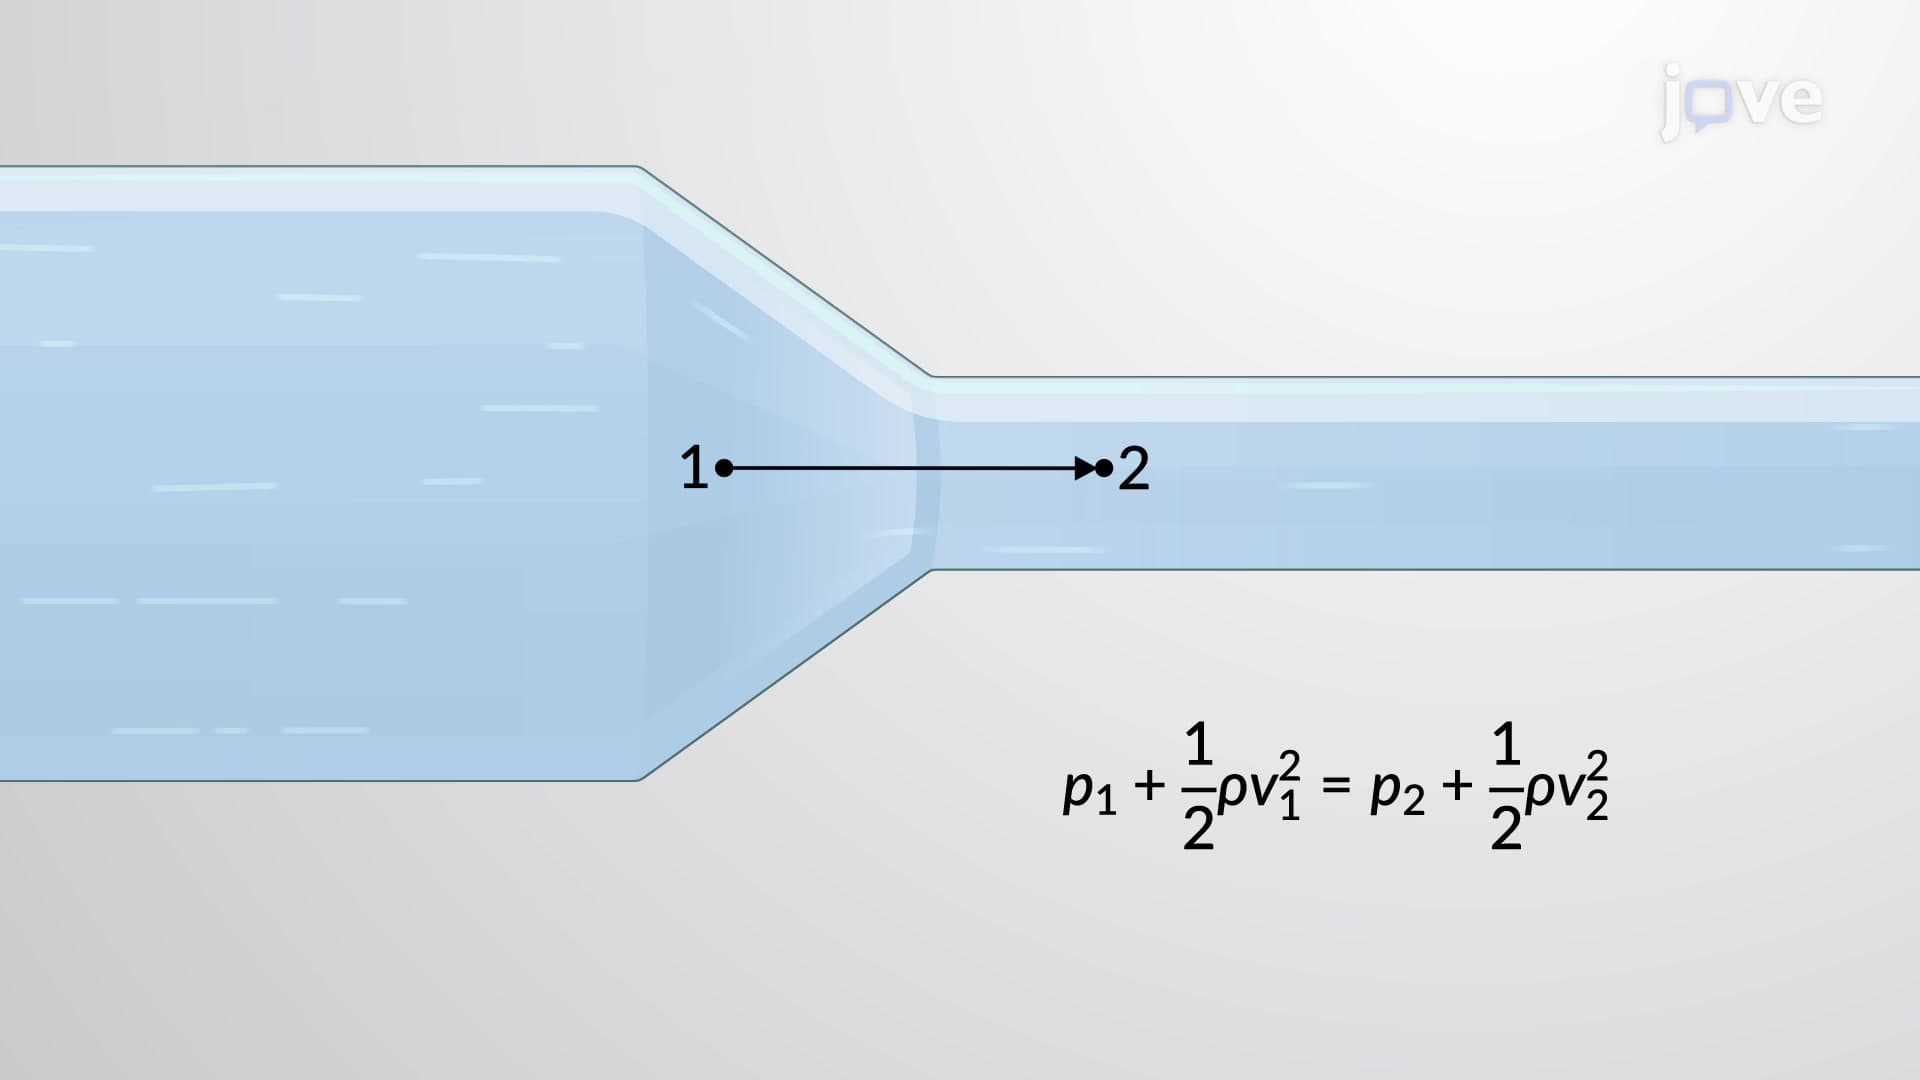
Bernoulli's principle has several applications. It is used...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:17
Bernoulli's Principle: Applications
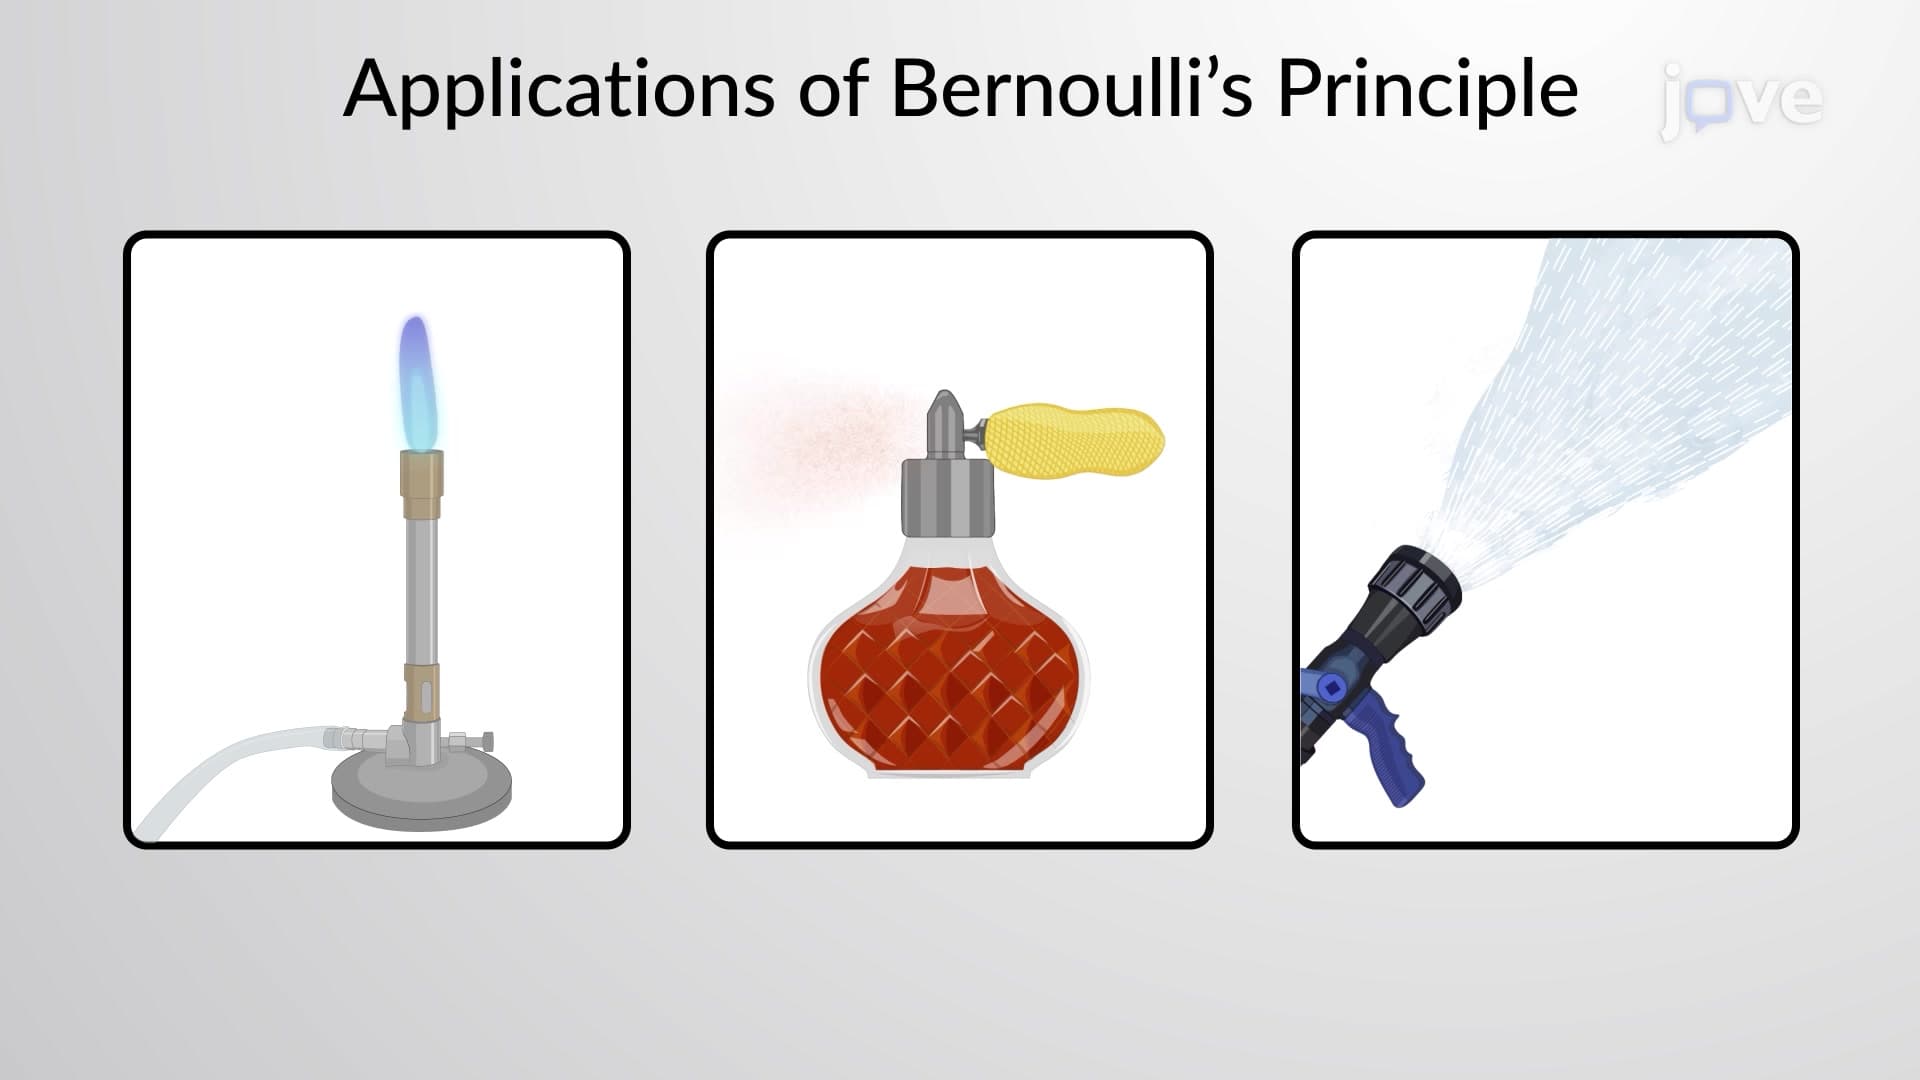
Entrainment devices use a high fluid speed to create low pressures and, thus, entrain one fluid into another. Some examples of these devices are given below: