Related Experiment Video
Updated: Oct 24, 2026
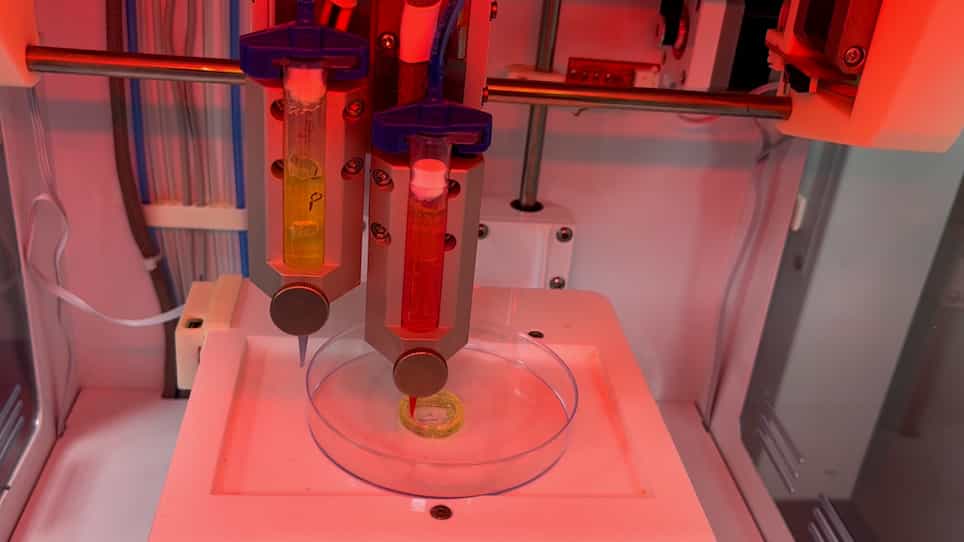
Four-Dimensional Printing of Stimuli-Responsive Hydrogel-Based Soft Robots
Published on: January 13, 2023
Multistable Kirigami Soft Grippers with Sustainable Magnetic Actuation and Conformal 3D/4D Printing
Moslem Mohammadi1, Euihyun Kim Kim2, Keun Park3
1School of Engineering, Deakin University, Geelong, Melbourne, 3125, Australia.

Abstract:
Soft robotic grippers are well suited to handling delicate and irregular objects, yet many remain difficult to deploy in practice due to high hardware overhead (pumps, valves, motors) and continuous energy demand during holding. This study presents a sustainable multi-stable soft gripper that decouples activation from holding and reduces manufacturing waste through mandrel-based, support-free multi-material fused filament fabrication (FFF). The gripper is a thin-walled cylindrical shell patterned with a circumferential auxetic kirigami lattice composed of bistable unit cells. Sequential snap-through transitions among the graded cell groups give rise to multistable behaviour at the gripper level, while the fully closed and fully deployed states serve as the functional grasping and object-acquisition states, respectively. A magnetically responsive distal tip, allows non-contact triggering to switch the structure into an expanded, truncated-cone open state for object acquisition, followed by snap-back to the closed state for passive grasping. Mechanical characterizations quantified activation and holding performance for two gripper sizes (36 mm and 58 mm initial diameters). The small gripper, with 25g weight and up to 48 payload-to-weight ratios, reliably activated across pulling speeds from 10 to 1385 mm·min⁻¹, showing repeatable multi-peak snap-through behaviour and consistent activation displacement of ~20 mm, with peak activation forces of approximately 10-12 N under six-magnet loading. Object pull-out tests demonstrated stable passive holding, with maximum pull-out forces ranging from ~3-5 N for 40-48 mm circular objects (small gripper) and up to ~17 N for non-circular objects (large gripper), with higher forces often arising from passive geometric interlocking. Finite element simulations using a Mooney-Rivlin hyperelastic TPE model reproduced the snap-through sequence and instability locations, supporting interpretation of the activation mechanics. Robotic demonstrations on a 3-DoF arm further validated practical pick-and-place capability without onboard actuation or sensing.

