Related Experiment Video
Updated: Oct 14, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Bounded rational response equilibria in human sensorimotor interactions
Cecilia Lindig-León1, Gerrit Schmid1, Daniel A Braun1
1Institute of Neural Information Processing, Faculty of Engineering, Computer Science and Psychology, Ulm University, Germany.

Abstract:
The Nash equilibrium is one of the most central solution concepts to study strategic interactions between multiple players and has recently also been shown to capture sensorimotor interactions between players that are haptically coupled. While previous studies in behavioural economics have shown that systematic deviations from Nash equilibria in economic decision-making can be explained by the more general quantal response equilibria, such deviations have not been reported for the sensorimotor domain. Here we investigate haptically coupled dyads across three different sensorimotor games corresponding to the classic symmetric and asymmetric Prisoner's Dilemma, where the quantal response equilibrium predicts characteristic shifts across the three games, although the Nash equilibrium stays the same. We find that subjects exhibit the predicted deviations from the Nash solution. Furthermore, we show that taking into account subjects' priors for the games, we arrive at a more accurate description of bounded rational response equilibria that can be regarded as a quantal response equilibrium with non-uniform prior. Our results suggest that bounded rational response equilibria provide a general tool to explain sensorimotor interactions that include the Nash equilibrium as a special case in the absence of information processing limitations.

Related Concept Videos
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 00:49
Rigid Body Equilibrium Problems - I
 01:11
Types of Responses of Series RLC Circuits
 01:28
Conditions of Equilibrium
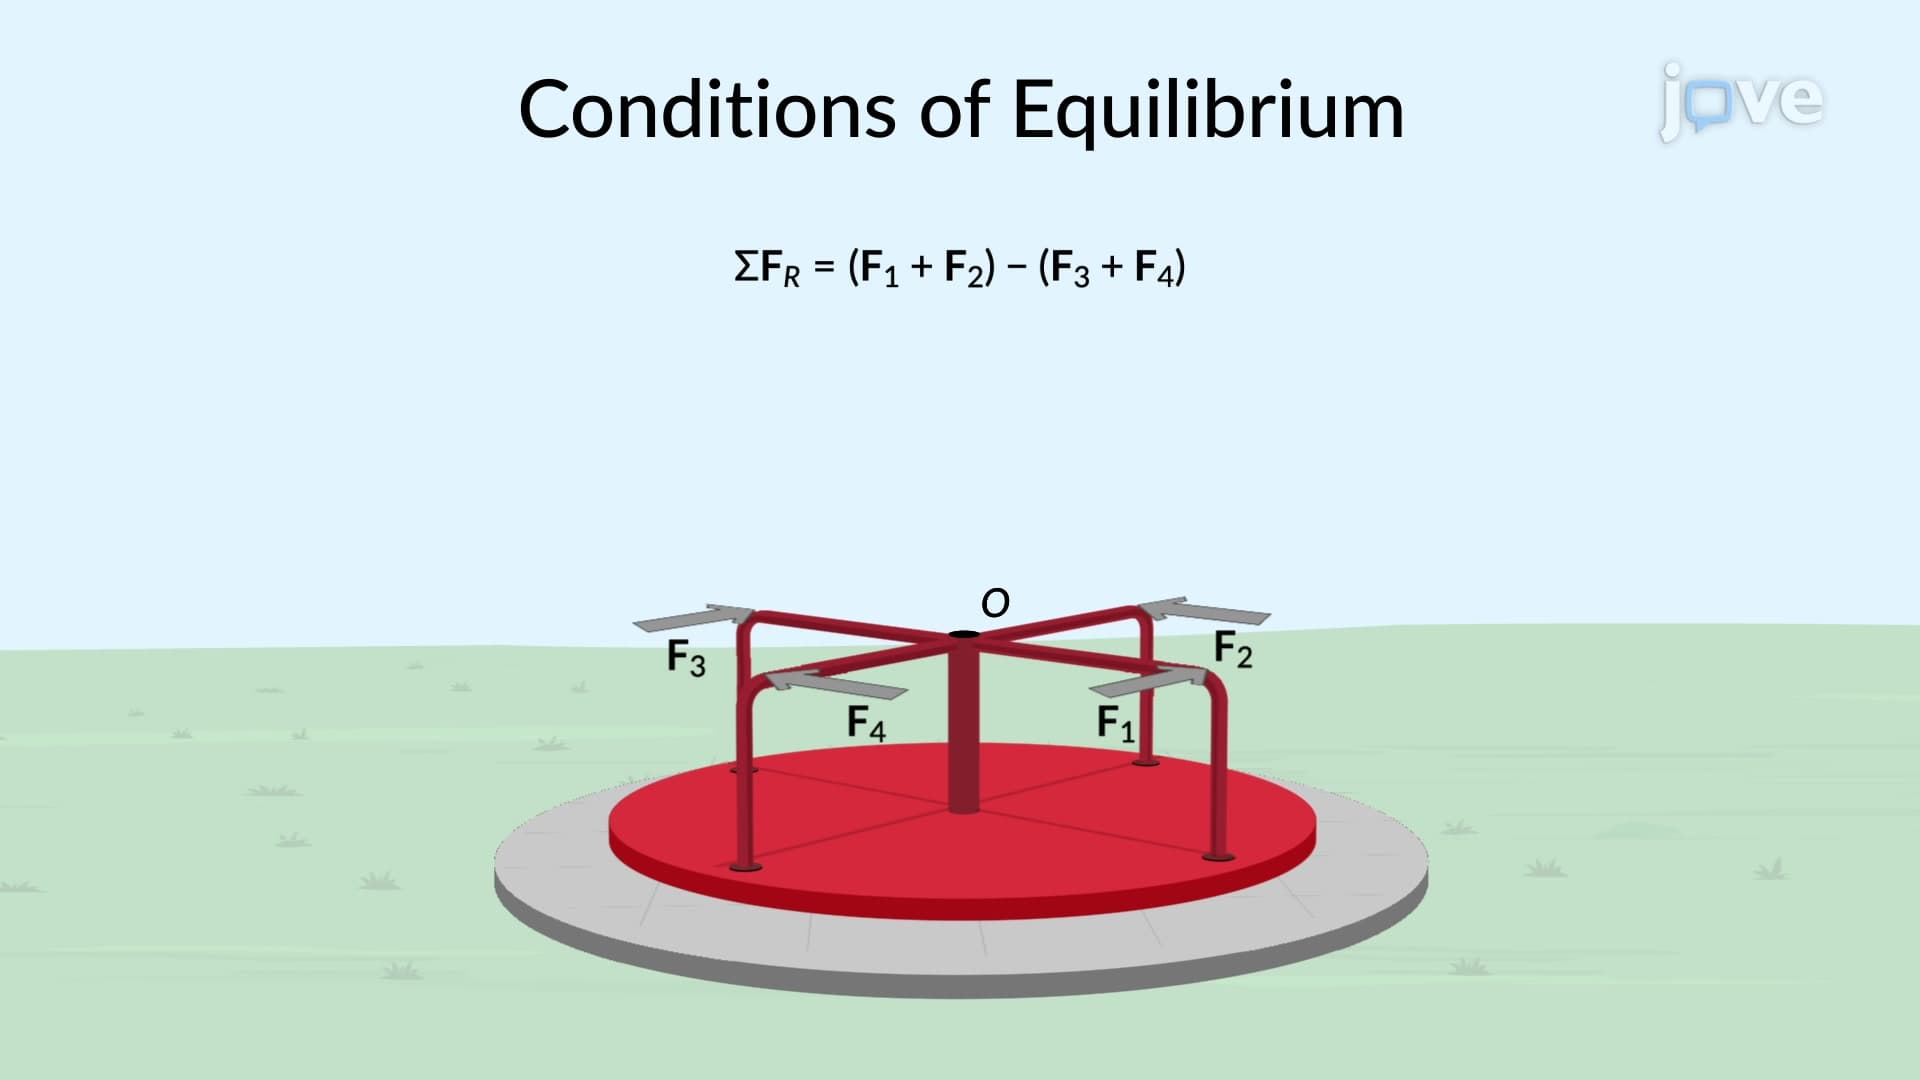
Internal forces are not considered for conditions of equilibrium because they occur in equal and opposite pairs within the body, effectively canceling each other. As a result,...
 01:15
Equilibrium and Balance