Related Experiment Video
Updated: Oct 12, 2025

Design and Characterization Methodology for Efficient Wide Range Tunable MEMS Filters
Published on: February 4, 2018
A Novel Parallel Processing Model for Noise Reduction and Temperature Compensation of MEMS Gyroscope
Qi Cai1, Fanjing Zhao2, Qiang Kang3
1Science and Technology on Electronic Test & Measurement Laboratory, North University of China, Taiyuan 030051, China.

Abstract:
To eliminate the noise and temperature drift in an Micro-Electro-Mechanical Systems (MEMS) gyroscope's output signal for improving measurement accuracy, a parallel processing model based on Multi-objective particle swarm optimization based on variational modal decomposition-time-frequency peak filter (MOVMD-TFPF) and Beetle antennae search algorithm- Elman neural network (BAS-Elman NN) is established. Firstly, variational mode decomposition (VMD) is optimized by multi-objective particle swarm optimization (MOPSO); then, the best decomposition parameters [kbest,abest] can be obtained. Secondly, the gyroscope output signals are decomposed by VMD optimized by MOPSO (MOVMD); then, the intrinsic mode functions (IMFs) obtained after decomposition are classified into a noise segment, mixed segment, and drift segment by sample entropy (SE). According to the idea of a parallel model, the noise segment can be discarded directly, the mixed segment is denoised by time-frequency peak filtering (TFPF), and the drift segment is compensated at the same time. In the compensation part, the beetle antennae search algorithm (BAS) is adopted to optimize the network parameters of the Elman neural network (Elman NN). Subsequently, the double-input/single-output temperature compensation model based on the BAS-Elman NN is established to compensate the drift segment, and these processed segments are reconstructed to form the final gyroscope output signal. Experimental results demonstrate the superiority of this parallel processing model; the angle random walk of the compensated gyroscope output is decreased from 0.531076 to 5.22502 × 10⁻³°/h/√Hz, and its bias stability is decreased from 32.7364°/h to 0.140403°/h, respectively.
More Related Videos
 11:44
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:24
Gyroscope: Precession
 01:02
Gyroscope
 01:22
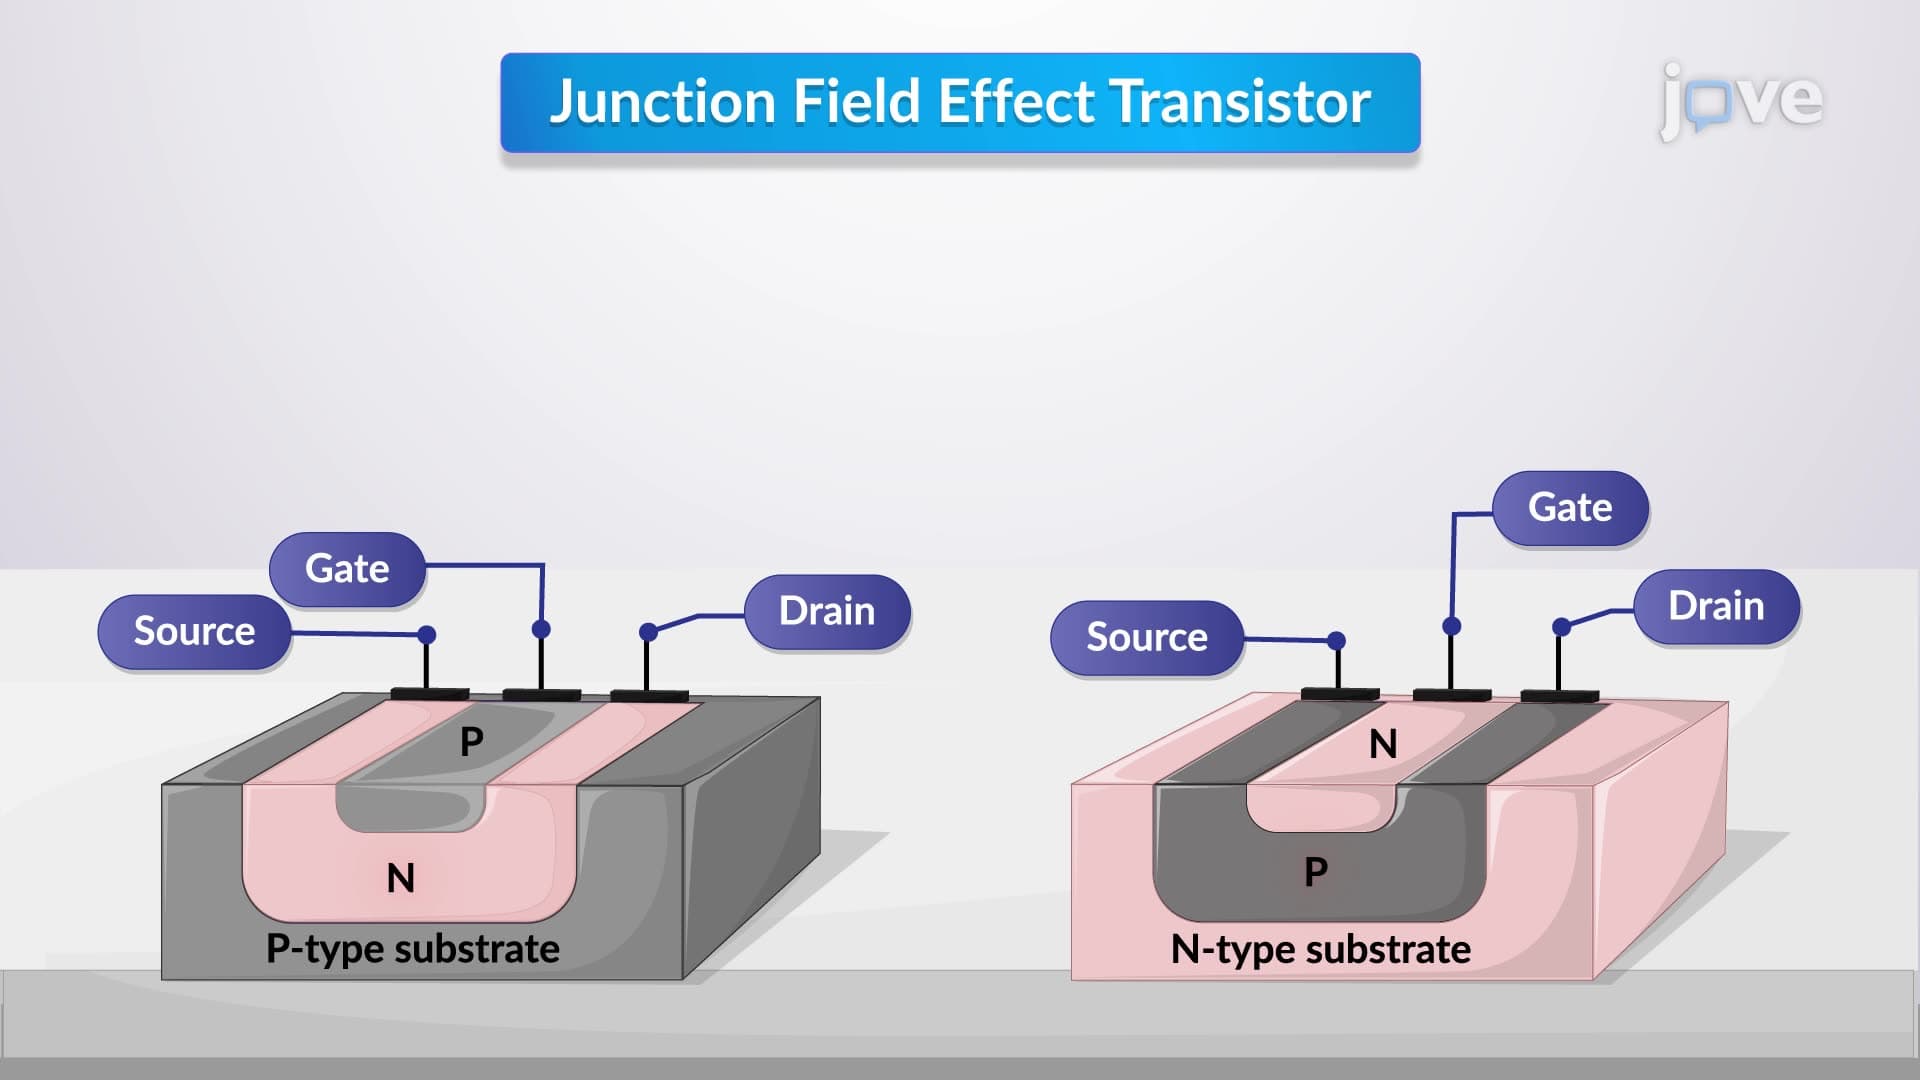
Biasing of FET
In an N-channel JFET, the structure consists of N-type material forming the channel on a P-type substrate, with the...
 01:20
Parallel Processing
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...