Related Experiment Video
Updated: Oct 11, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Robust adaptive control for uncertain nonlinear systems with odd rational powers, unmodeled dynamics, and
Zhen-Guo Liu1, Wei Sun2, Weidong Zhang3
1School of Automation and Software Engineering, Shanxi University, Taiyuan 030006, China; Department of Automation, Shanghai Jiao Tong University, Shanghai, 200240, China.

Abstract:
Numerous approaches have been reported for different control problems of low-order triangular nonlinear systems. Nevertheless, it shows that the dynamic models of some practical plants are high-order nonlinear systems with odd rational powers. Besides, these systems constantly possess a non-triangular form and suffer from the impact of unmodeled dynamics. The related studies of such systems are very few and more challenging. This work concentrates on adaptive control issue of high-order nonlinear system with odd rational powers, unmodeled dynamics, and non-triangular structure. Based on the small-gain theorem, and by employing the adaptive technique, adding a power integrator method, and neural network method, we successfully construct a new adaptive controller, which greatly decreases the use of parameter estimations in the adaptive control of the considered system. An example highlights that the strategy regulates the studied systems well and performs satisfied system responses.
More Related Videos
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:19
Routh-Hurwitz Criterion II
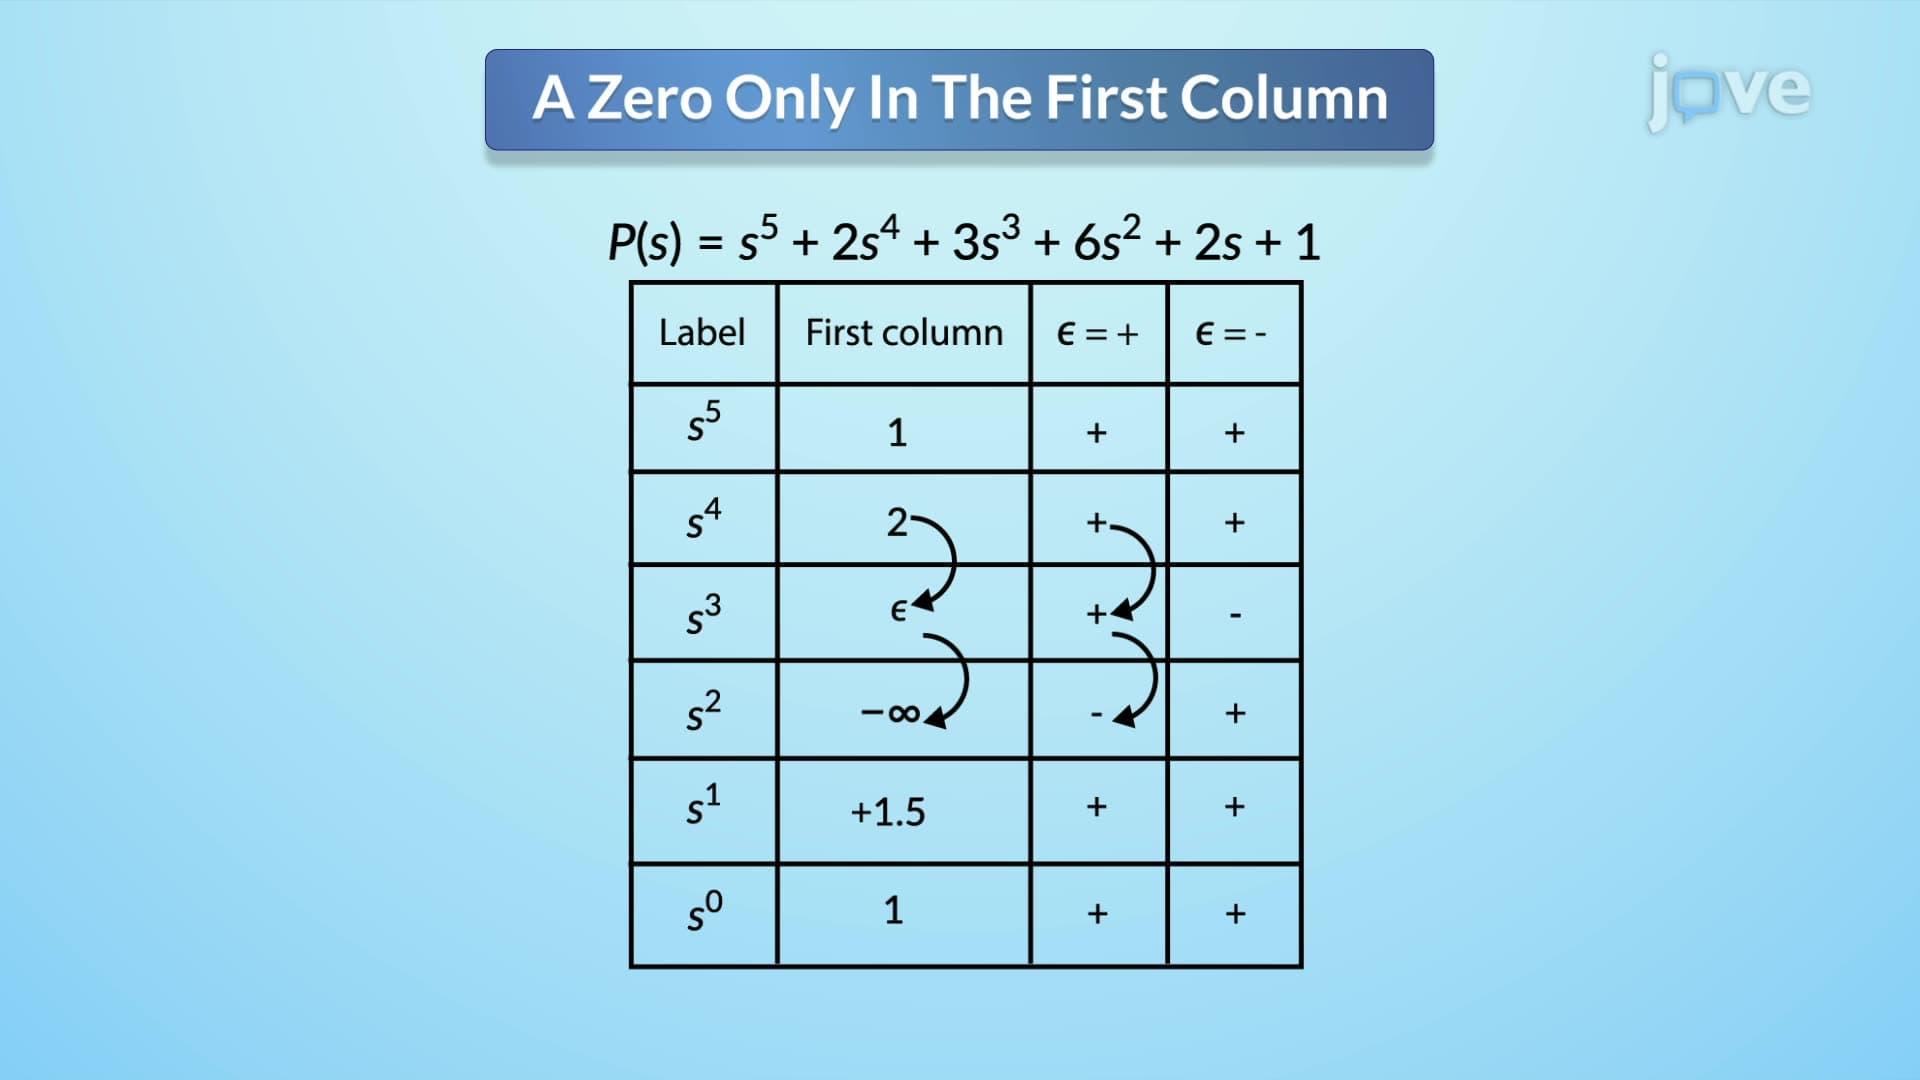
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 01:10
Control Systems
At the heart...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...