Related Experiment Video
Updated: Oct 9, 2025

Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Implicit Contact Dynamics Modeling With Explicit Inertia Matrix Representation for Real-Time, Model-Based Control in
Takeshi D Itoh1, Koji Ishihara2, Jun Morimoto3
1Department of Brain Robot Interface, ATR Computational Neuroscience Laboratories, Kyoto, 619-0288, Japan, and Graduate School of Science and Technology, Nara Institute of Science and Technology, Nara, 630-0192, Japan itoh.takeshi.ik4@is.naist.jp.

Abstract:
Model-based control has great potential for use in real robots due to its high sampling efficiency. Nevertheless, dealing with physical contacts and generating accurate motions are inevitable for practical robot control tasks, such as precise manipulation. For a real-time, model-based approach, the difficulty of contact-rich tasks that requires precise movement lies in the fact that a model needs to accurately predict forthcoming contact events within a limited length of time rather than detect them afterward with sensors. Therefore, in this study, we investigate whether and how neural network models can learn a task-related model useful enough for model-based control, that is, a model predicting future states, including contact events. To this end, we propose a structured neural network model predictive control (SNN-MPC) method, whose neural network architecture is designed with explicit inertia matrix representation. To train the proposed network, we develop a two-stage modeling procedure for contact-rich dynamics from a limited number of samples. As a contact-rich task, we take up a trackball manipulation task using a physical 3-DoF finger robot. The results showed that the SNN-MPC outperformed MPC with a conventional fully connected network model on the manipulation task.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Kinematic Equations - I
 01:24
Inertia Tensor
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:13
Linear Momentum in Control Volume
 01:22
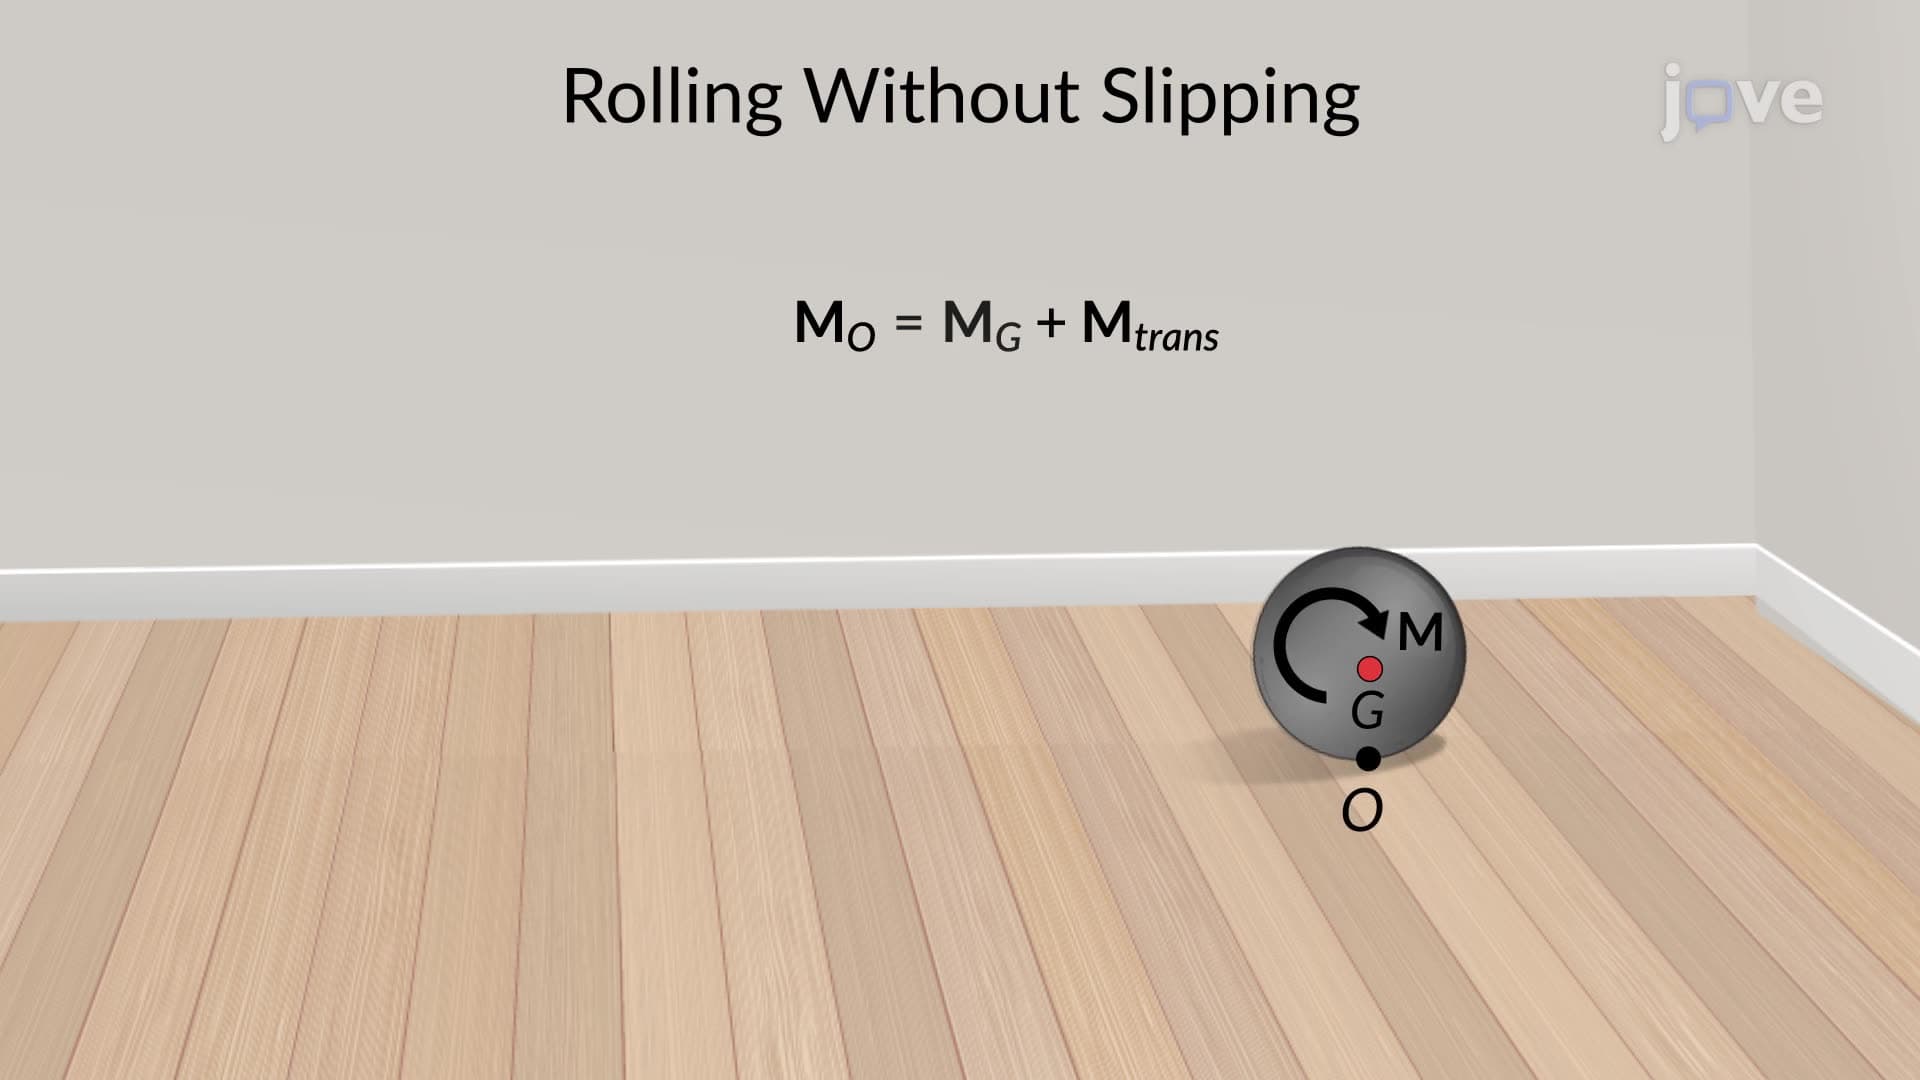
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the...