Related Experiment Video
Updated: Jan 15, 2026


Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Dynamical modeling of torso stability in running via hip-knee three pairs of six springs
Hidaka Asai1,2, Tomoyuki Noda1, Jun Morimoto1,2
1Brain Robot Interface, ATR Computational Neuroscience Labs, Kyoto, Japan.

Abstract:
Prior spring-mass locomotion models achieve stable gaits by prescribing a constant touchdown angle (TD angle) during the flight phase; however, they either exclude torso modeling or depend on online state feedback to stabilize the pitch angle of the torso. In contrast, evidence from biology and robotics suggests that coordinating monoarticular and biarticular hip-knee muscles supports whole-body stability with the simplified controller without online state feedback. However, this has only been verified through empirical and constructive approaches, rather than through dynamical modeling. To verify this hypothesis, we propose a new mathematical dynamical model, torso-hip-knee three pairs of six springs, a planar locomotion model that consists of a torso and coordinated springs imitating a three-pair six-muscle structure in the upper leg. The proposed dynamical model achieves stable running solely by giving a constant TD angle and a constant kicking angle relative to the torso, which control the dynamics during the flight and stance phases respectively. Numerical analysis utilizing Floquet multipliers demonstrates that self-stability emerges across stiffness parameters of coordinated springs. These results constitute the first mathematical evidence that muscle coordination, including biarticular muscles, can stabilize torso pitch during locomotion and provide guidelines for legged-robot design and rehabilitation assessment.


Related Concept Videos
 01:14
Stability of structures
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:30
Three-Dimensional Force System
 01:23
Euler's Formula to Columns: Problem Solving
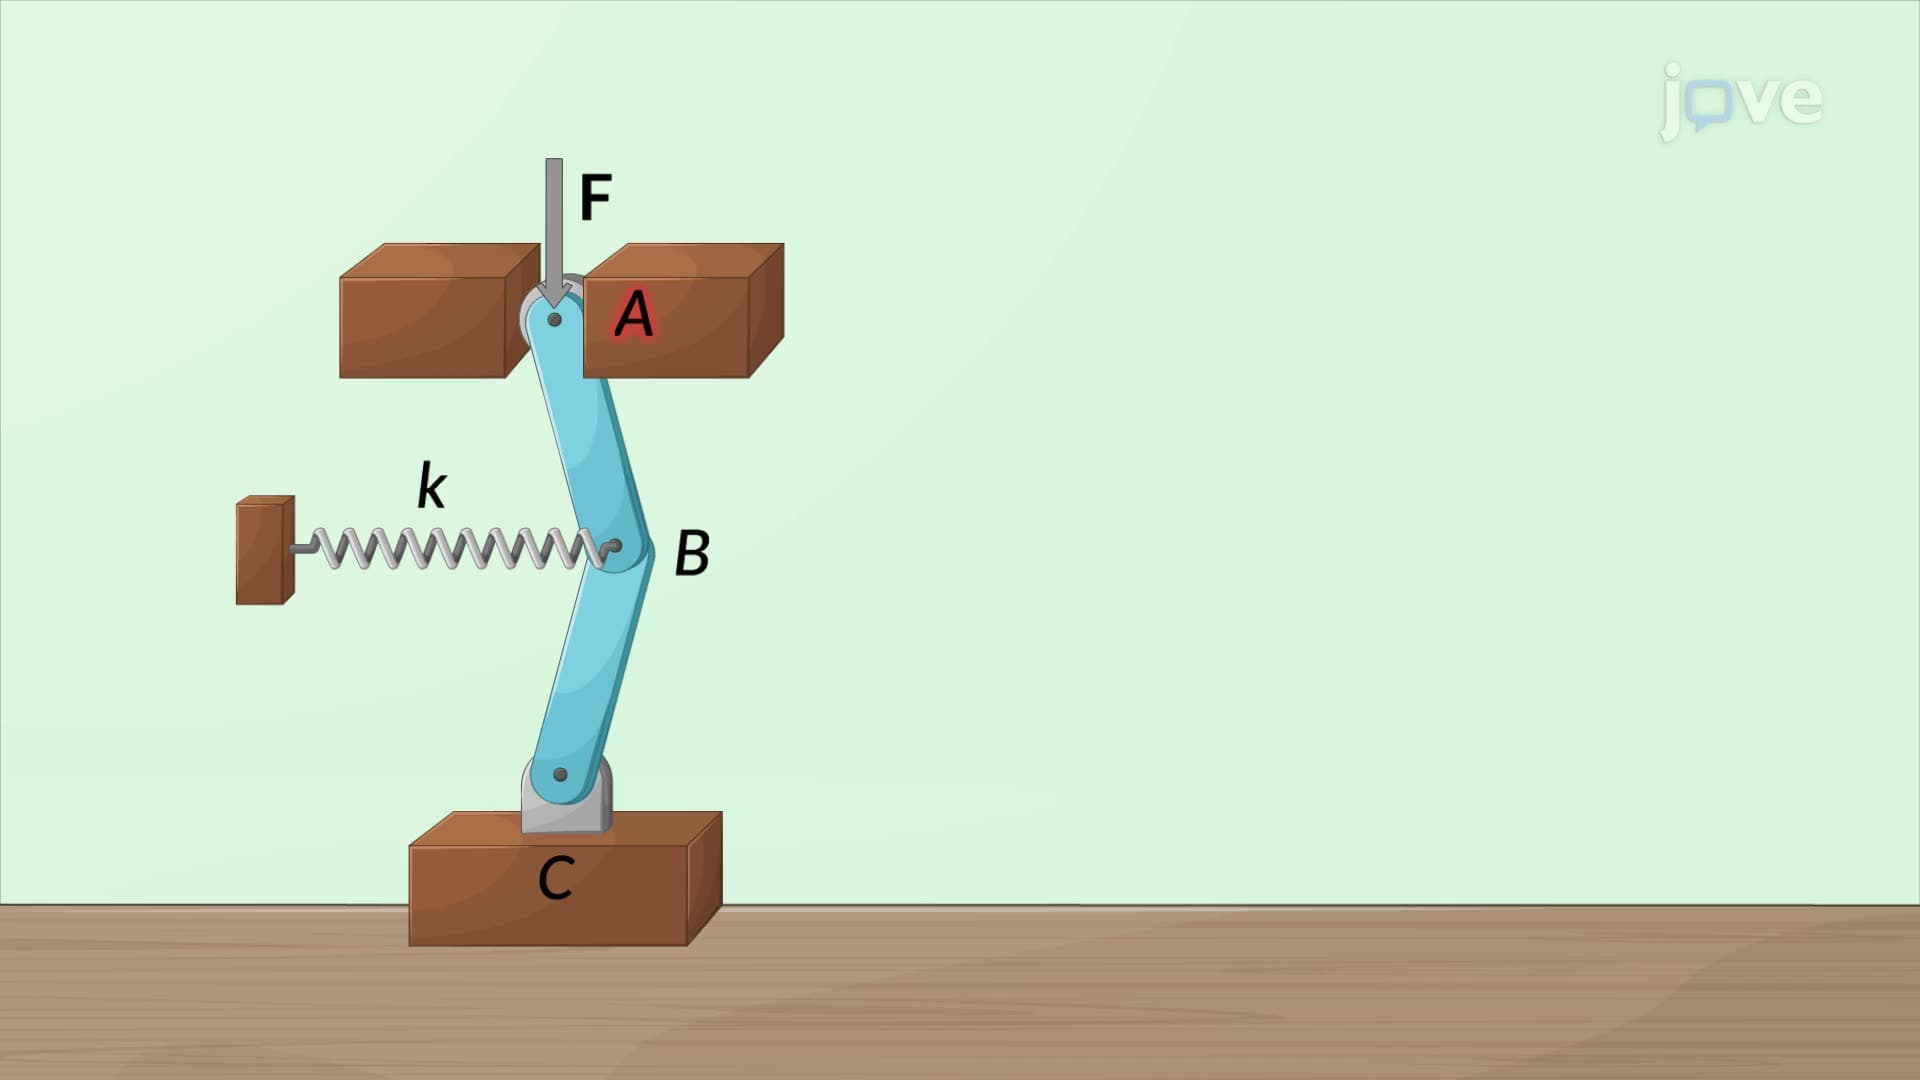
The system comprises two vertical rigid bars, AB and BC, of...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...