Related Experiment Video
Updated: Oct 3, 2025


An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Research on a Silicon Gyroscope Interface Circuit Based on Closed-Loop Controlled Drive Loop
Qiang Li1,2, Lifeng Ding3, Xiaowei Liu4
1Shanxi Key Laboratory of Micro Nano Sensors & Artificial Intelligence Perception, College of Information and Computer, Taiyuan University of Technology, Taiyuan 030024, China.

Abstract:
The existing analysis methods for the silicon gyroscope drive loop, such as the perturbation method and period average method, cannot analyze the dynamic characteristics of the system. In this work, a linearized amplitude control model of the silicon gyroscope drive loop was established to analyze the stability and set-up time of the drive loop, and the vibration conditions of the silicon gyro were obtained. According to the above results, a new silicon gyroscope interface circuit was designed, using a 0.35 μm Bipolar-CMOS-DMOS (BCD) process, and the chip area was 4.5 mm × 4.0 mm. The application-specific integrated circuit (ASIC) of the silicon gyroscope was tested in combination with the sensitive structure with a zero stability of 1.14°/hr (Allen). The test results for the ASIC and the whole machine prove the correctness of the theoretical model, which reflects the effectiveness of the stability optimization of the closed-loop controlled drive loop of the silicon gyroscope circuit.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:02
Gyroscope
 01:24
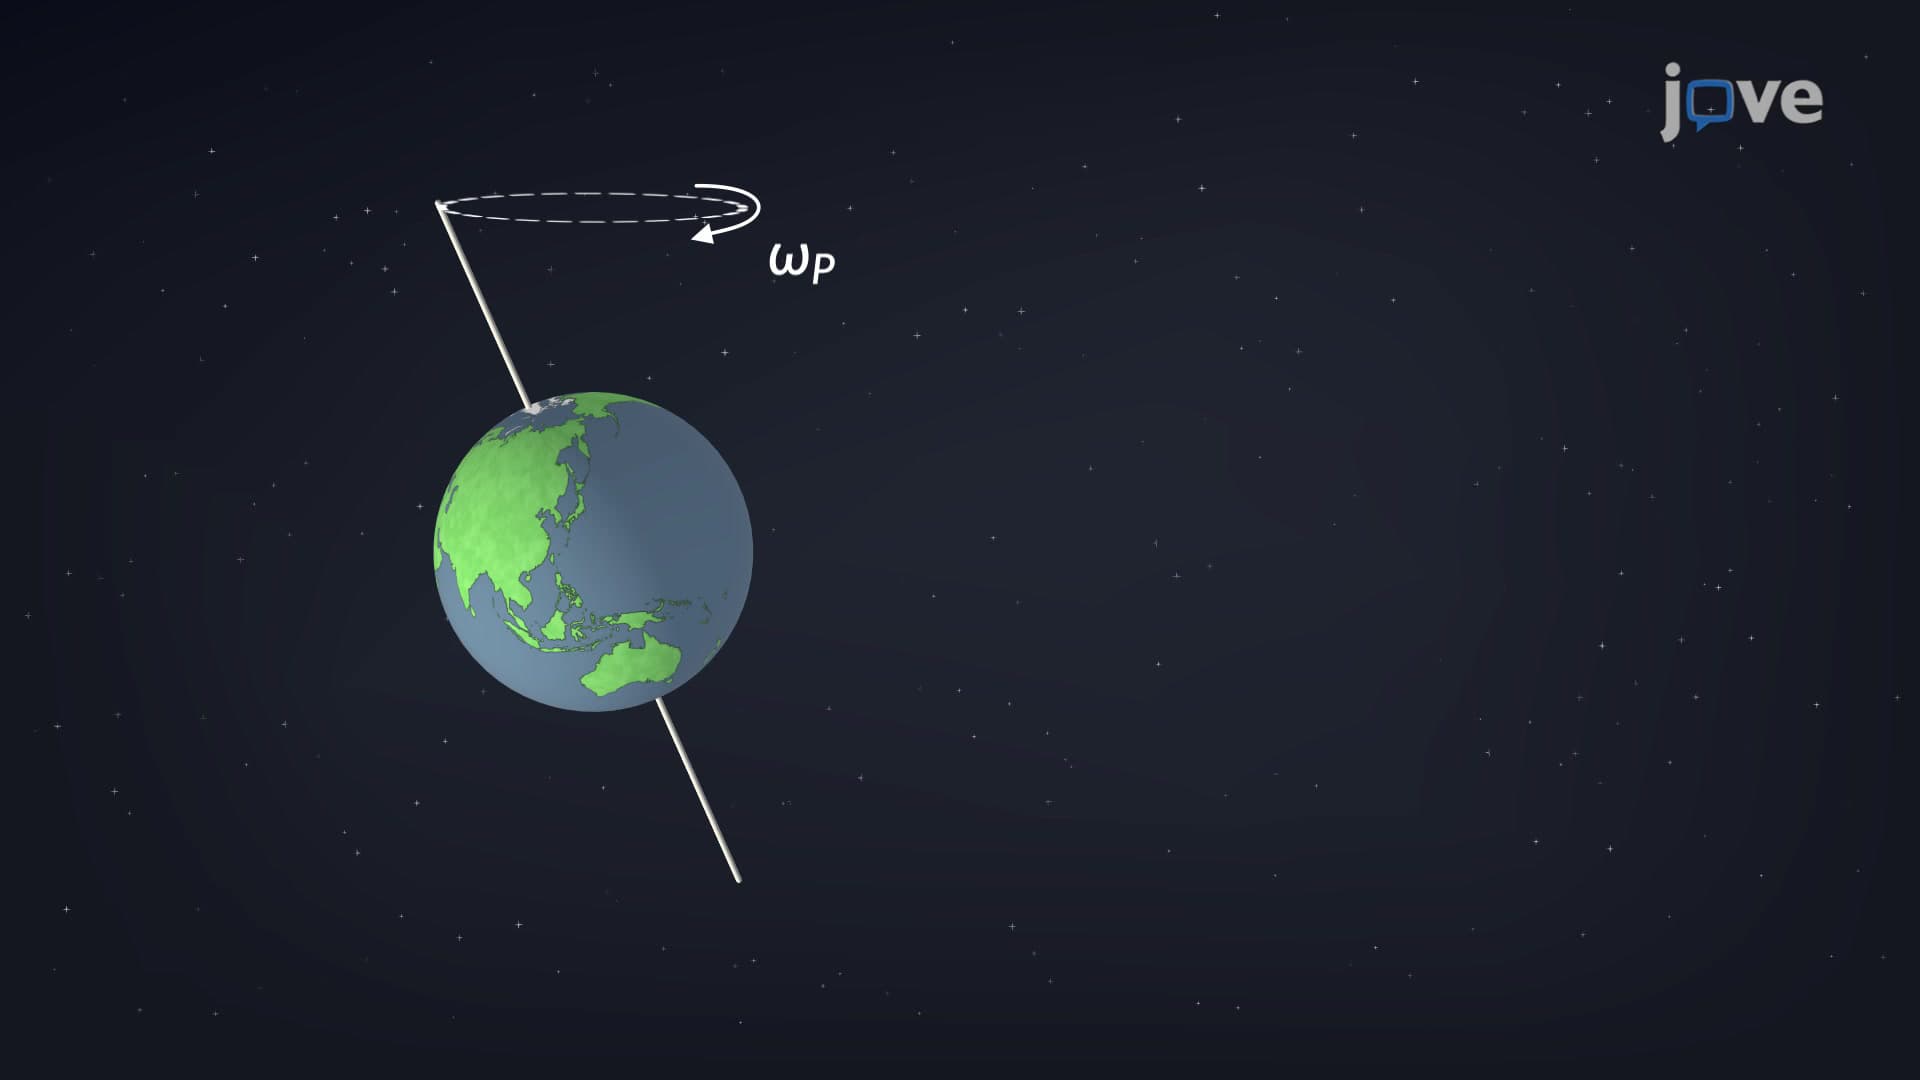
Gyroscope: Precession
 01:24
PI Controller: Design
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...