Related Experiment Video
Updated: Oct 3, 2025
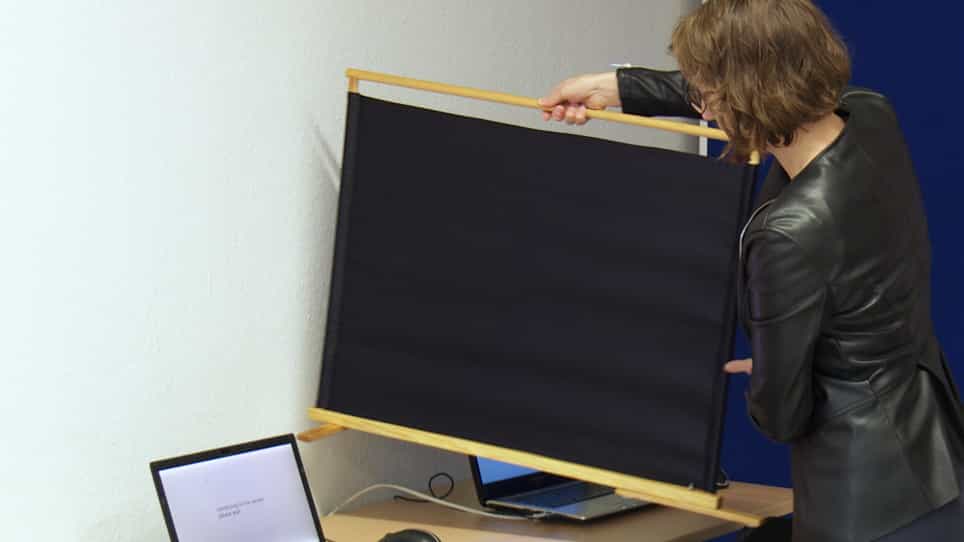
The HoneyComb Paradigm for Research on Collective Human Behavior
Published on: January 19, 2019
Balancing Collective Exploration and Exploitation in Multi-Agent and Multi-Robot Systems: A Review
Hian Lee Kwa1,2, Jabez Leong Kit1, Roland Bouffanais3
1Singapore University of Technology and Design, Singapore, Singapore.

Abstract:
Multi-agent systems and multi-robot systems have been recognized as unique solutions to complex dynamic tasks distributed in space. Their effectiveness in accomplishing these tasks rests upon the design of cooperative control strategies, which is acknowledged to be challenging and nontrivial. In particular, the effectiveness of these strategies has been shown to be related to the so-called exploration-exploitation dilemma: i.e., the existence of a distinct balance between exploitative actions and exploratory ones while the system is operating. Recent results point to the need for a dynamic exploration-exploitation balance to unlock high levels of flexibility, adaptivity, and swarm intelligence. This important point is especially apparent when dealing with fast-changing environments. Problems involving dynamic environments have been dealt with by different scientific communities using theory, simulations, as well as large-scale experiments. Such results spread across a range of disciplines can hinder one's ability to understand and manage the intricacies of the exploration-exploitation challenge. In this review, we summarize and categorize the methods used to control the level of exploration and exploitation carried out by an multi-agent systems. Lastly, we discuss the critical need for suitable metrics and benchmark problems to quantitatively assess and compare the levels of exploration and exploitation, as well as the overall performance of a system with a given cooperative control algorithm.
Related Concept Videos
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:21
Distributed Loads: Problem Solving
 01:13
Principle of Virtual Work: Problem Solving
To apply the principle of virtual work,...
 01:05
Collisions in Multiple Dimensions: Introduction
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...