Related Experiment Video
Updated: Jun 22, 2026

Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
Vision-Based Automated Control of Magnetic Microrobots
Xiaoqing Tang1, Yuke Li1, Xiaoming Liu1
1Key Laboratory of Biomimetic Robots and Systems, Ministry of Education, State Key Laboratory of Intelligent Control and Decision of Complex System, Beijing Advanced Innovation Center for Intelligent Robots and Systems, and School of Mechatronical Engineering, Beijing Institute of Technology, Beijing 100081, China.

Abstract:
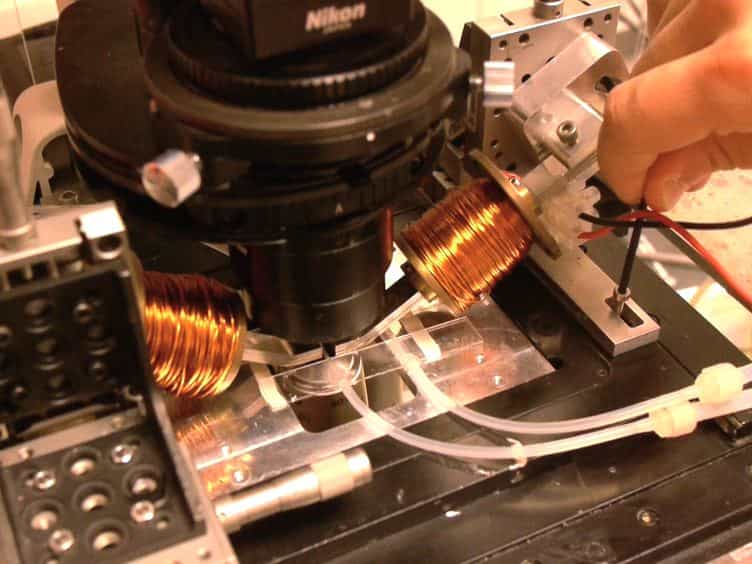
Magnetic microrobots are vital tools for targeted therapy, drug delivery, and micromanipulation on cells in the biomedical field. In this paper, we report an automated control and path planning method of magnetic microrobots based on computer vision. Spherical microrobots can be driven in the rotating magnetic field generated by electromagnetic coils. Under microscopic visual navigation, robust target tracking is achieved using PID-based closed-loop control combined with the Kalman filter, and intelligent obstacle avoidance control can be achieved based on the dynamic window algorithm (DWA) implementation strategy. To improve the performance of magnetic microrobots in trajectory tracking and movement in complicated environments, the magnetic microrobot motion in the flow field at different velocities and different distribution obstacles was investigated. The experimental results showed that the vision-based controller had an excellent performance in a complex environment and that magnetic microrobots could be controlled to move to the target position smoothly and accurately. We envision that the proposed method is a promising opportunity for targeted drug delivery in biological research.