Related Experiment Video
Updated: Oct 2, 2025

Characterization of SiN Integrated Optical Phased Arrays on a Wafer-Scale Test Station
Published on: April 1, 2020
All-Directional DOA Estimation for Ultra-Wideband Regular Tetrahedral Array Using Wrapped PDoA
Jinglin Luo1,2, Jingjing Zhang3, Haidong Yang1,2
1Foshan Nanhai Guangdong Technology University CNC Equipment Cooperative Innovation Institute, Foshan 528225, China.

Abstract:
In this paper, we proposed a Regular Tetrahedral Array (RTA) to cope with various types of sensors expected in Ultra-Wideband (UWB) localization requiring all-directional detection capability and high accuracy, such as indoor Internet-of-Things (IoT) devices at diverse locations, UAVs performing aerial navigation, collision avoidance and takeoff/landing guidance. The RTA is deployed with four synchronized Ultra-Wideband (UWB) transceivers on its vertexes and configured with arbitrary aperture. An all-directional DOA estimation algorithm using combined TDoA and wrapped PDoA was conducted. The 3D array RTA was decomposed into four planar subarrays solved as phased Uniform Circular Array (UCA) respectively. A new cost function based on geometric identical and variable neighborhood search strategy using TDoA information was proposed for ambiguity resolution. The results of simulation and numerical experiments demonstrated excellent performance of the proposed RTA and corresponding algorithm.
More Related Videos
 07:14
Tracking Infiltration Front Depth Using Time-lapse Multi-offset Gathers Collected with Array Antenna Ground Penetrating Radar
Published on: May 1, 2018
 08:08
Evaluating Targeting Accuracy in the Focal Plane for an Ultrasound-guided High-intensity Focused Ultrasound Phased-array System
Published on: March 6, 2019
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:13
Angle of Twist: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:13
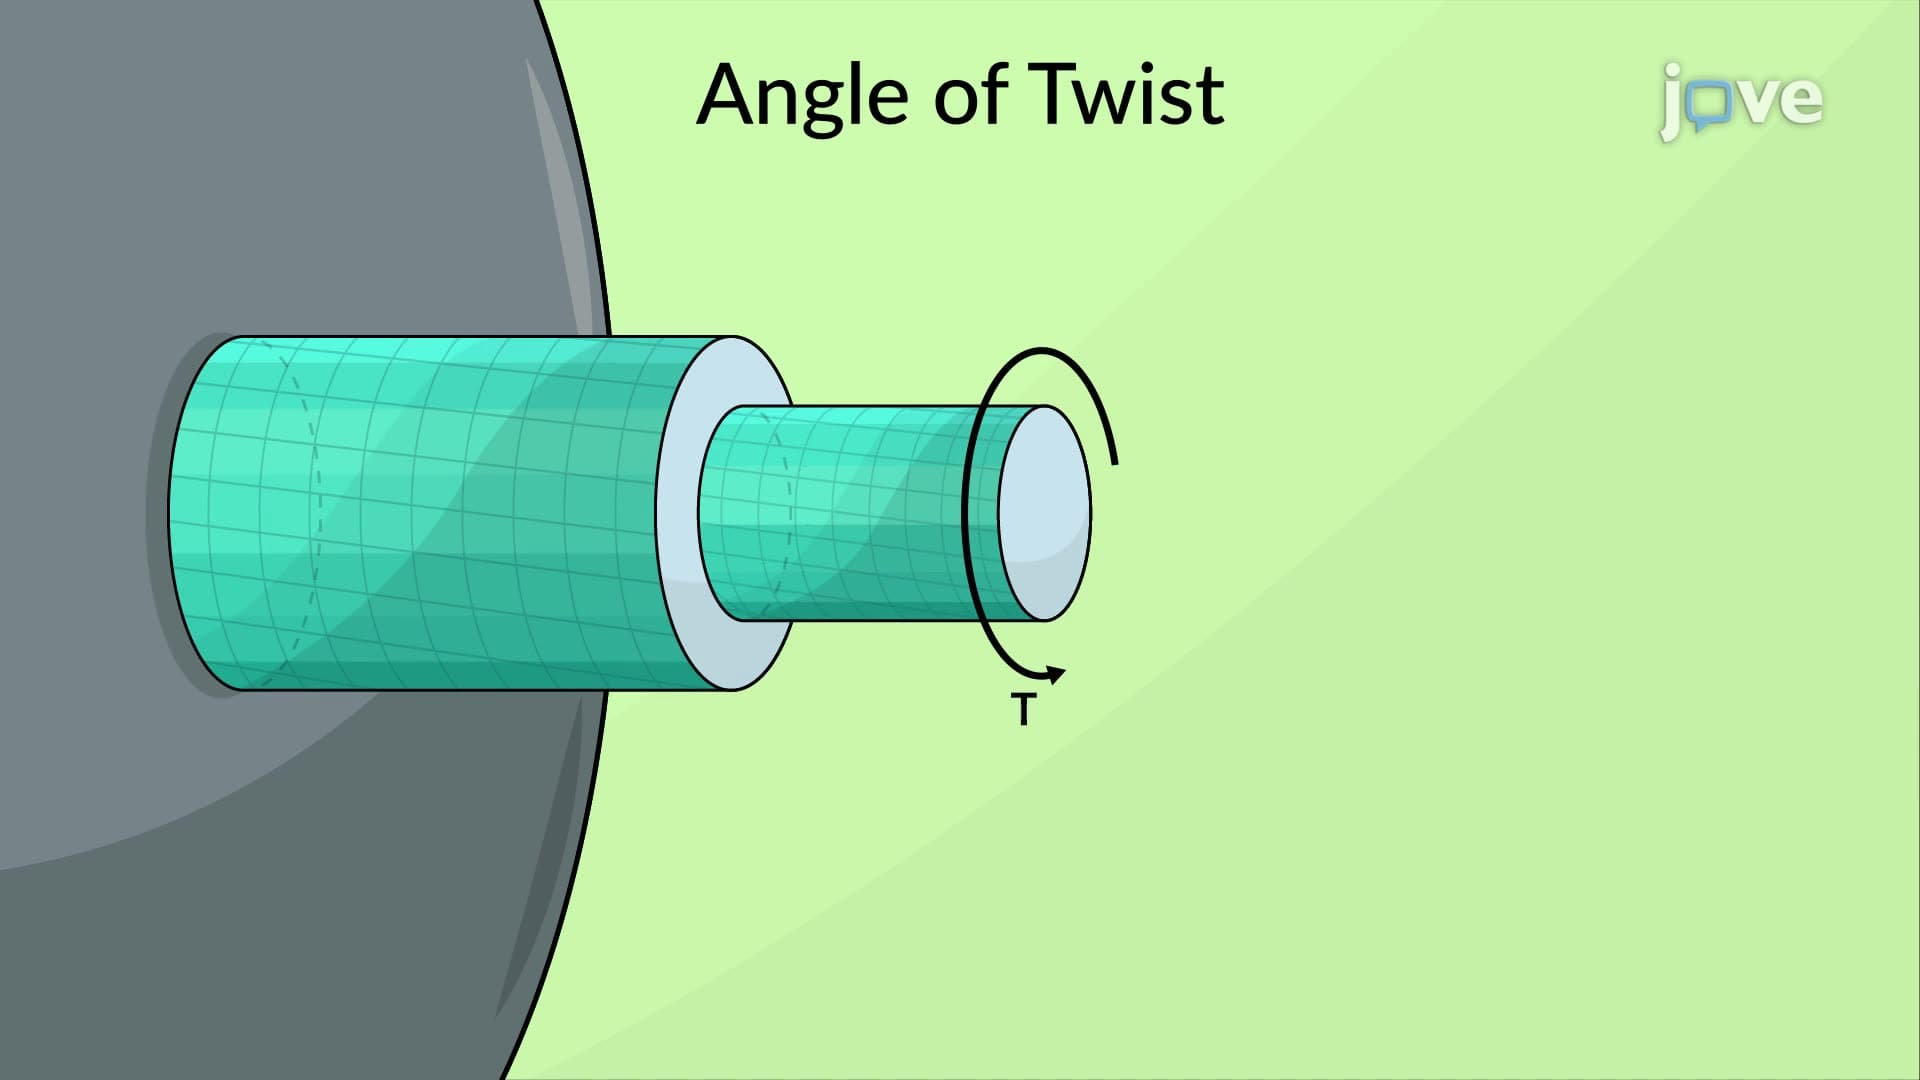
Angle of Twist - Elastic Range
 01:15
Unsymmetric Bending - Angle of Neutral Axis
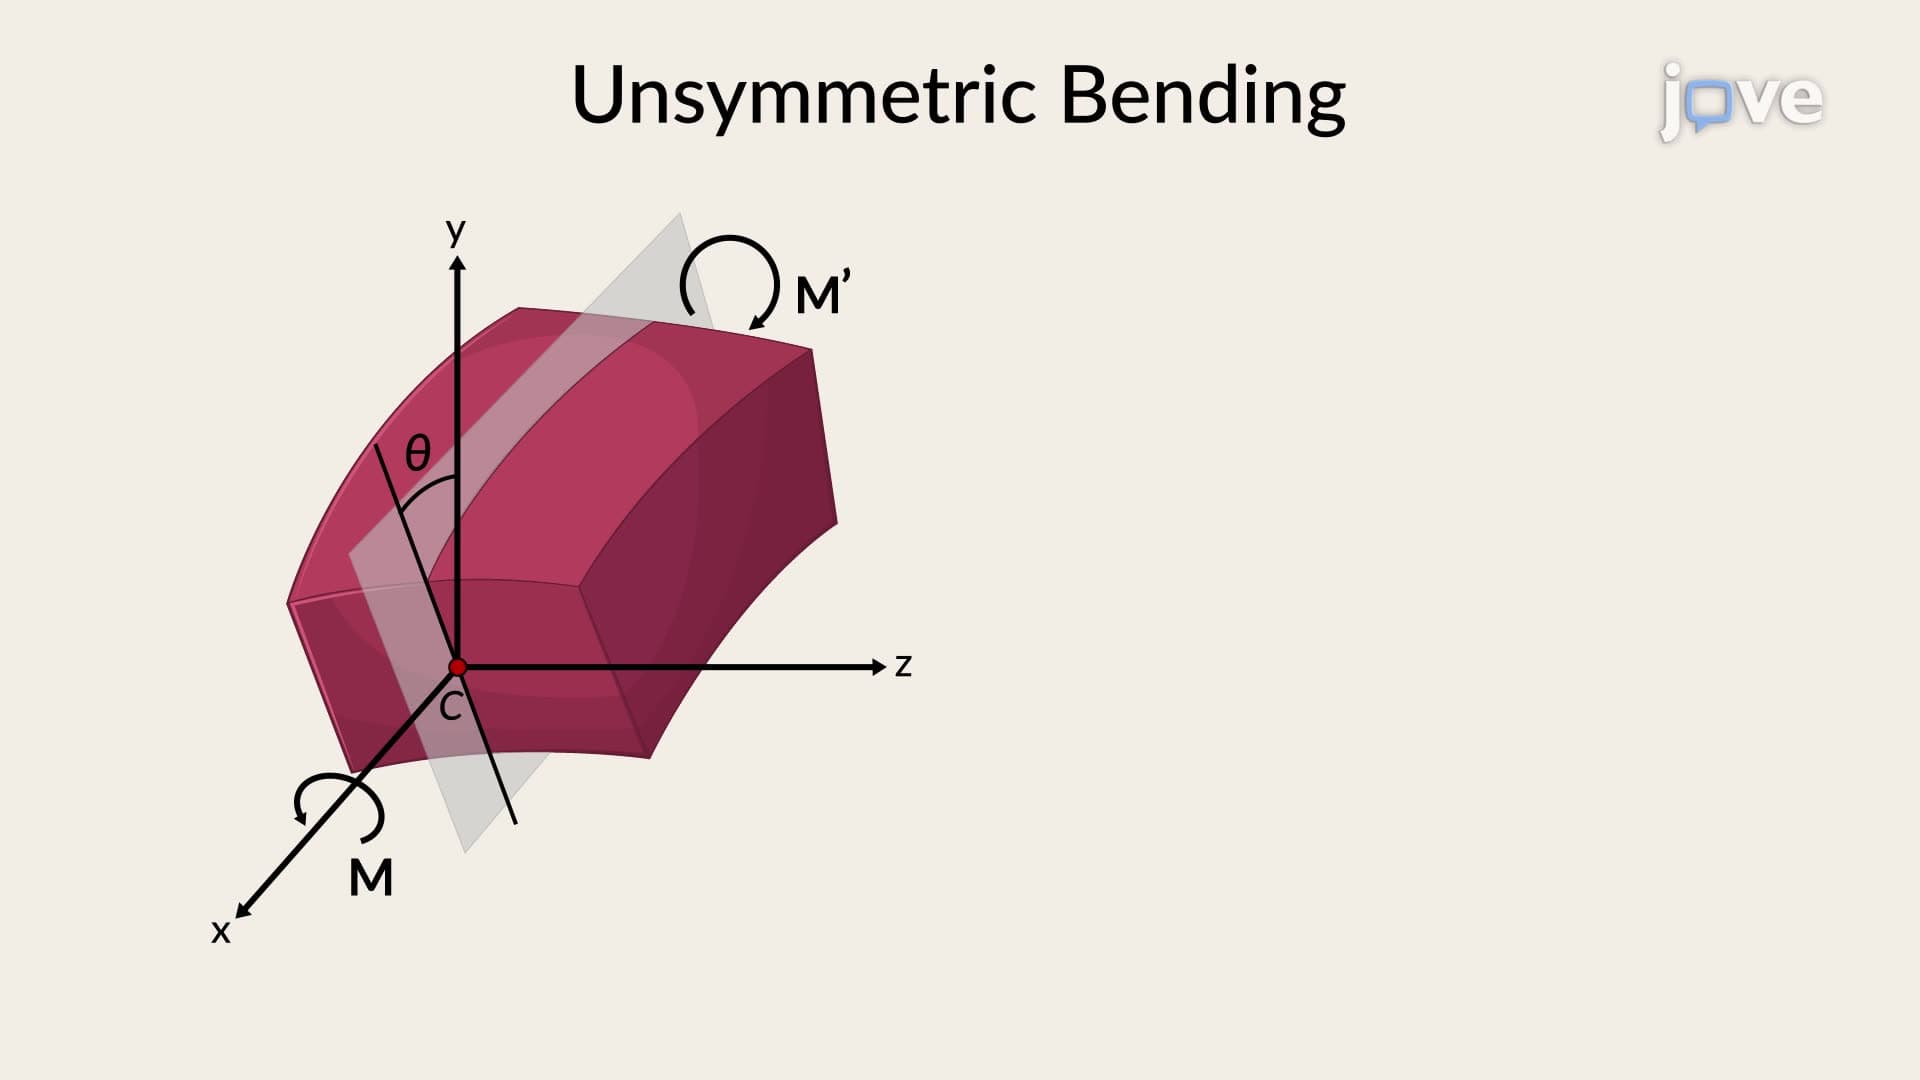
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal...
 01:22
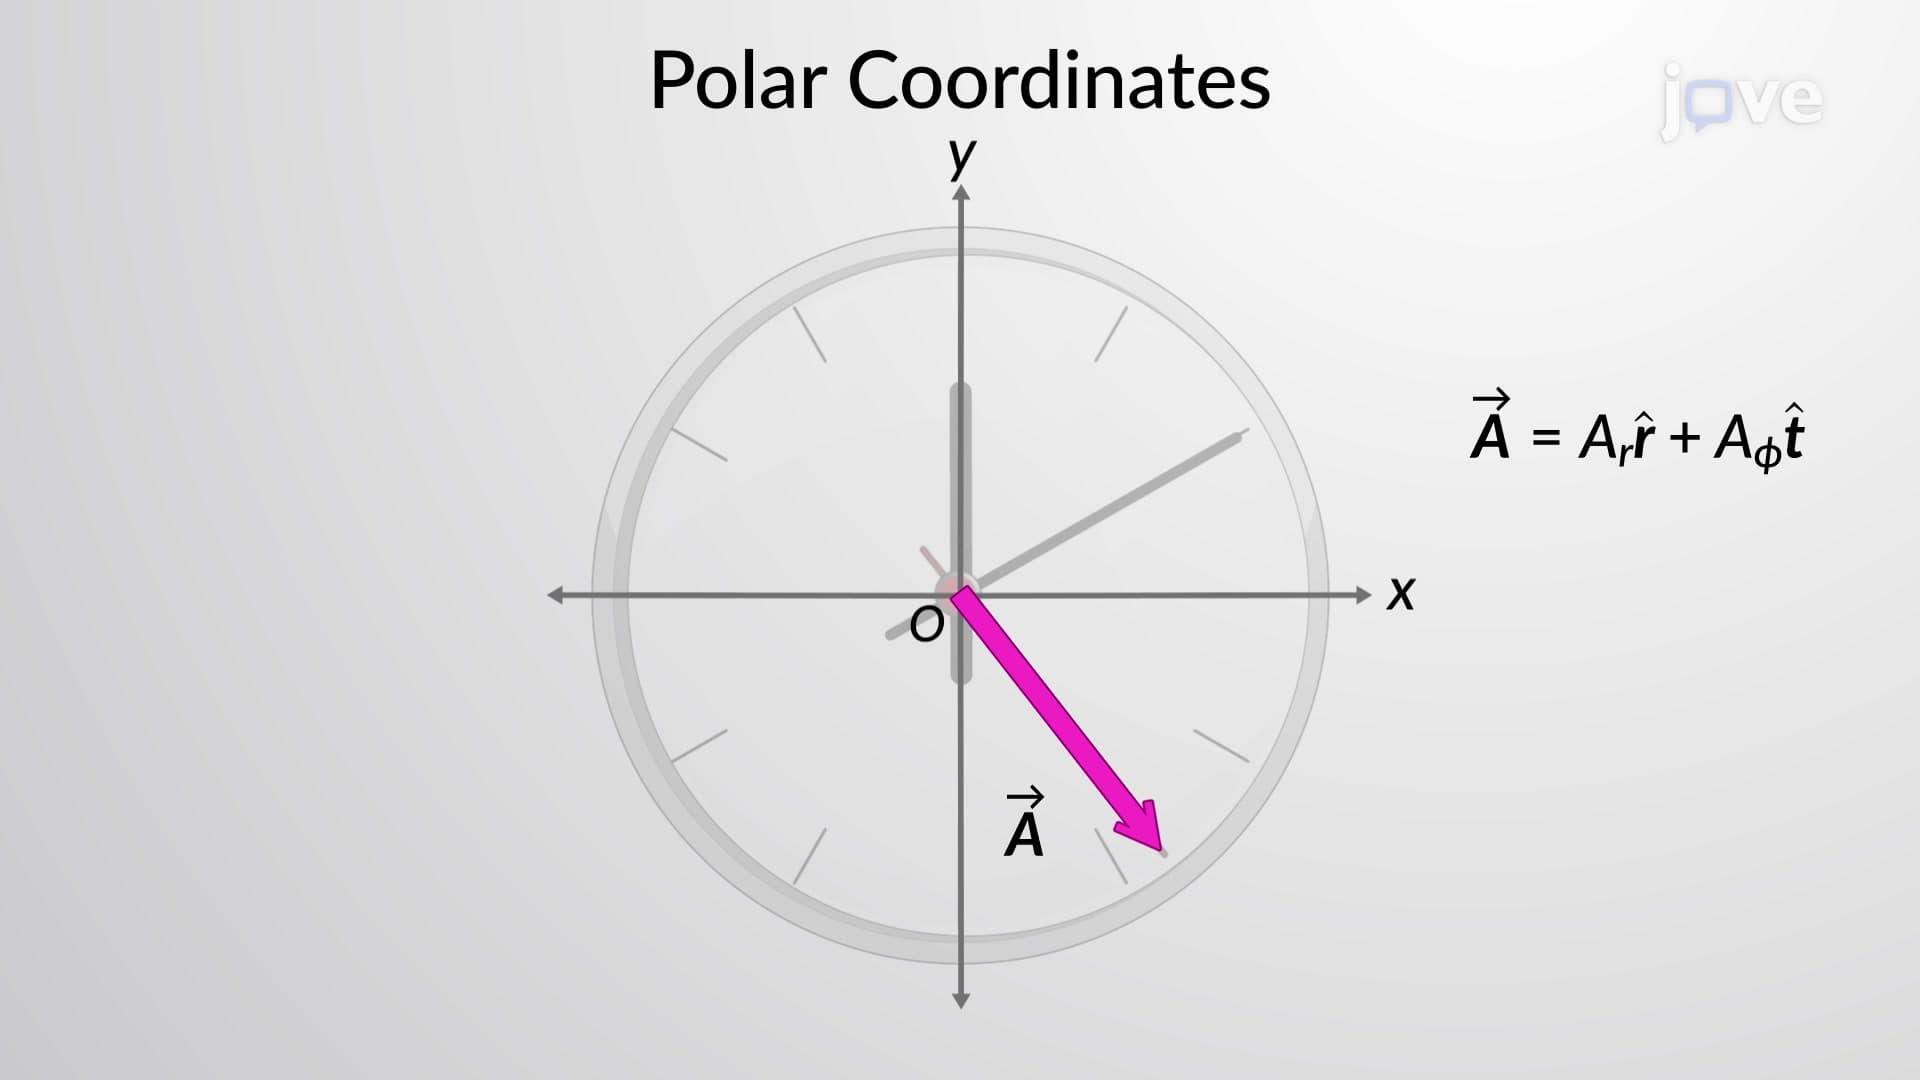
Polar and Cylindrical Coordinates