Related Experiment Video
Updated: Sep 30, 2025

Preparation and 3D Tracking of Catalytic Swimming Devices
Published on: July 1, 2016
The -Link Swimmer in Three Dimensions: Controllability and Optimality Results
Roberto Marchello1, Marco Morandotti1, Henry Shum2
1Dipartimento di Scienze Matematiche "G. L. Lagrange", Politecnico di Torino, Corso Duca degli Abruzzi, 24, 10129 Torino, Italy.

Abstract:
The controllability of a fully three-dimensional -link swimmer is studied. After deriving the equations of motion in a low Reynolds number fluid by means of Resistive Force Theory, the controllability of the minimal 2-link swimmer is tackled using techniques from Geometric Control Theory. The shape of the 2-link swimmer is described by two angle parameters. It is shown that the associated vector fields that govern the dynamics generate, via taking their Lie brackets, all eight linearly independent directions in the combined configuration and shape space, leading to controllability; the swimmer can move from any starting configuration and shape to any target configuration and shape by operating on the two shape variables. The result is subsequently extended to the -link swimmer. Finally, the minimal time optimal control problem and the minimization of the power expended are addressed and a qualitative description of the optimal strategies is provided.
Related Concept Videos
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:19
Root-Locus Method
This system can be represented by a block...
 01:06
Divergence and Stokes' Theorems
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:14
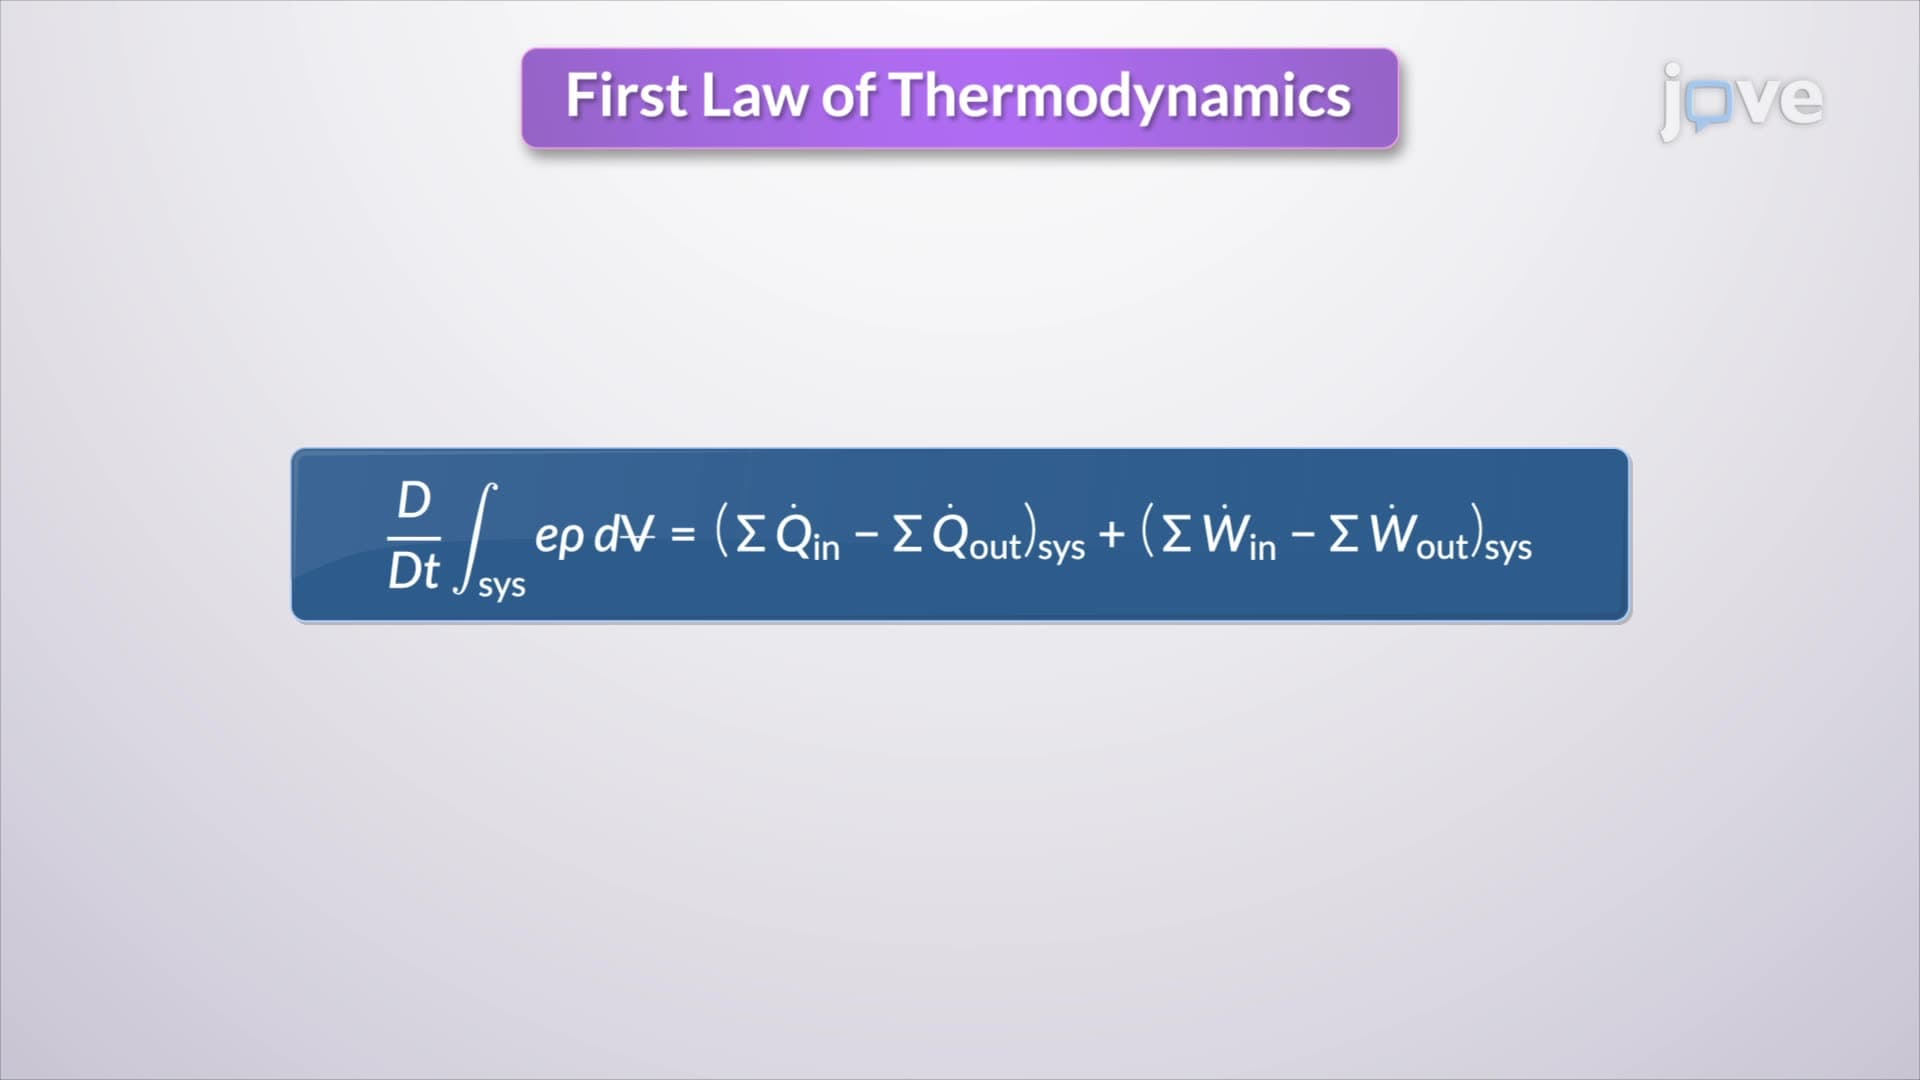
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:18
Uniform Depth Channel Flow: Problem Solving