Learning Skill Characteristics From Manipulations
Related Experiment Video
Updated: Sep 29, 2025
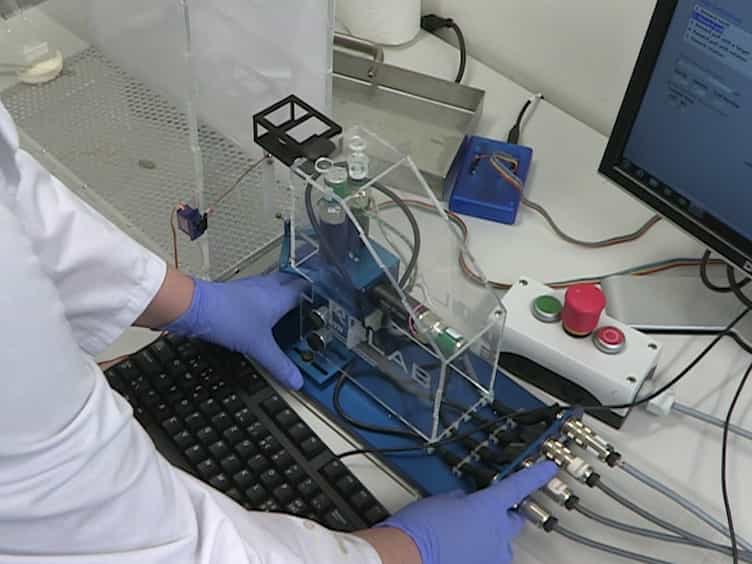
Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017

Abstract:
Percutaneous coronary intervention (PCI) has increasingly become the main treatment for coronary artery disease. The procedure requires high experienced skills and dexterous manipulations. However, there are few techniques to model PCI skill so far. In this study, a learning framework with local and ensemble learning is proposed to learn skill characteristics of different skill-level subjects from their PCI manipulations. Ten interventional cardiologists (four experts and six novices) were recruited to deliver a medical guidewire to two target arteries on a porcine model for in vivo studies. Simultaneously, translation and twist manipulations of thumb, forefinger, and wrist are acquired with electromagnetic (EM) and fiber-optic bend (FOB) sensors, respectively. These behavior data are then processed with wavelet packet decomposition (WPD) under 1-10 levels for feature extraction. The feature vectors are further fed into three candidate individual classifiers in the local learning layer. Furthermore, the local learning results from different manipulation behaviors are fused in the ensemble learning layer with three rule-based ensemble learning algorithms. In subject-dependent skill characteristics learning, the ensemble learning can achieve 100% accuracy, significantly outperforming the best local result (90%). Furthermore, ensemble learning can also maintain 73% accuracy in subject-independent schemes. These promising results demonstrate the great potential of the proposed method to facilitate skill learning in surgical robotics and skill assessment in clinical practice.
Related Concept Videos
 01:12
Observational Learning
 01:22
Purposive Learning
 01:18
Introduction to Learning
In contrast to learned behaviors, unlearned behaviors such as crying, sexual...
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...
 01:14
Steps in the Modeling Process
Attention is the first necessary component for observational learning. It involves focusing on what the model is doing and saying. For example, if you decide to take a drawing class to enhance your skills, you need to pay close attention to the instructor's words and hand movements. The characteristics of the model significantly...
 01:26
Higher Mental Functions of Brain: Learning and Memory