Related Experiment Video
Updated: Sep 24, 2025

Operant Learning of Drosophila at the Torque Meter
Published on: June 16, 2008
Neural-Fly enables rapid learning for agile flight in strong winds
Michael O'Connell1, Guanya Shi1, Xichen Shi1
1Division of Engineering and Applied Science, California Institute of Technology, Pasadena, CA, USA.

Abstract:
Executing safe and precise flight maneuvers in dynamic high-speed winds is important for the ongoing commoditization of uninhabited aerial vehicles (UAVs). However, because the relationship between various wind conditions and its effect on aircraft maneuverability is not well understood, it is challenging to design effective robot controllers using traditional control design methods. We present Neural-Fly, a learning-based approach that allows rapid online adaptation by incorporating pretrained representations through deep learning. Neural-Fly builds on two key observations that aerodynamics in different wind conditions share a common representation and that the wind-specific part lies in a low-dimensional space. To that end, Neural-Fly uses a proposed learning algorithm, domain adversarially invariant meta-learning (DAIML), to learn the shared representation, only using 12 minutes of flight data. With the learned representation as a basis, Neural-Fly then uses a composite adaptation law to update a set of linear coefficients for mixing the basis elements. When evaluated under challenging wind conditions generated with the Caltech Real Weather Wind Tunnel, with wind speeds up to 43.6 kilometers/hour (12.1 meters/second), Neural-Fly achieves precise flight control with substantially smaller tracking error than stateof-the-art nonlinear and adaptive controllers. In addition to strong empirical performance, the exponential stability of Neural-Fly results in robustness guarantees. Last, our control design extrapolates to unseen wind conditions, is shown to be effective for outdoor flights with only onboard sensors, and can transfer across drones with minimal performance degradation.

Related Concept Videos
 01:18
Drag Force and Terminal Speed
 01:19
Drift Velocity
 01:18
Neural Control of Respiration
Respiratory Centers in the Brainstem
Two primary areas comprise the respiratory center: the medullary respiratory center in the medulla oblongata and the pontine respiratory group in the pons. The...
 01:37
Neural Regulation
 01:24
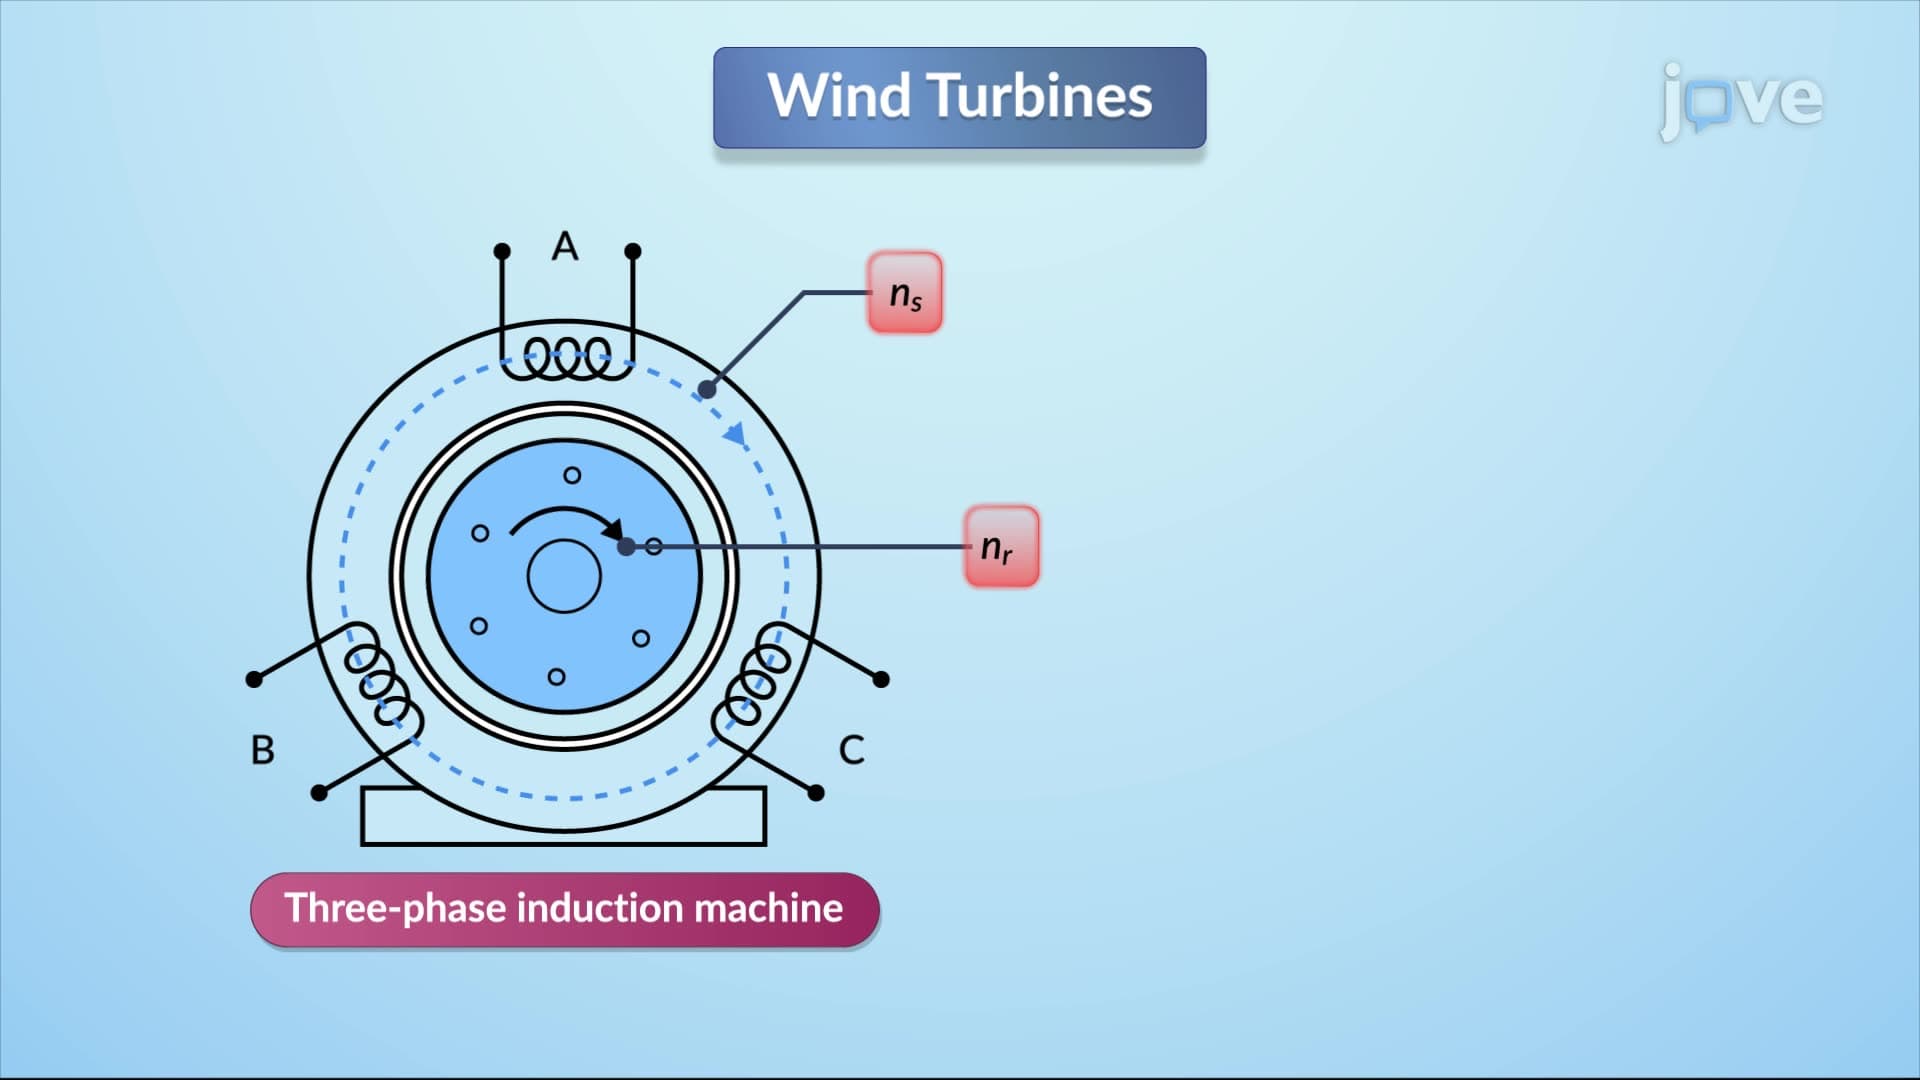
Wind Turbine Machine Models
Induction machines interact through the rotating magnetic field generated by the stator and the rotor. The key parameter is slip, which is the difference between synchronous speed and rotor speed relative to synchronous speed. Slip is...