Related Experiment Video
Updated: Sep 18, 2026


Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
AthenaZero: A low-inertia, bimanual robot for dynamic manipulation
Andrew S Morgan1, Gregory Xie1, Capprin Bass1
1RAI Institute, Cambridge, MA 02142, USA.

Abstract:
AthenaZero is a bimanual manipulator designed to minimize inertia without compromising control authority. By using quasidirect drive actuation and transmission remotization techniques, the system achieves an effective end-point mass comparable to that of a human, about an order of magnitude less than that of conventional robot manipulators. This characteristic, combined with its inherent torque transparency, makes AthenaZero exceptionally well suited for dynamic manipulation. We describe the methodology that led to this design and demonstrate the robot's capabilities on three baseball-inspired tasks, throwing, catching, and batting, which showcase complex interactions on human-comparable timescales where milliseconds matter. AthenaZero was capable of throwing at speeds in excess of 30 meters per second, with catching and batting at speeds in excess of 14 meters per second over a short 7.3-meter distance. Batting practice and a game of catch were subsequently performed in robot-to-robot and human-to-robot variations, showcasing the efficacy and adaptability of our system in tasks that require high acceleration.
Related Concept Videos
 01:09
Angular Momentum and Principle Axes of Inertia
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:11
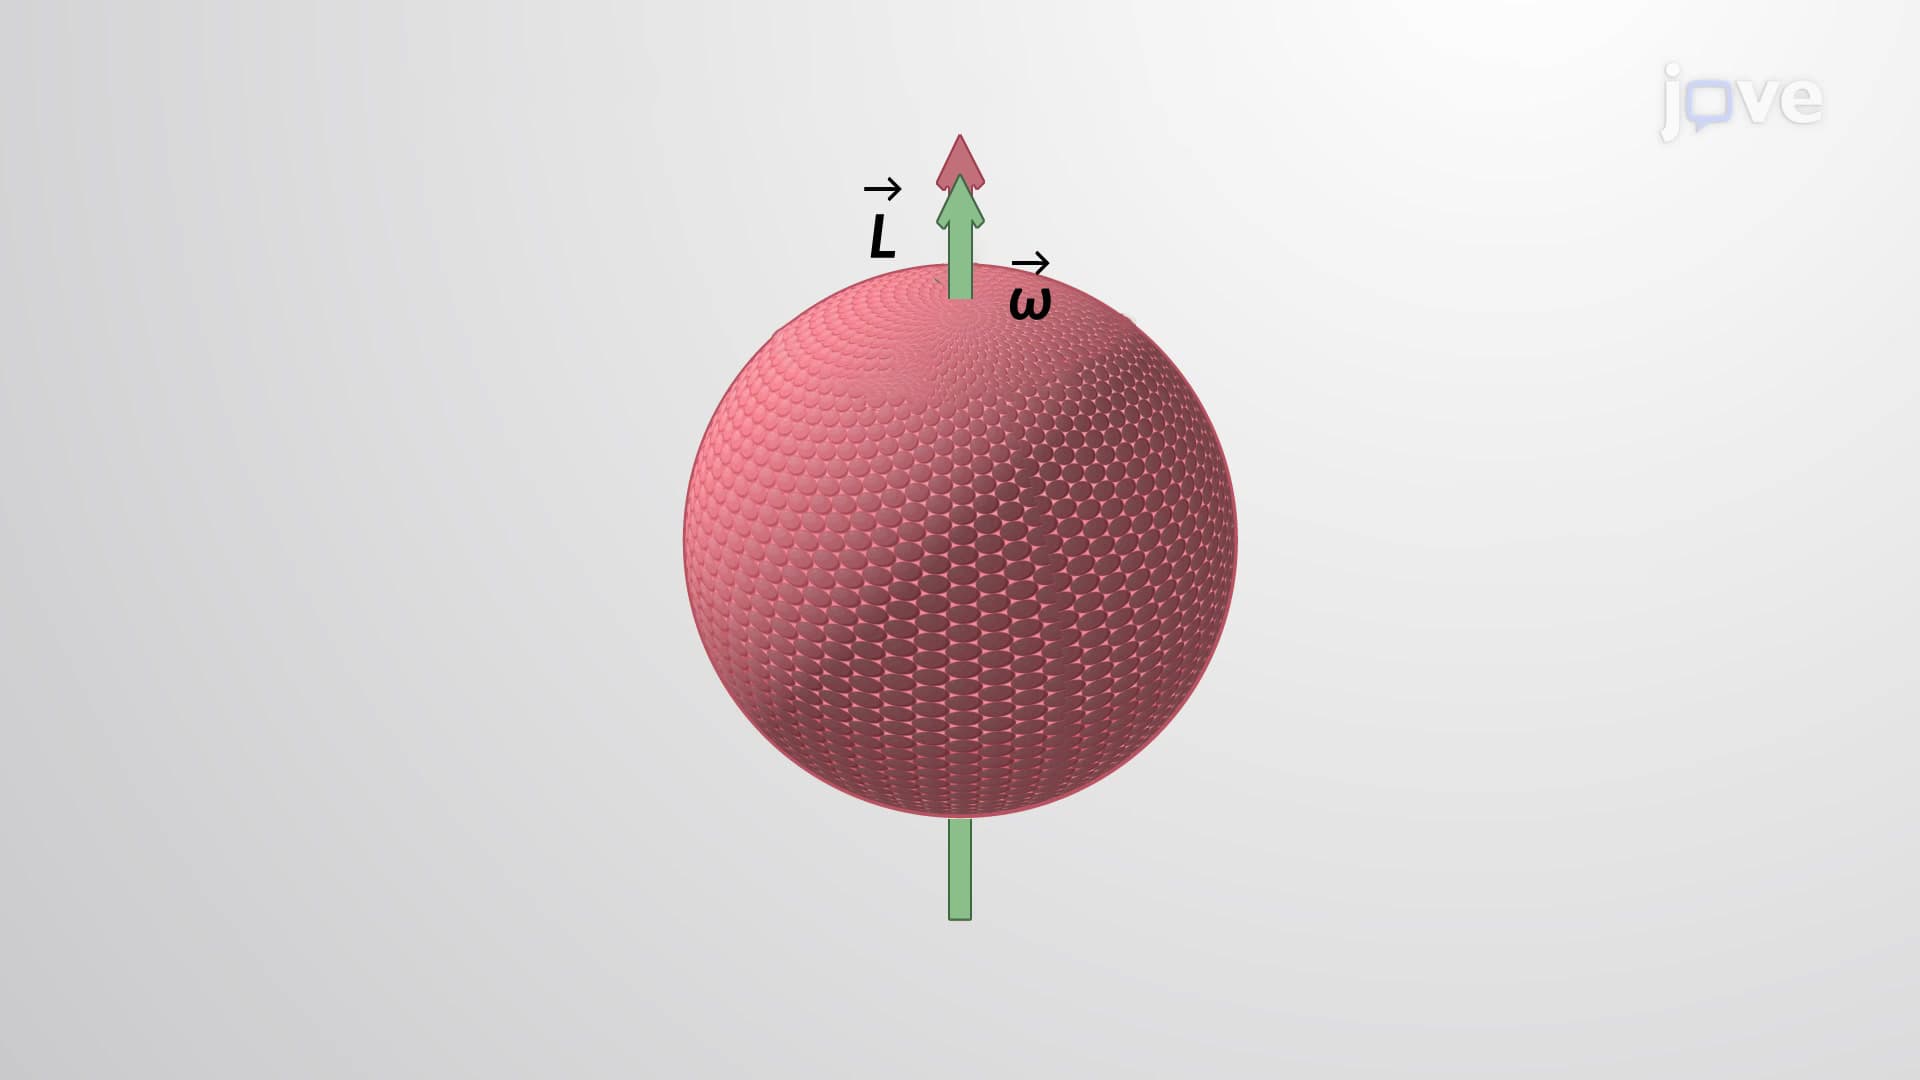
Angular Momentum: Rigid Body
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...