Related Experiment Video
Updated: Aug 14, 2026

Enhancing Upper Limb Function and Motor Skills Post-Stroke Through an Upper Limb Rehabilitation Robot
Published on: September 6, 2024
ZEST: Zero-shot embodied skill transfer for athletic robot control
Jean Pierre Sleiman1, He Li1, Alphonsus Adu-Bredu2
1RAI Institute, Cambridge, MA, USA.

Abstract:
Achieving robust, humanlike whole-body control on humanoid robots for agile, contact-rich behaviors remains a central challenge, demanding heavy per-skill engineering and a brittle process of tuning controllers. We introduce ZEST (zero-shot embodied skill transfer), a streamlined motion-imitation framework that trains policies via reinforcement learning from diverse sources-high-fidelity motion capture, noisy monocular video, and non-physics-constrained animation-and deploys them to hardware zero-shot. ZEST generalizes across behaviors and platforms without relying on contact labels, reference or observation windows, state estimators, or extensive reward shaping. Its training pipeline combines adaptive sampling, which focuses training on difficult motion segments, and an automatic curriculum using a model-based assistive wrench, together enabling dynamic, long-horizon maneuvers. We further provide a procedure for selecting joint-level gains from approximate analytical armature values for closed-chain actuators, along with a refined model of actuators. Trained entirely in simulation with moderate domain randomization, ZEST demonstrated broad generality. On Boston Dynamics' Atlas humanoid, ZEST learned dynamic, multicontact skills (army crawl and breakdancing) from motion capture. It transferred expressive dance and scene-interaction skills, such as box climbing, directly from videos to Atlas and the Unitree G1. Furthermore, it extended across morphologies to the Spot quadruped, enabling acrobatics, such as a continuous backflip, through animation. Together, these results demonstrate robust zero-shot deployment across heterogeneous data sources and embodiments, establishing ZEST as a scalable interface between biological movements and their robotic counterparts.
Related Concept Videos
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
 01:15
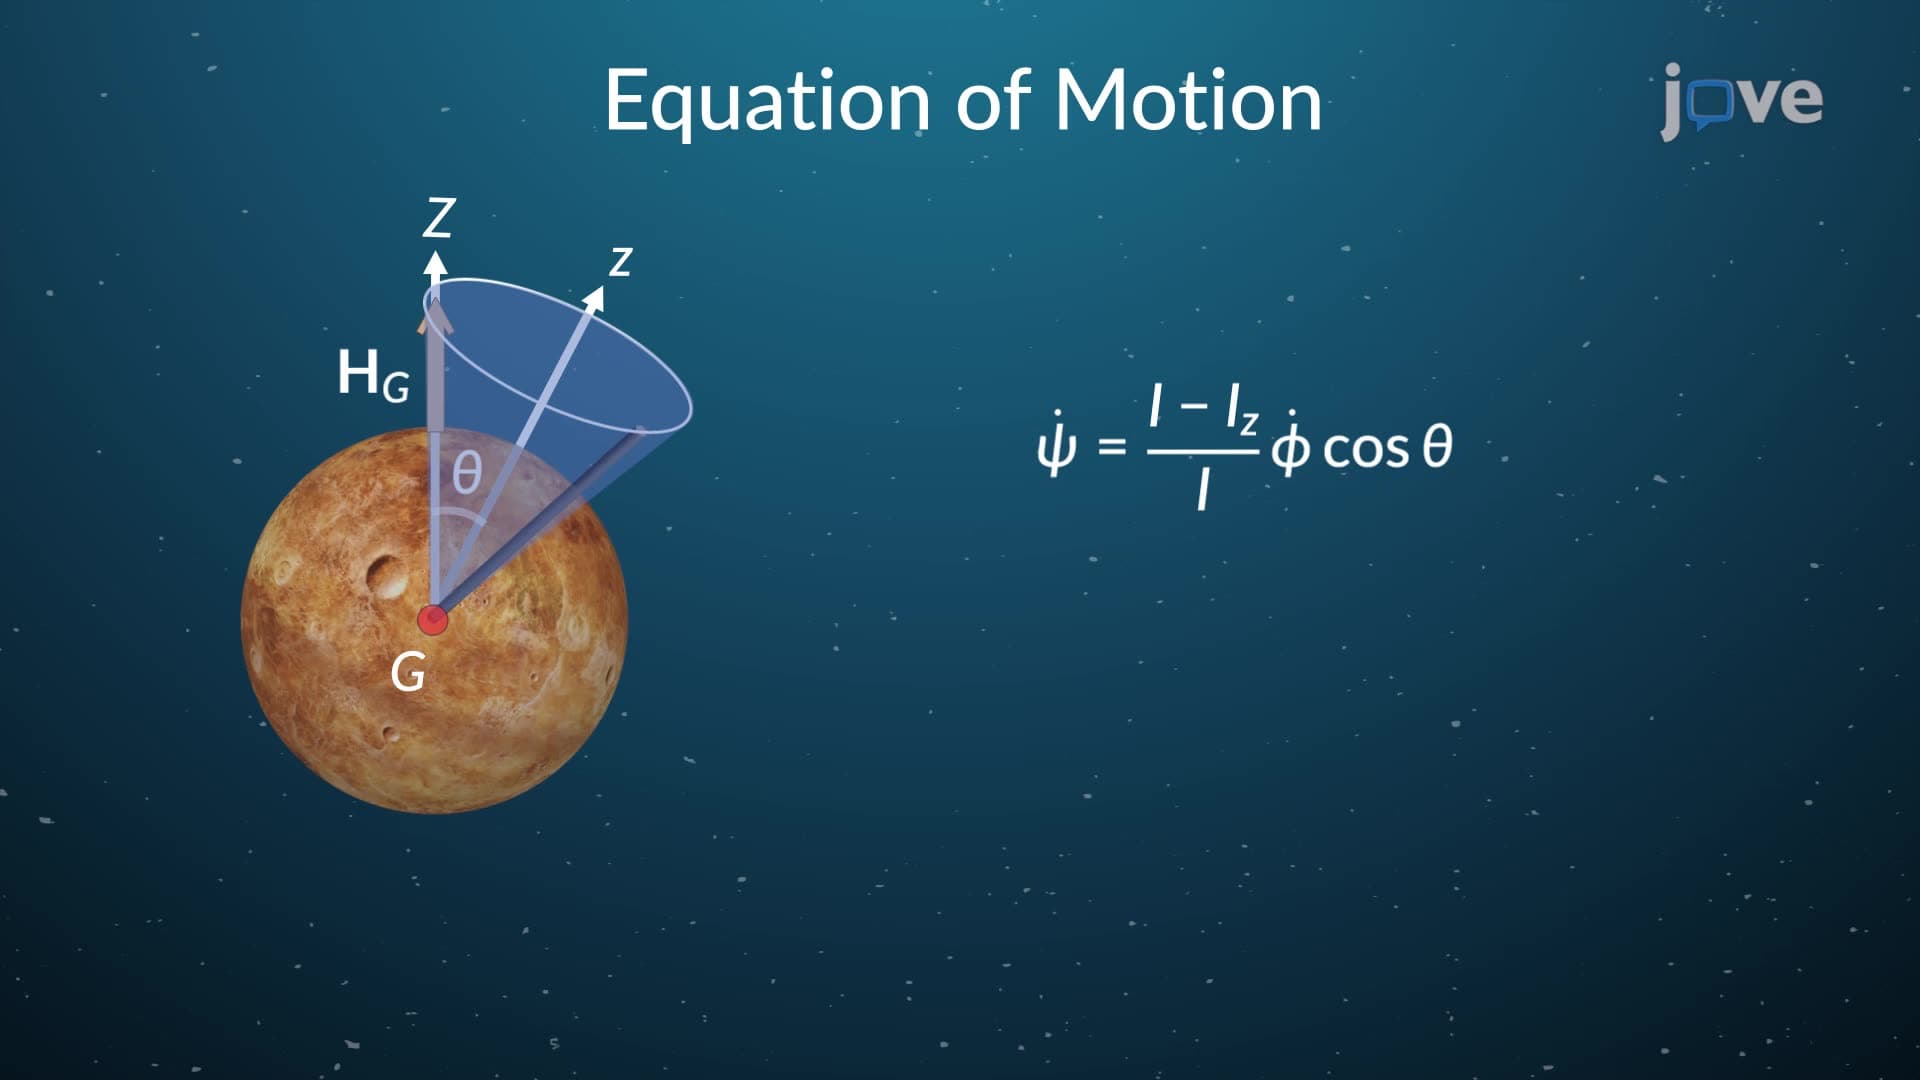
Torque Free Motion
 01:30
Zero-Force Member
One critical concept in truss design is the idea of zero-force members. It refers to a truss member that experiences no stress under loading conditions.
 01:13
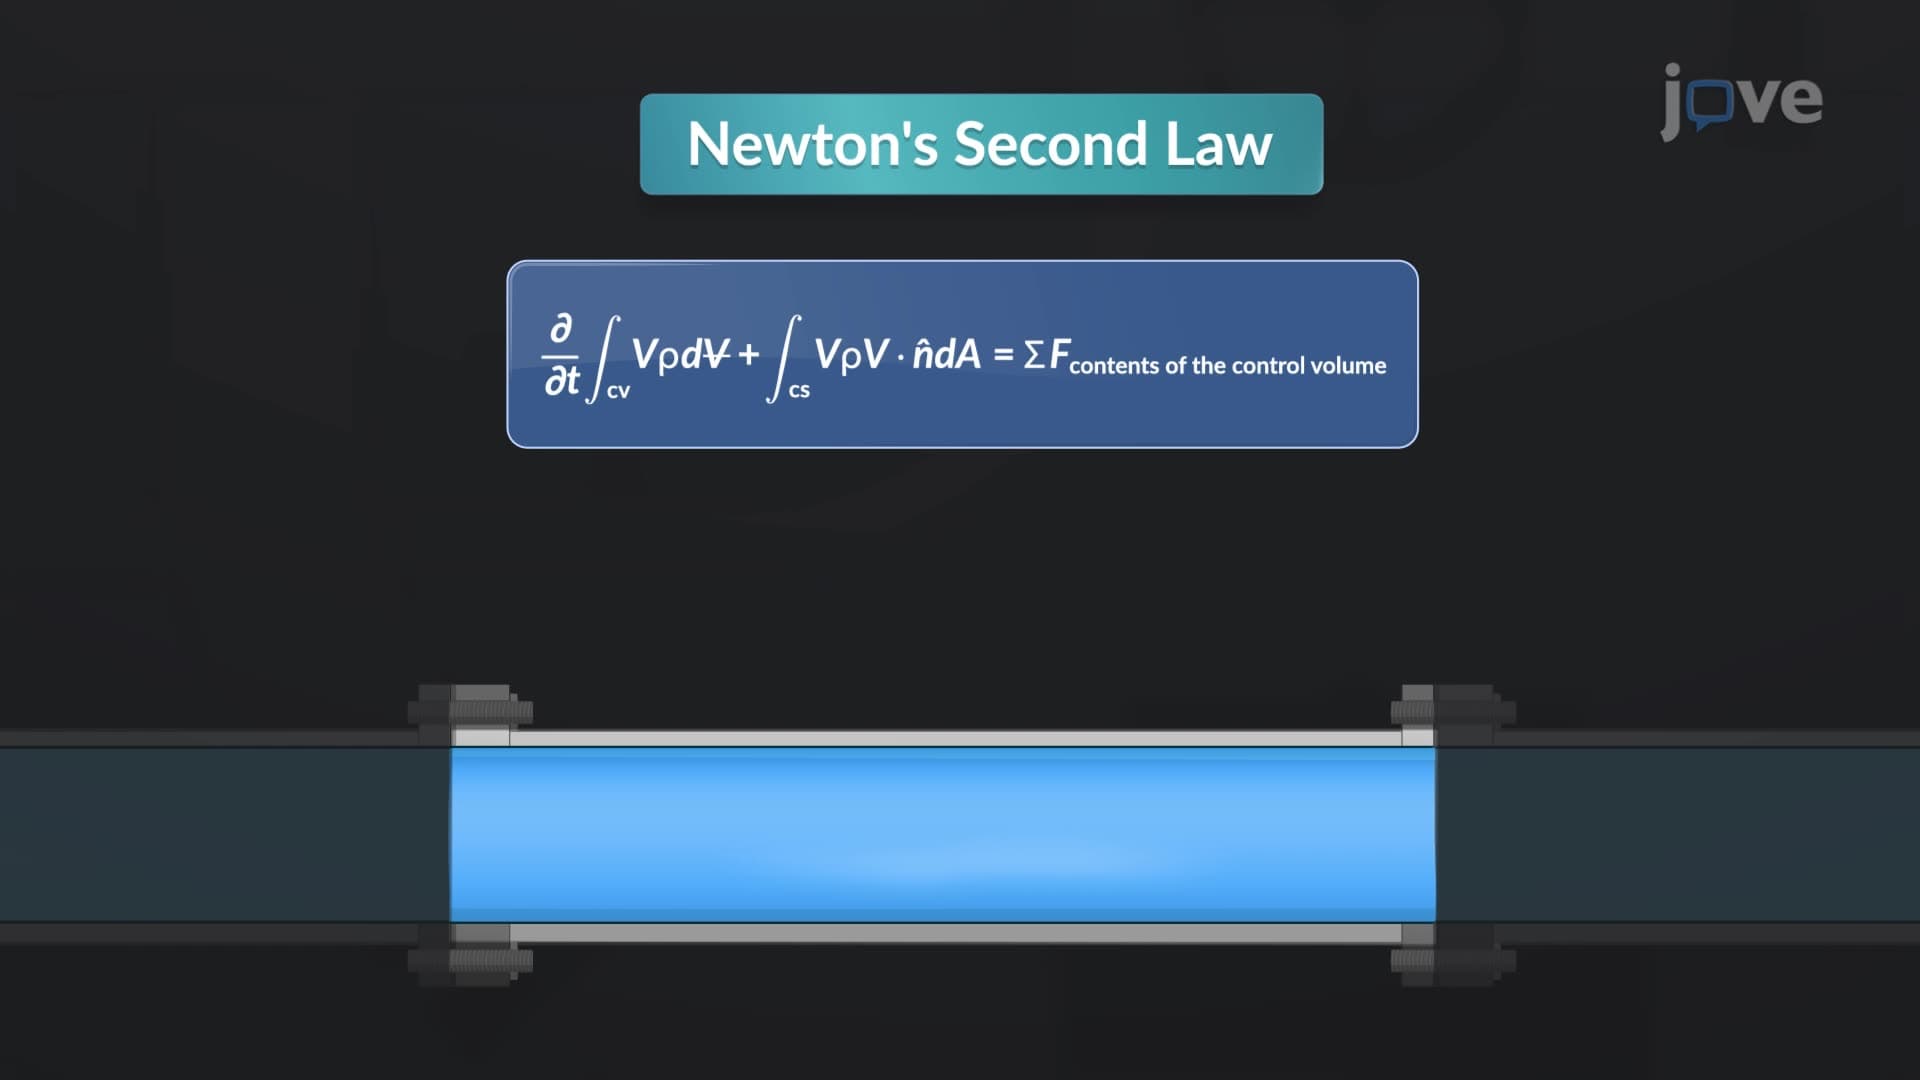
Linear Momentum in Control Volume
 00:23
Kinetic Energy