Related Experiment Video
Updated: Sep 24, 2025

Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
Analysis and control of a running spring-mass model with a trunk based on virtual pendulum concept
O K Karagoz1,2, G Secer3,4, M M Ankarali1,2
1Electrical and Electronics Engineering Department, Middle East Technical University, Ankara, Turkey.

Abstract:
The spring-loaded inverted pendulum model has been one of the most studied conceptual models in the locomotion community. Even though it can adequately explain the center of mass trajectories of numerous legged animals, it remains insufficient in template-based control of complex robot platforms, being unable to capture additional dynamic characteristics of locomotion exhibited in additional degrees of freedom such as trunk pitch oscillations. In fact, analysis of trunk behavior during locomotion has been one of the motivations behind studying the virtual pivot point (VPP) concept, with biological inspiration and basis for both natural and synthetic systems with non-negligible trunk dynamics. This study first presents a comprehensive analysis of the VPP concept for planar running behaviors, followed by a systematic study of the existence and characteristics of periodic solutions. In particular, we investigate how periodic solutions depend on model control parameters and compare them based on stability and energetic cost. We then develop a feedback controller that can stabilize system dynamics around its periodic solutions and evaluate performance as compared to a previously introduced controller from the literature. We demonstrate the effectiveness of both controllers and find that the proposed control scheme creates larger basins of attraction with minor degradation in convergence speed. In conclusion, this study shows that the VPP concept, in conjunction with the proposed controller, could be beneficial in designing and controlling legged robots capable of running with non-trivial upper body dynamics. Our systematic analysis of periodic solutions arising from the use of the VPP concept is also an important step towards a more formal basis for comparisons of the VPP concept with bio-locomotion.

Related Concept Videos
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum...
 01:09
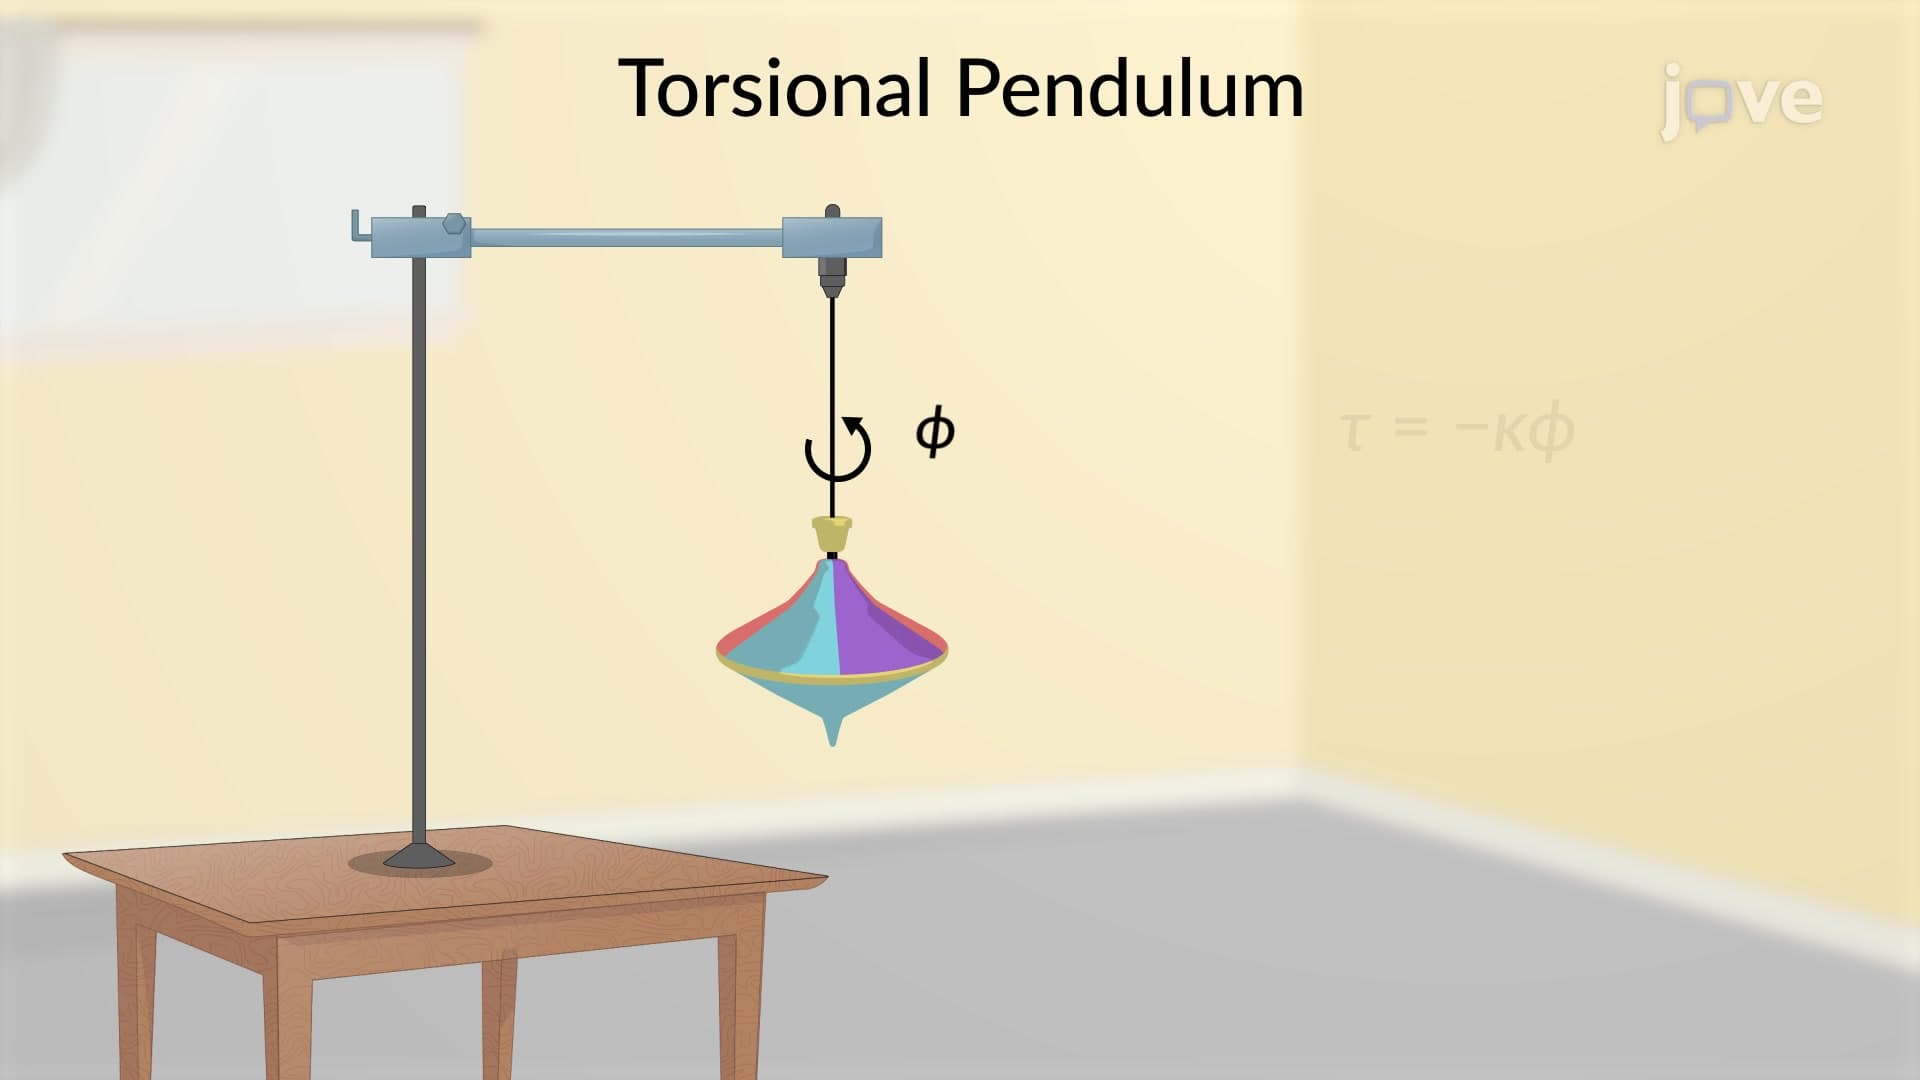
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:17
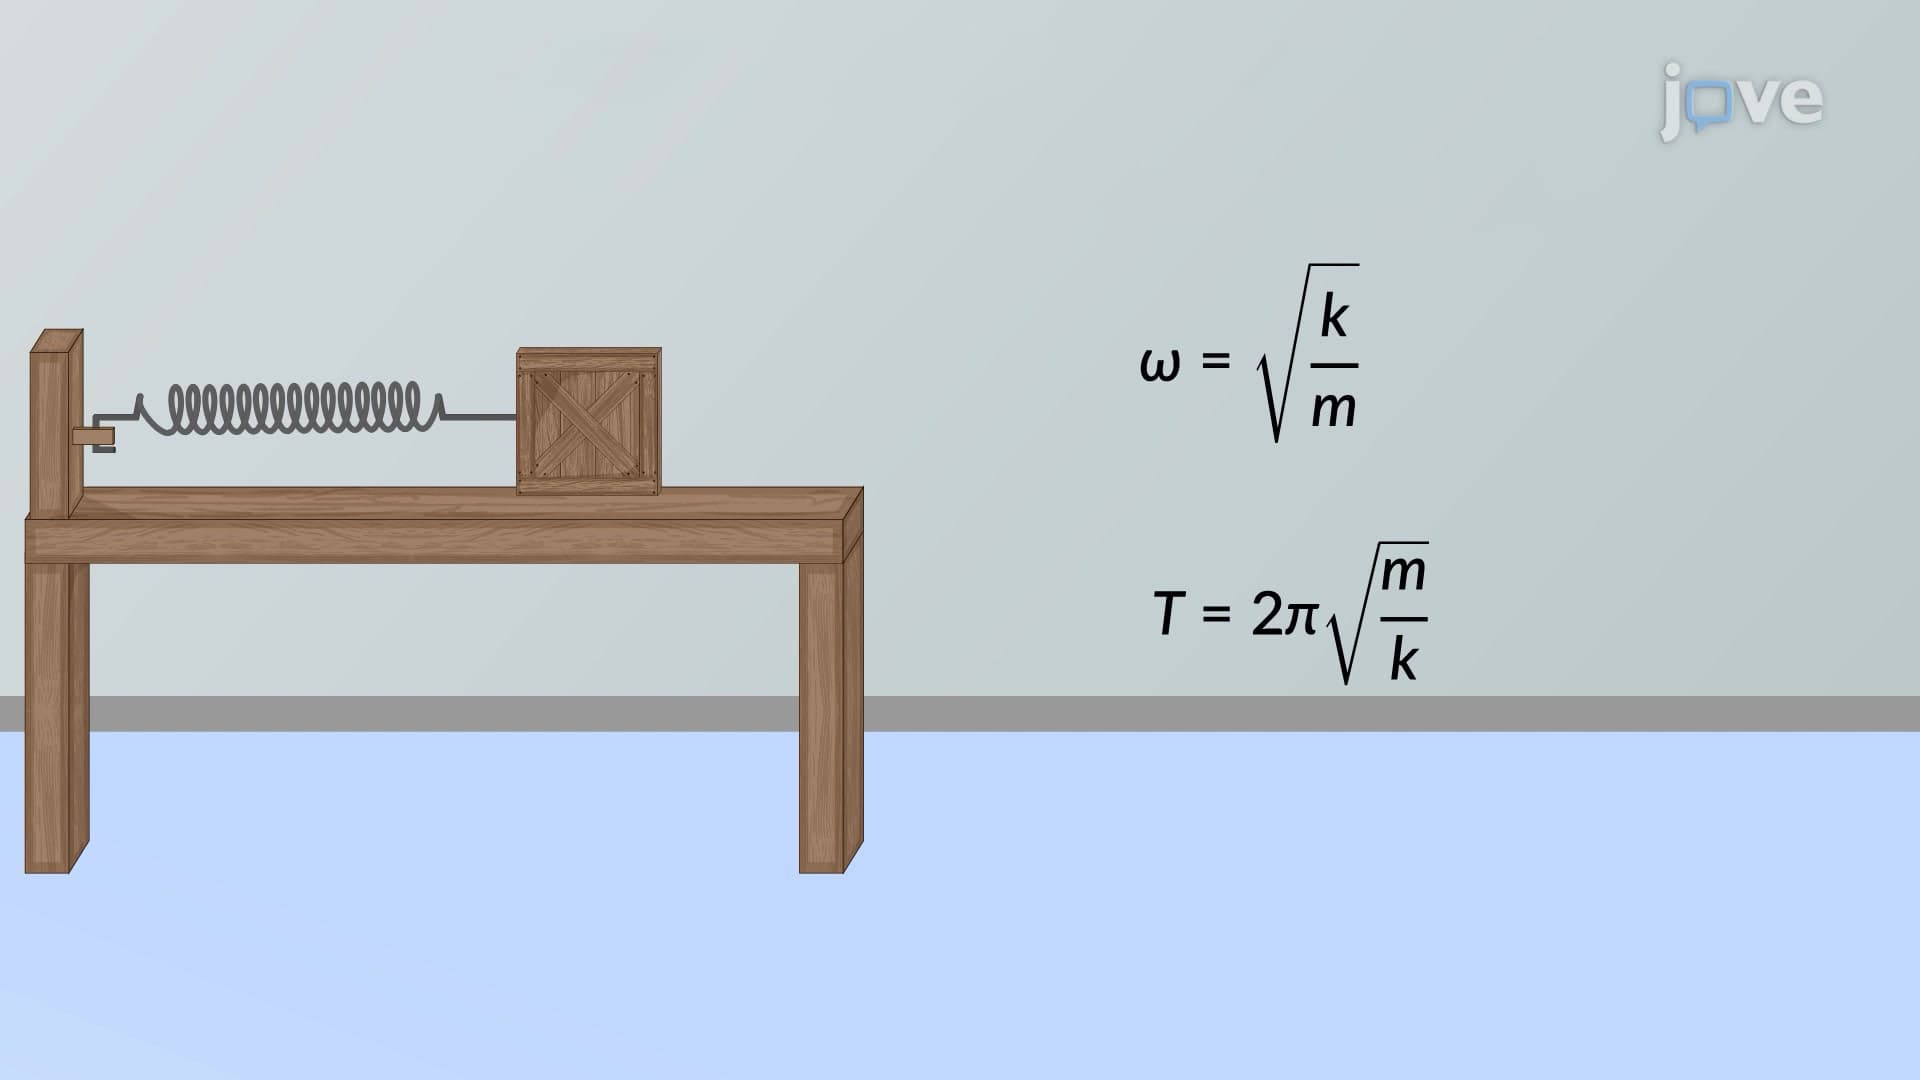
Frequency of Spring-Mass System
Consider a block on a spring on a frictionless surface. There...
 01:13
Principle of Virtual Work: Problem Solving
To apply the principle of virtual work,...