Related Experiment Video
Updated: Sep 23, 2025
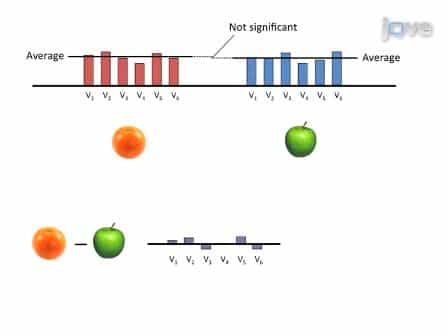
Cross-Modal Multivariate Pattern Analysis
Published on: November 9, 2011
Multimodal Unrolled Robust PCA for Background Foreground Separation

Abstract:
Background foreground separation (BFS) is a popular computer vision problem where dynamic foreground objects are separated from the static background of a scene. Typically, this is performed using consumer cameras because of their low cost, human interpretability, and high resolution. Yet, cameras and the BFS algorithms that process their data have common failure modes due to lighting changes, highly reflective surfaces, and occlusion. One solution is to incorporate an additional sensor modality that provides robustness to such failure modes. In this paper, we explore the ability of a cost-effective radar system to augment the popular Robust PCA technique for BFS. We apply the emerging technique of algorithm unrolling to yield real-time computation, feedforward inference, and strong generalization in comparison with traditional deep learning methods. We benchmark on the RaDICaL dataset to demonstrate both quantitative improvements of incorporating radar data and qualitative improvements that confirm robustness to common failure modes of image-based methods.
Related Concept Videos
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:30
Classification of Signals
A continuous-time signal holds a value at every instant in time, representing information seamlessly. In contrast, a discrete-time signal holds values only at specific moments, often denoted as x(n), where...
 01:20
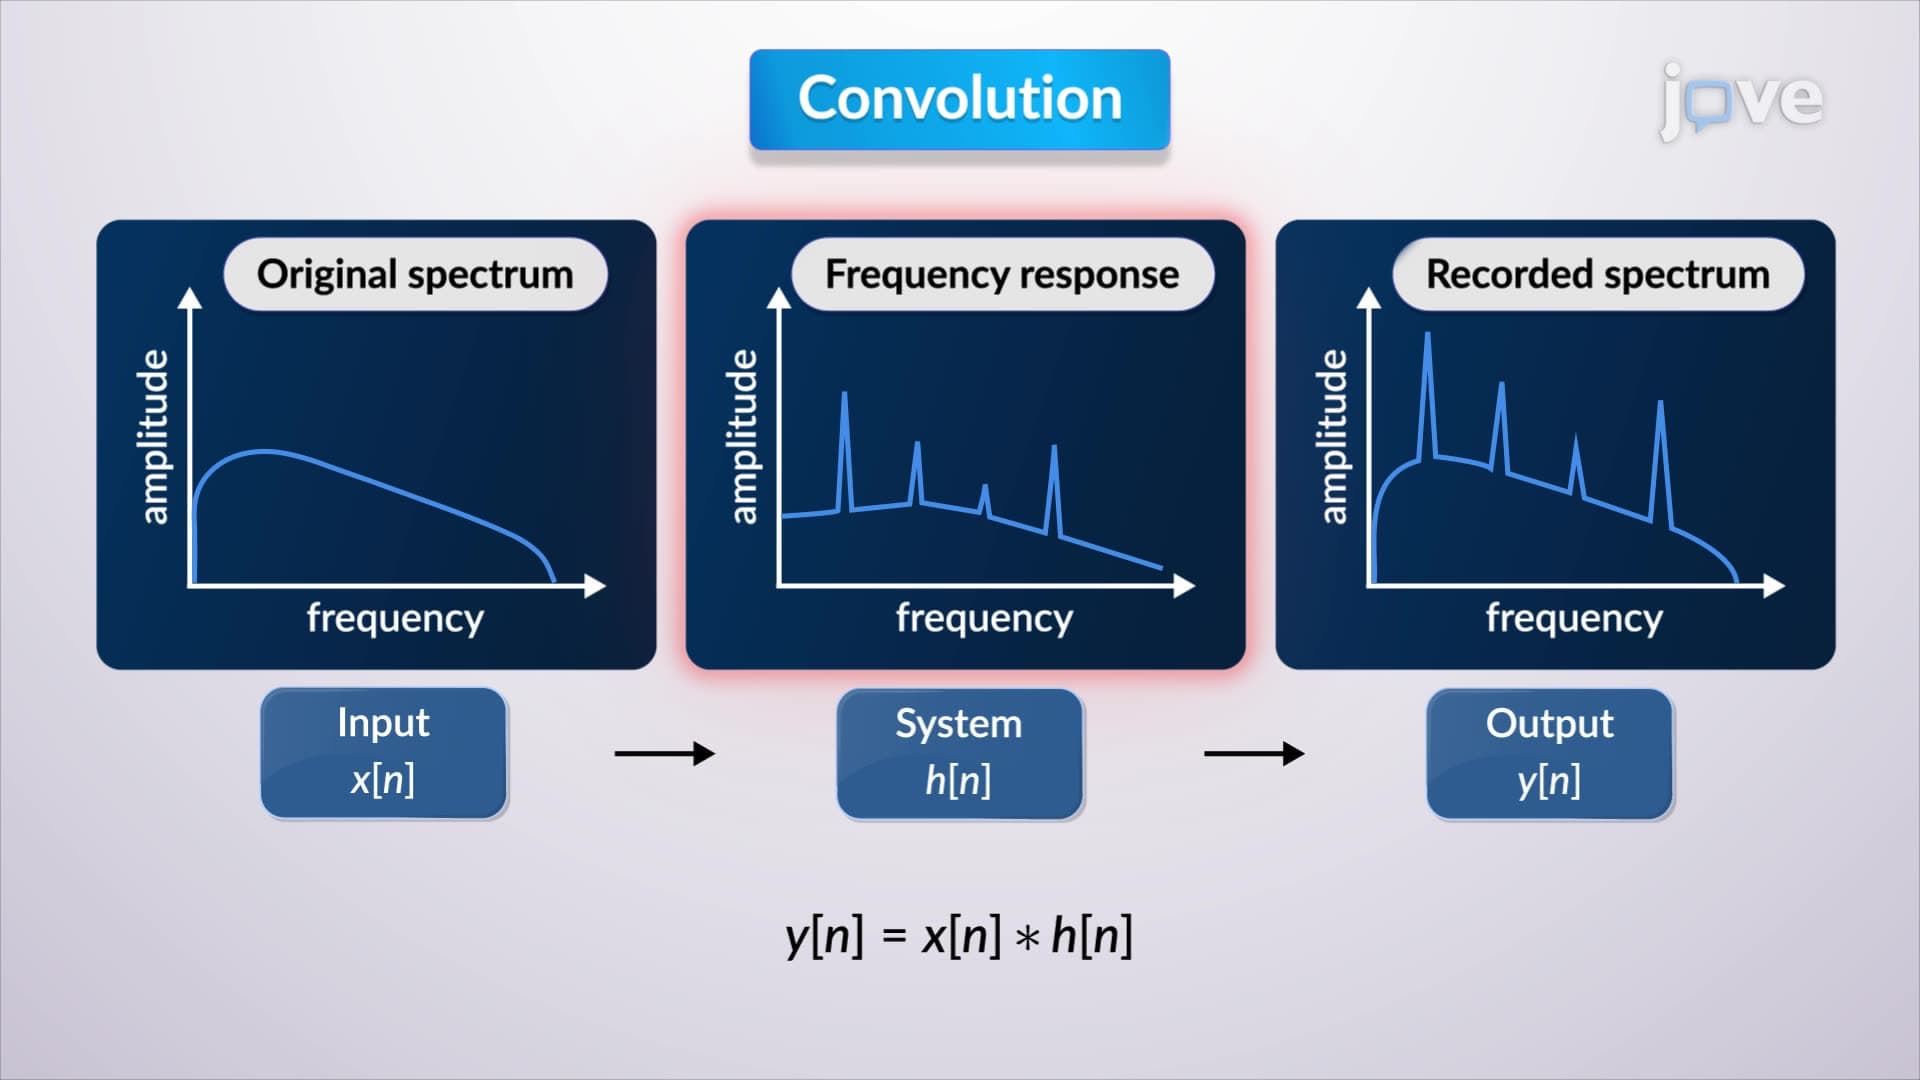
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:19
Masking and Demasking Agents
There are many masking agents, such as cyanide, fluoride, triethanolamine, thiourea, and 2,3-bis(sulfanyl)propan-1-ol (formerly 2,3-dimercapto-1-propanol), with the masking agent chosen based on...